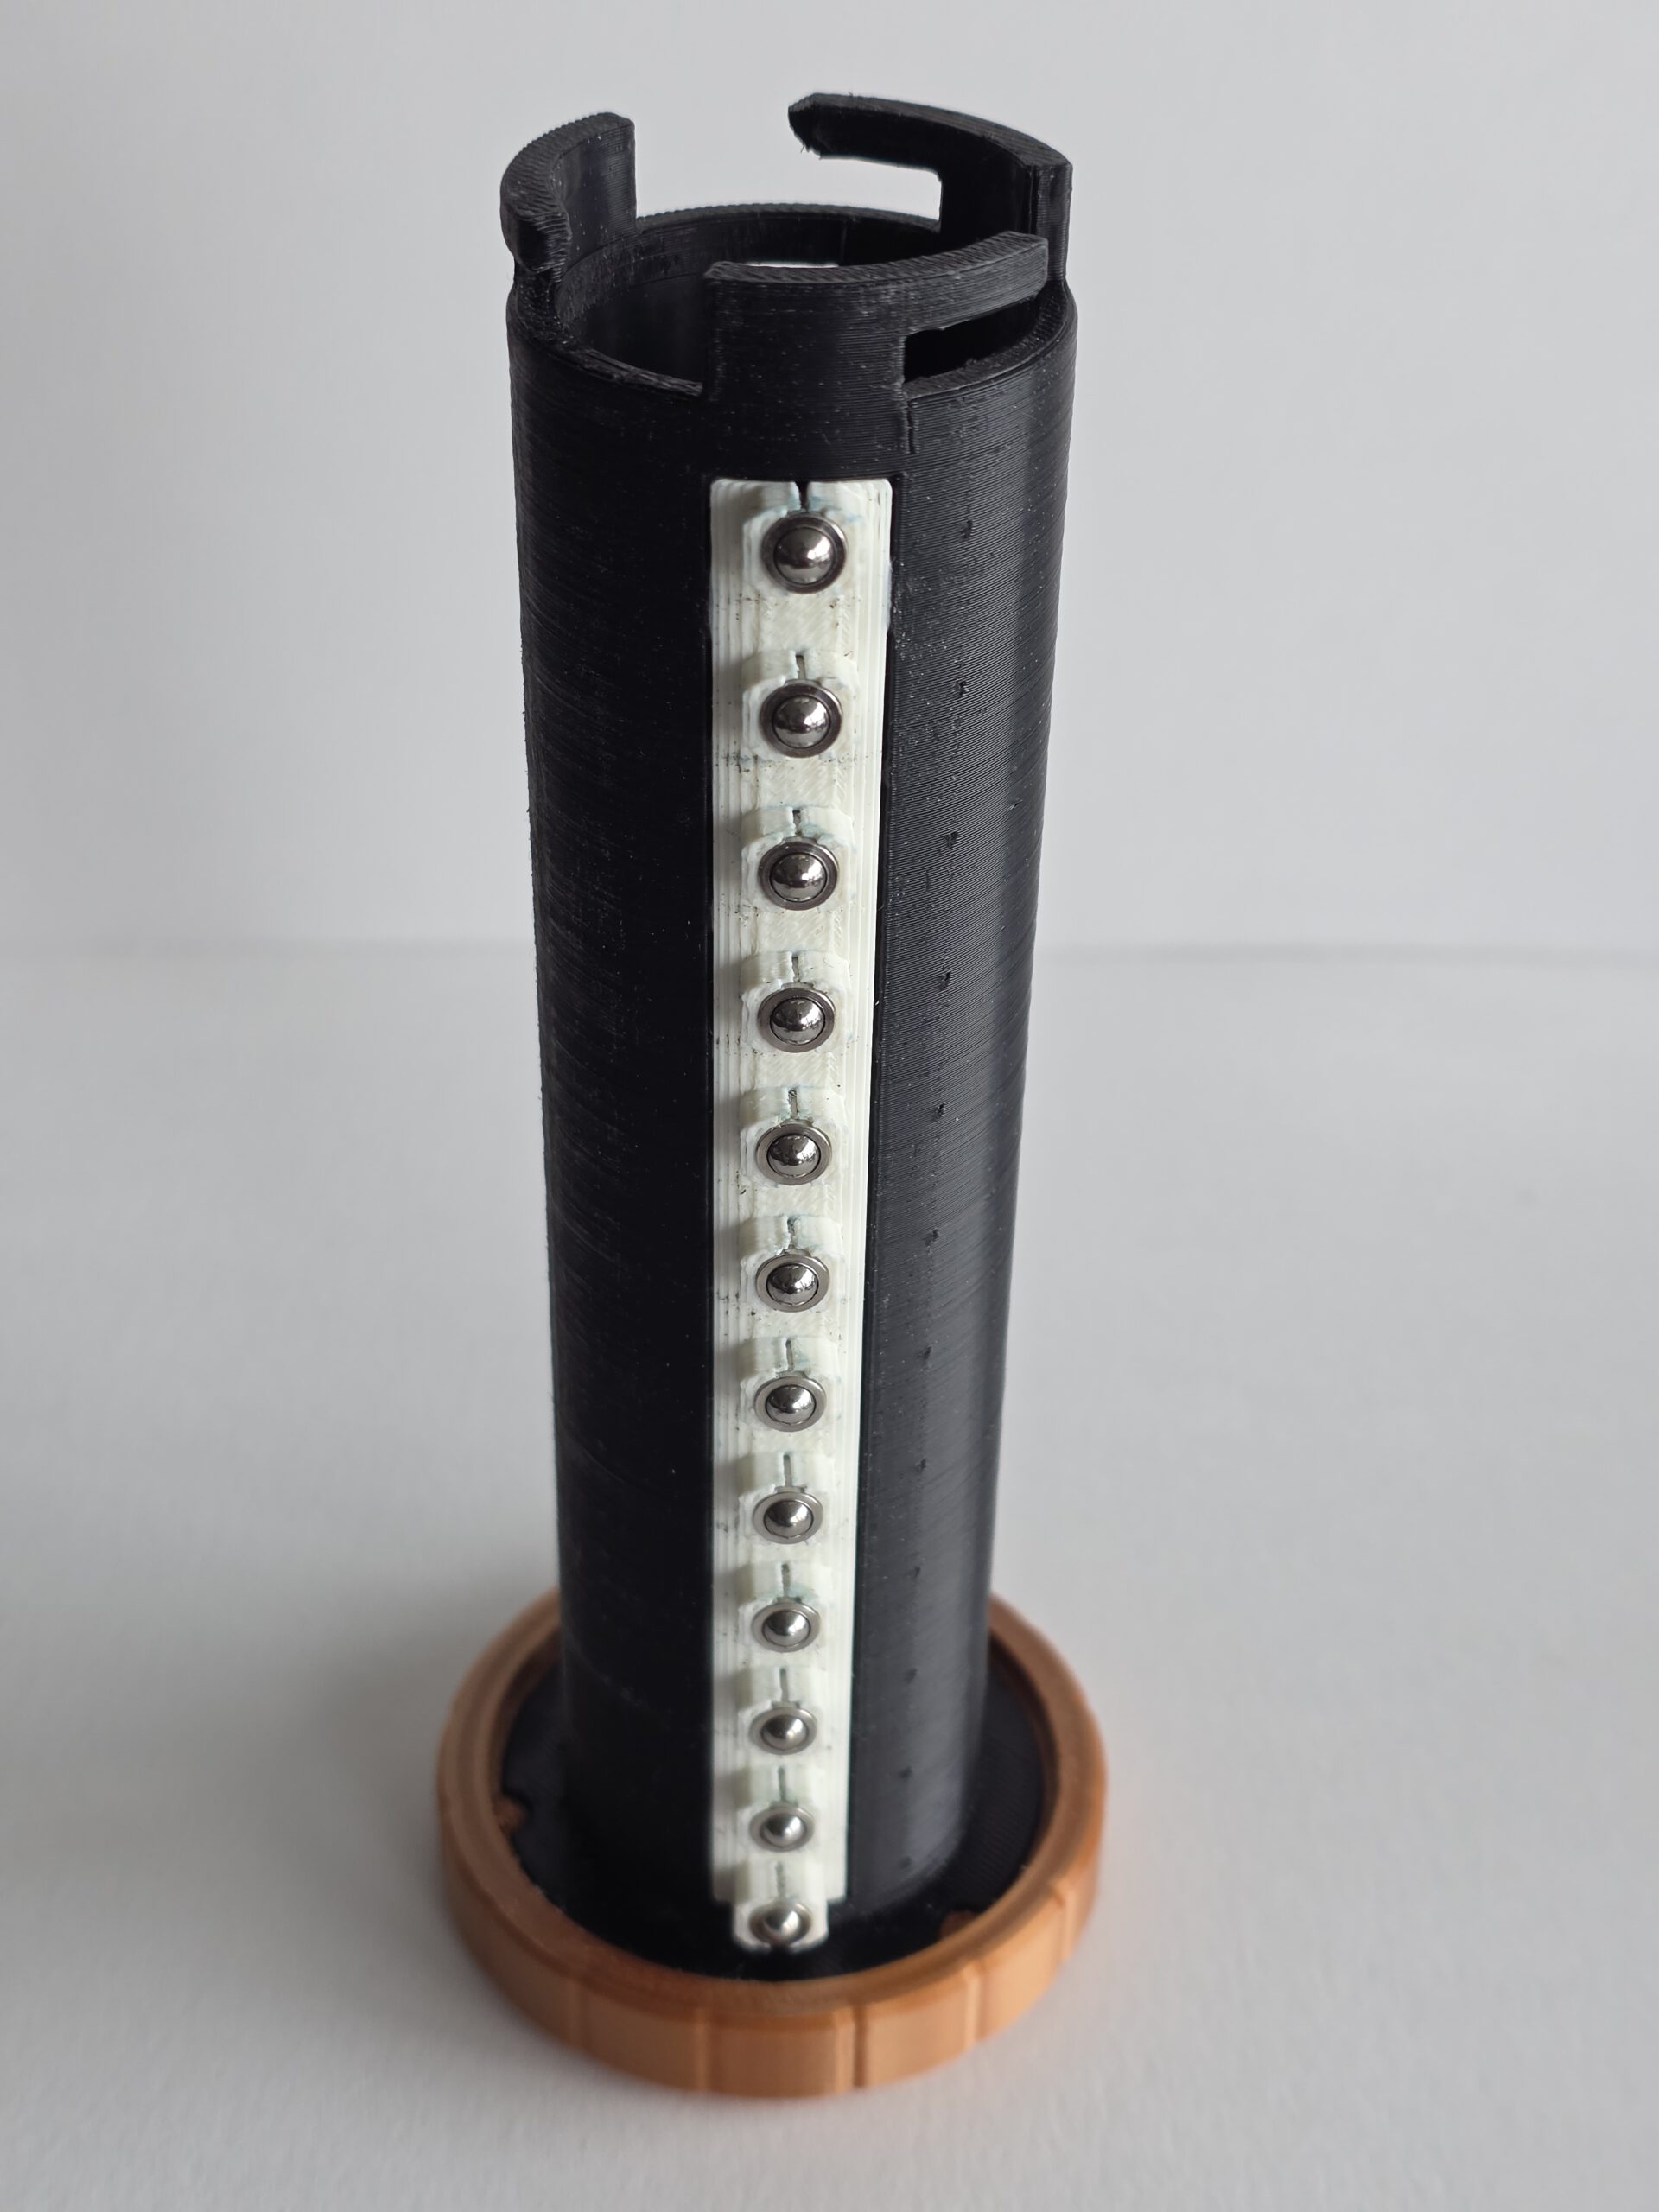
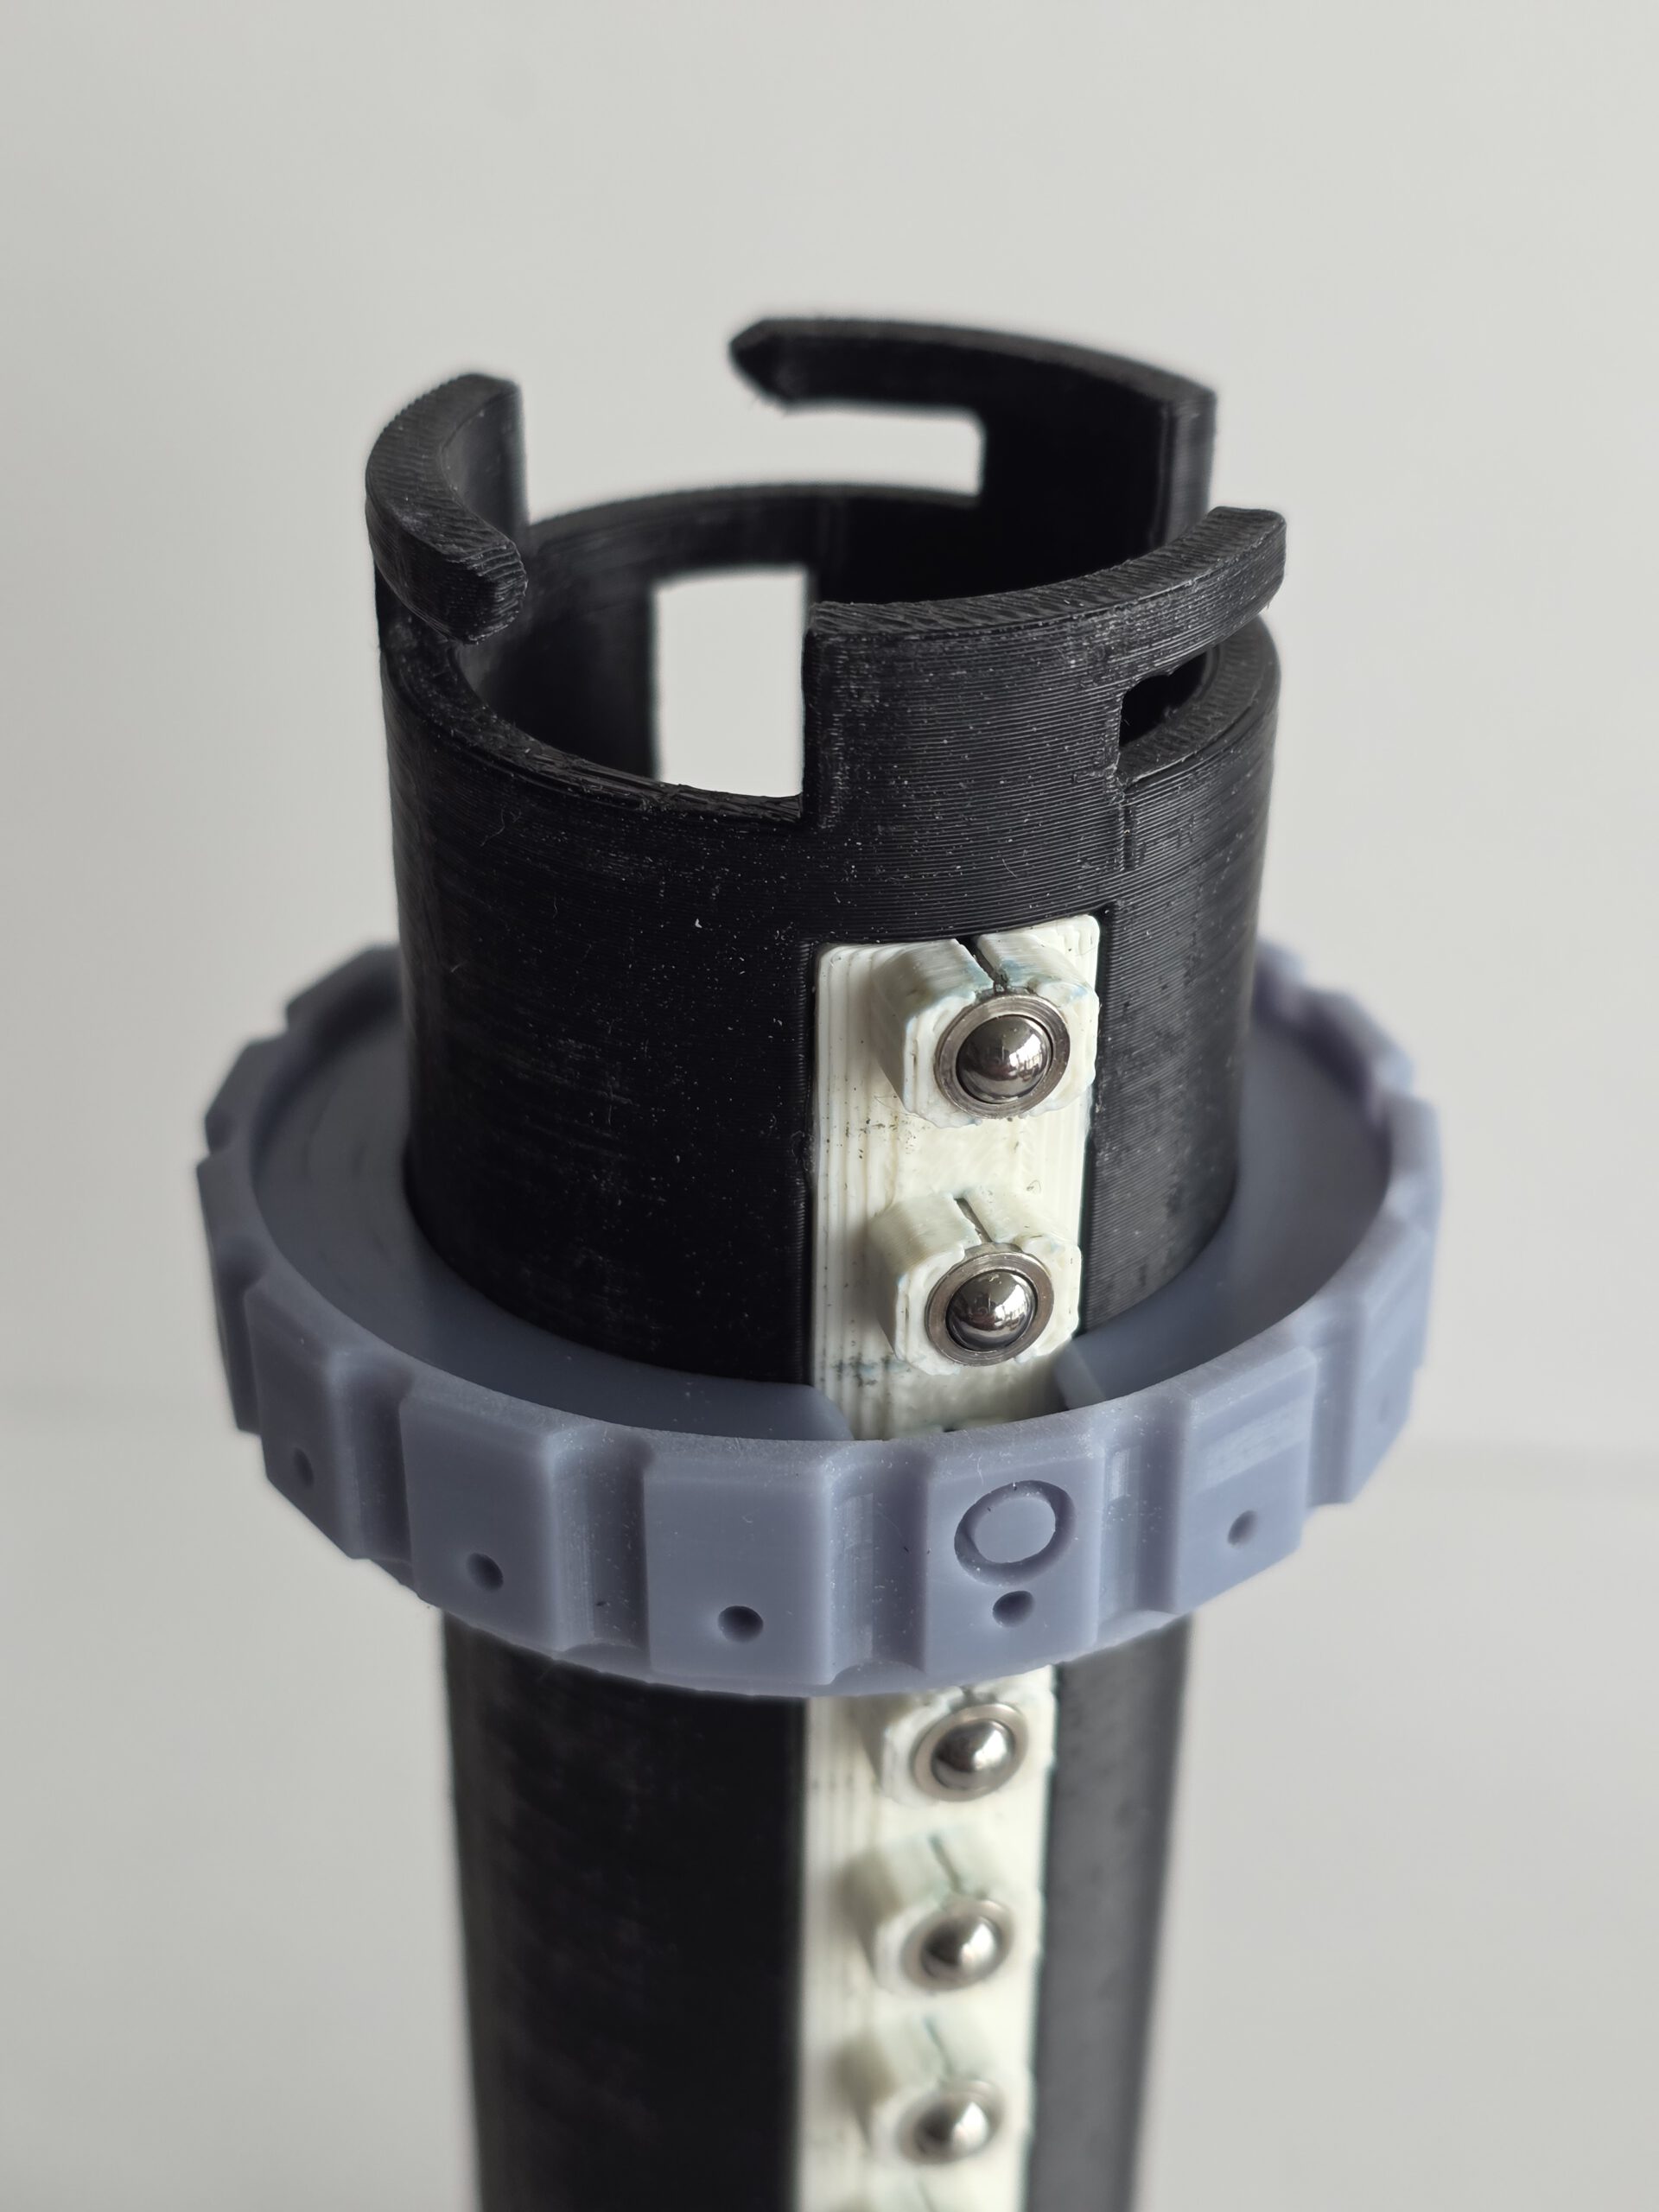
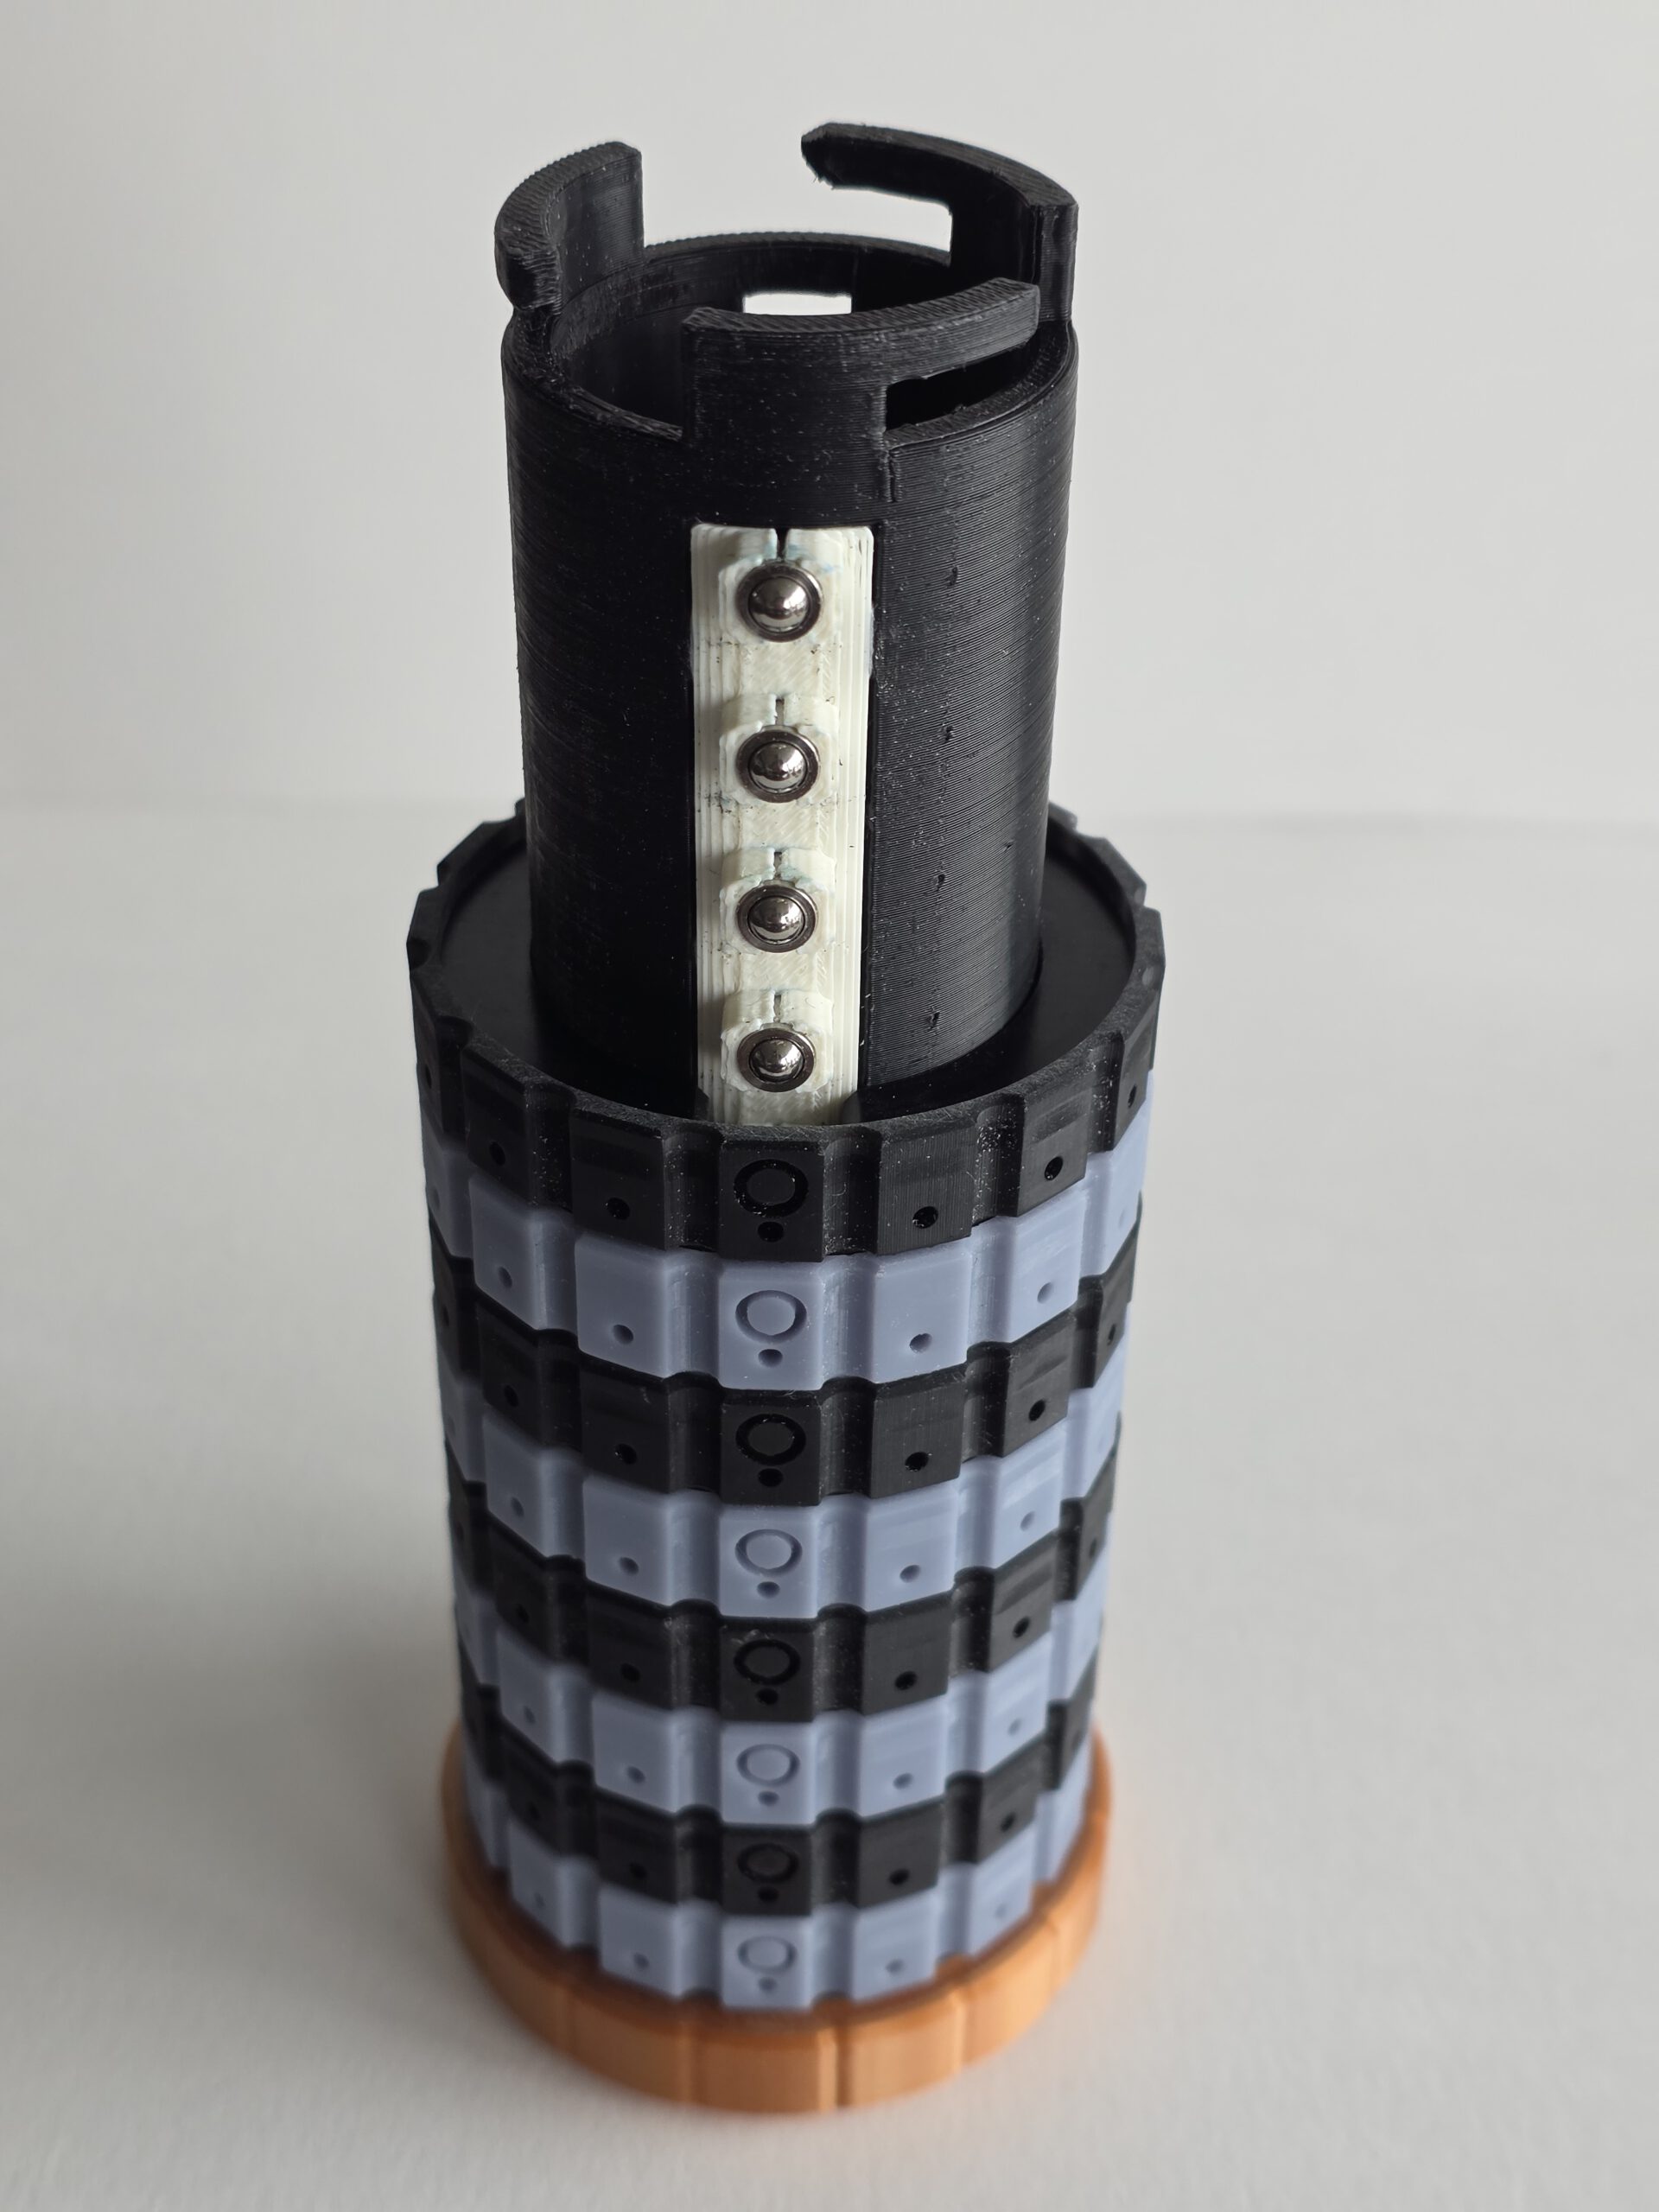
The CryptHEX (9SQM) — A fully mechanical 3D-printed cryptex I designed for a Cyber Security CTF (Capture The Flag). Twelve independently rotating rings each have 16 hexadecimal positions (0–9, A–F), creating a 48-bit combination space. Solving one of the CTF challenges revealed the code needed to open the CryptHEX; inside was the code required to continue with the next challenge. Flexible TPU locking pins make the correct ring positions deliberately difficult to detect by feel. Forget the code and there is no reset button, recovery procedure or password hint. There is, however, a saw.
Using the CryptHEX
1. CryptHEX — Assembly, Code Setup and Locking
Before You Start
The CryptHEX uses twelve code rings, each with 16 positions: 0–9 and A–F. The combination therefore consists of twelve hexadecimal characters.
Each code ring works together with a click ring, providing 16 distinct rotational positions.
The inner tube carries twelve flexible lock pins. For the inner tube to be inserted or removed, the openings in all twelve rings must be aligned with these lock pins.
The O markings are used during assembly to indicate the position of the lock pins. The arrows at the top and bottom of the CryptHEX indicate the code-reading position.
Important: Make sure you know the intended 12-character code before locking the CryptHEX. Once locked, it cannot be opened without the correct code. If you forget it, mechanical persuasion involving a saw may be required.
Step 1 — Install the Click Rings
Slide the first click ring onto the outer tube.
Each click ring has a clearance slot that allows it to pass over the click mechanism. Align this slot with the click mechanism and slide the ring down into position.
Repeat this procedure until all 12 click rings have been installed.
Step 2 — Move the Click Rings to the Open Position
Once all twelve click rings are installed, rotate each click ring 180 degrees.
The clearance slots should now be positioned on the opposite side of the click mechanism, creating a continuous vertical clearance for the twelve lock pins on the inner tube.
The O markings indicate this lock-pin position. and should now align with the arrow on the fixed ring of the outer tube.
The CryptHEX is now in its open position.
Step 3 — Install the Code Rings and Set the Combination
Fit the twelve hexadecimal code rings onto their corresponding click rings.
The physical position of each code ring relative to its click ring determines which character will appear at the code-reading position when the lock-pin openings are aligned.
Position each code ring so that the desired hexadecimal character appears along the code-reading line indicated by the arrows at the top and bottom of the CryptHEX.
Repeat this for all twelve rings.
The twelve characters between the arrows now form the opening code.
Step 4 — Install the Locking Lid
Before inserting the inner tube, place the locking lid onto the CryptHEX and rotate it fully into its locked position.
This must be done before inserting the inner tube.
Once the inner tube has been installed, it mechanically prevents the locking lid from being rotated and removed.
Step 5 — Insert the Inner Tube
Check once more that all twelve code rings are correctly positioned.
The arrows at the top and bottom of the CryptHEX indicate the code-reading position. The twelve hexadecimal characters aligned between these arrows must show the intended combination.
Carefully slide the inner tube into the outer tube.
The twelve flexible lock pins should pass through the aligned openings without requiring significant force.
Do not force the inner tube. If it does not slide in freely, check that all twelve rings are correctly positioned.
Push the inner tube fully into position.
Step 6 — Lock the CryptHEX
Rotate several or all of the code rings away from the programmed combination.
The openings are now moved away from the lock pins, preventing the inner tube from being removed.
Because the inner tube also blocks the locking lid, the complete assembly is now mechanically locked.
The CryptHEX is now locked.
To open it again, rotate all twelve rings until the correct hexadecimal combination appears between the two arrows. This realigns all twelve openings with the lock pins, allowing the inner tube to be removed.
2. CryptHEX — Disassembly, Changing the Code and Reassembly
Before You Start
To change the combination, the CryptHEX must first be opened using its current 12-character hexadecimal code.
There is no externally accessible reset mechanism while the CryptHEX is locked.
Important: Do not start changing the code unless you know the current combination and can successfully remove the inner tube.
Step 1 — Enter the Current Code
Rotate each of the twelve code rings until the correct hexadecimal combination appears along the code-reading line indicated by the arrows at the top and bottom of the CryptHEX.
Check the complete 12-character code carefully.
When all twelve positions are correct, the internal openings will be aligned with the lock pins on the inner tube.
Step 2 — Remove the Inner Tube
Carefully pull the inner tube straight out of the CryptHEX.
The twelve flexible lock pins should pass through the aligned openings.
Only light resistance should be present.
Do not force it. If the inner tube will not slide out, check all twelve code positions again. A single incorrectly positioned ring is enough to prevent removal.
Once the inner tube has been removed, leave all rings in this position. The CryptHEX is now in its open position, and there is no need to rotate the rings by 180 degrees.
Step 3 — Remove the Locking Lid
With the inner tube removed, the locking lid is no longer mechanically blocked.
Step 4 — Remove the Code Rings
Keep the CryptHEX in its open position.
The twelve code rings can now be slid off the outer tube. Their clearance slots are already correctly aligned with the click mechanism, so there is no need to rotate the rings first. The “O” markings now should align with the arrow on the Fixed Ring on the outer tube.
Remove all twelve code rings.
Step 5 — Reinstall the Code Rings
With the CryptHEX still in its open position, slide the twelve code rings back onto the outer tube.
Each ring can be installed in a different rotational orientation. This is how the combination is mechanically programmed. DO NOT ROTATE the inner rings during this process.
Install each ring so that the hexadecimal character required for the new combination will appear at the code-reading position indicated by the arrows.
Repeat this for all twelve positions.
Step 6 — Set and Verify the New Code
Check the characters displayed along the code-reading line between the top and bottom arrows.
They should show your new 12-character hexadecimal combination.
Valid characters are:
0 1 2 3 4 5 6 7 8 9 A B C D E F
Check the entire code carefully before continuing.
At this point, the physical relationship between the code rings and their click positions defines the new combination. No additional programming or adjustment is required.
Write down the new code before continuing. The CryptHEX does not have a Forgot password? button.
Step 7 — Reinstall the Locking Lid
Place the locking lid onto the CryptHEX and rotate it fully into its locked position.
This must be done before inserting the inner tube.
Step 8 — Insert the Inner Tube
Keep the newly programmed code aligned between the arrows.
Carefully slide the inner tube into the CryptHEX.
The twelve flexible lock pins should pass freely through the aligned openings.
Do not force it. If the inner tube does not slide in easily, stop and check the position of all twelve rings.
Push the inner tube fully into position.
Step 9 — Lock the CryptHEX
Rotate several or all of the code rings away from the new combination.
The lock pins are now trapped behind the rings, preventing the inner tube from being removed.
Because the inner tube also prevents the locking lid from being released, the CryptHEX is now fully locked.
Step 10 — Test the New Combination
Before putting anything important inside the CryptHEX, test the new combination at least once.
Enter the new code between the arrows and verify that the inner tube can be removed.
Reinsert the inner tube and scramble the code rings again.
Verify that the inner tube and locking lid are both securely locked.
Your new combination is now ready for use.
And REMEMBER the code. There is no master key, backdoor or recovery code. There is however… the saw…
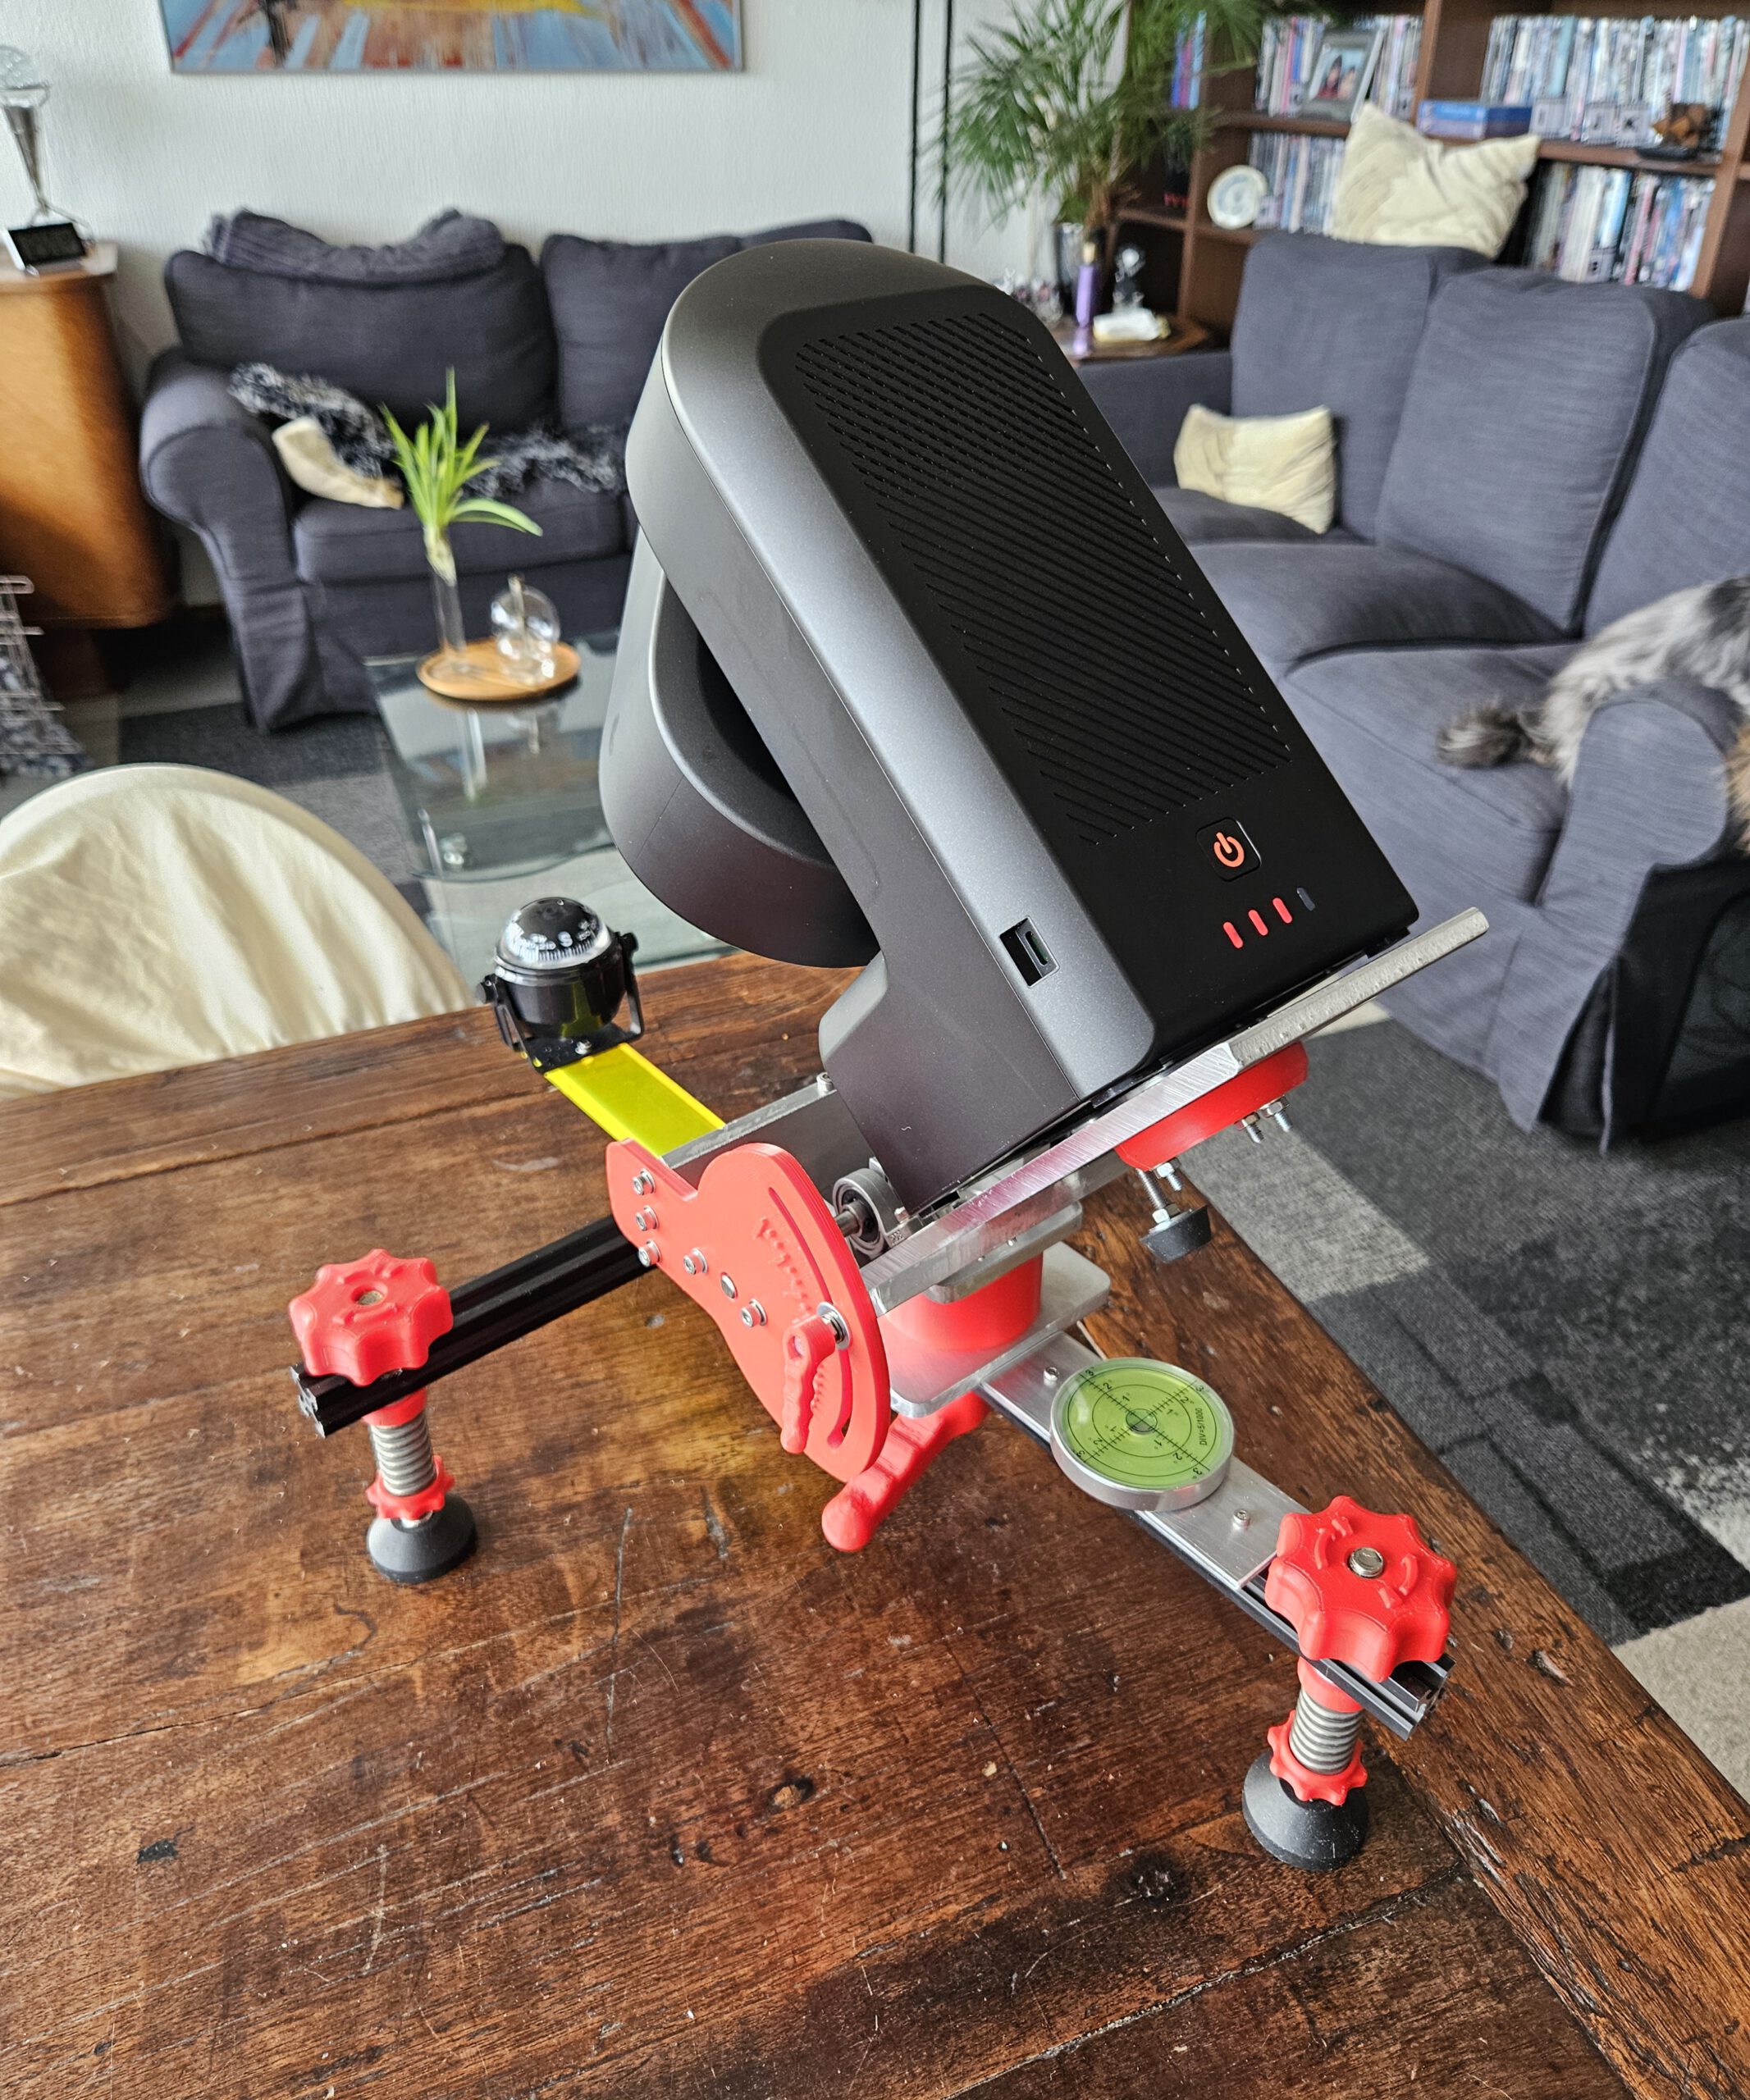
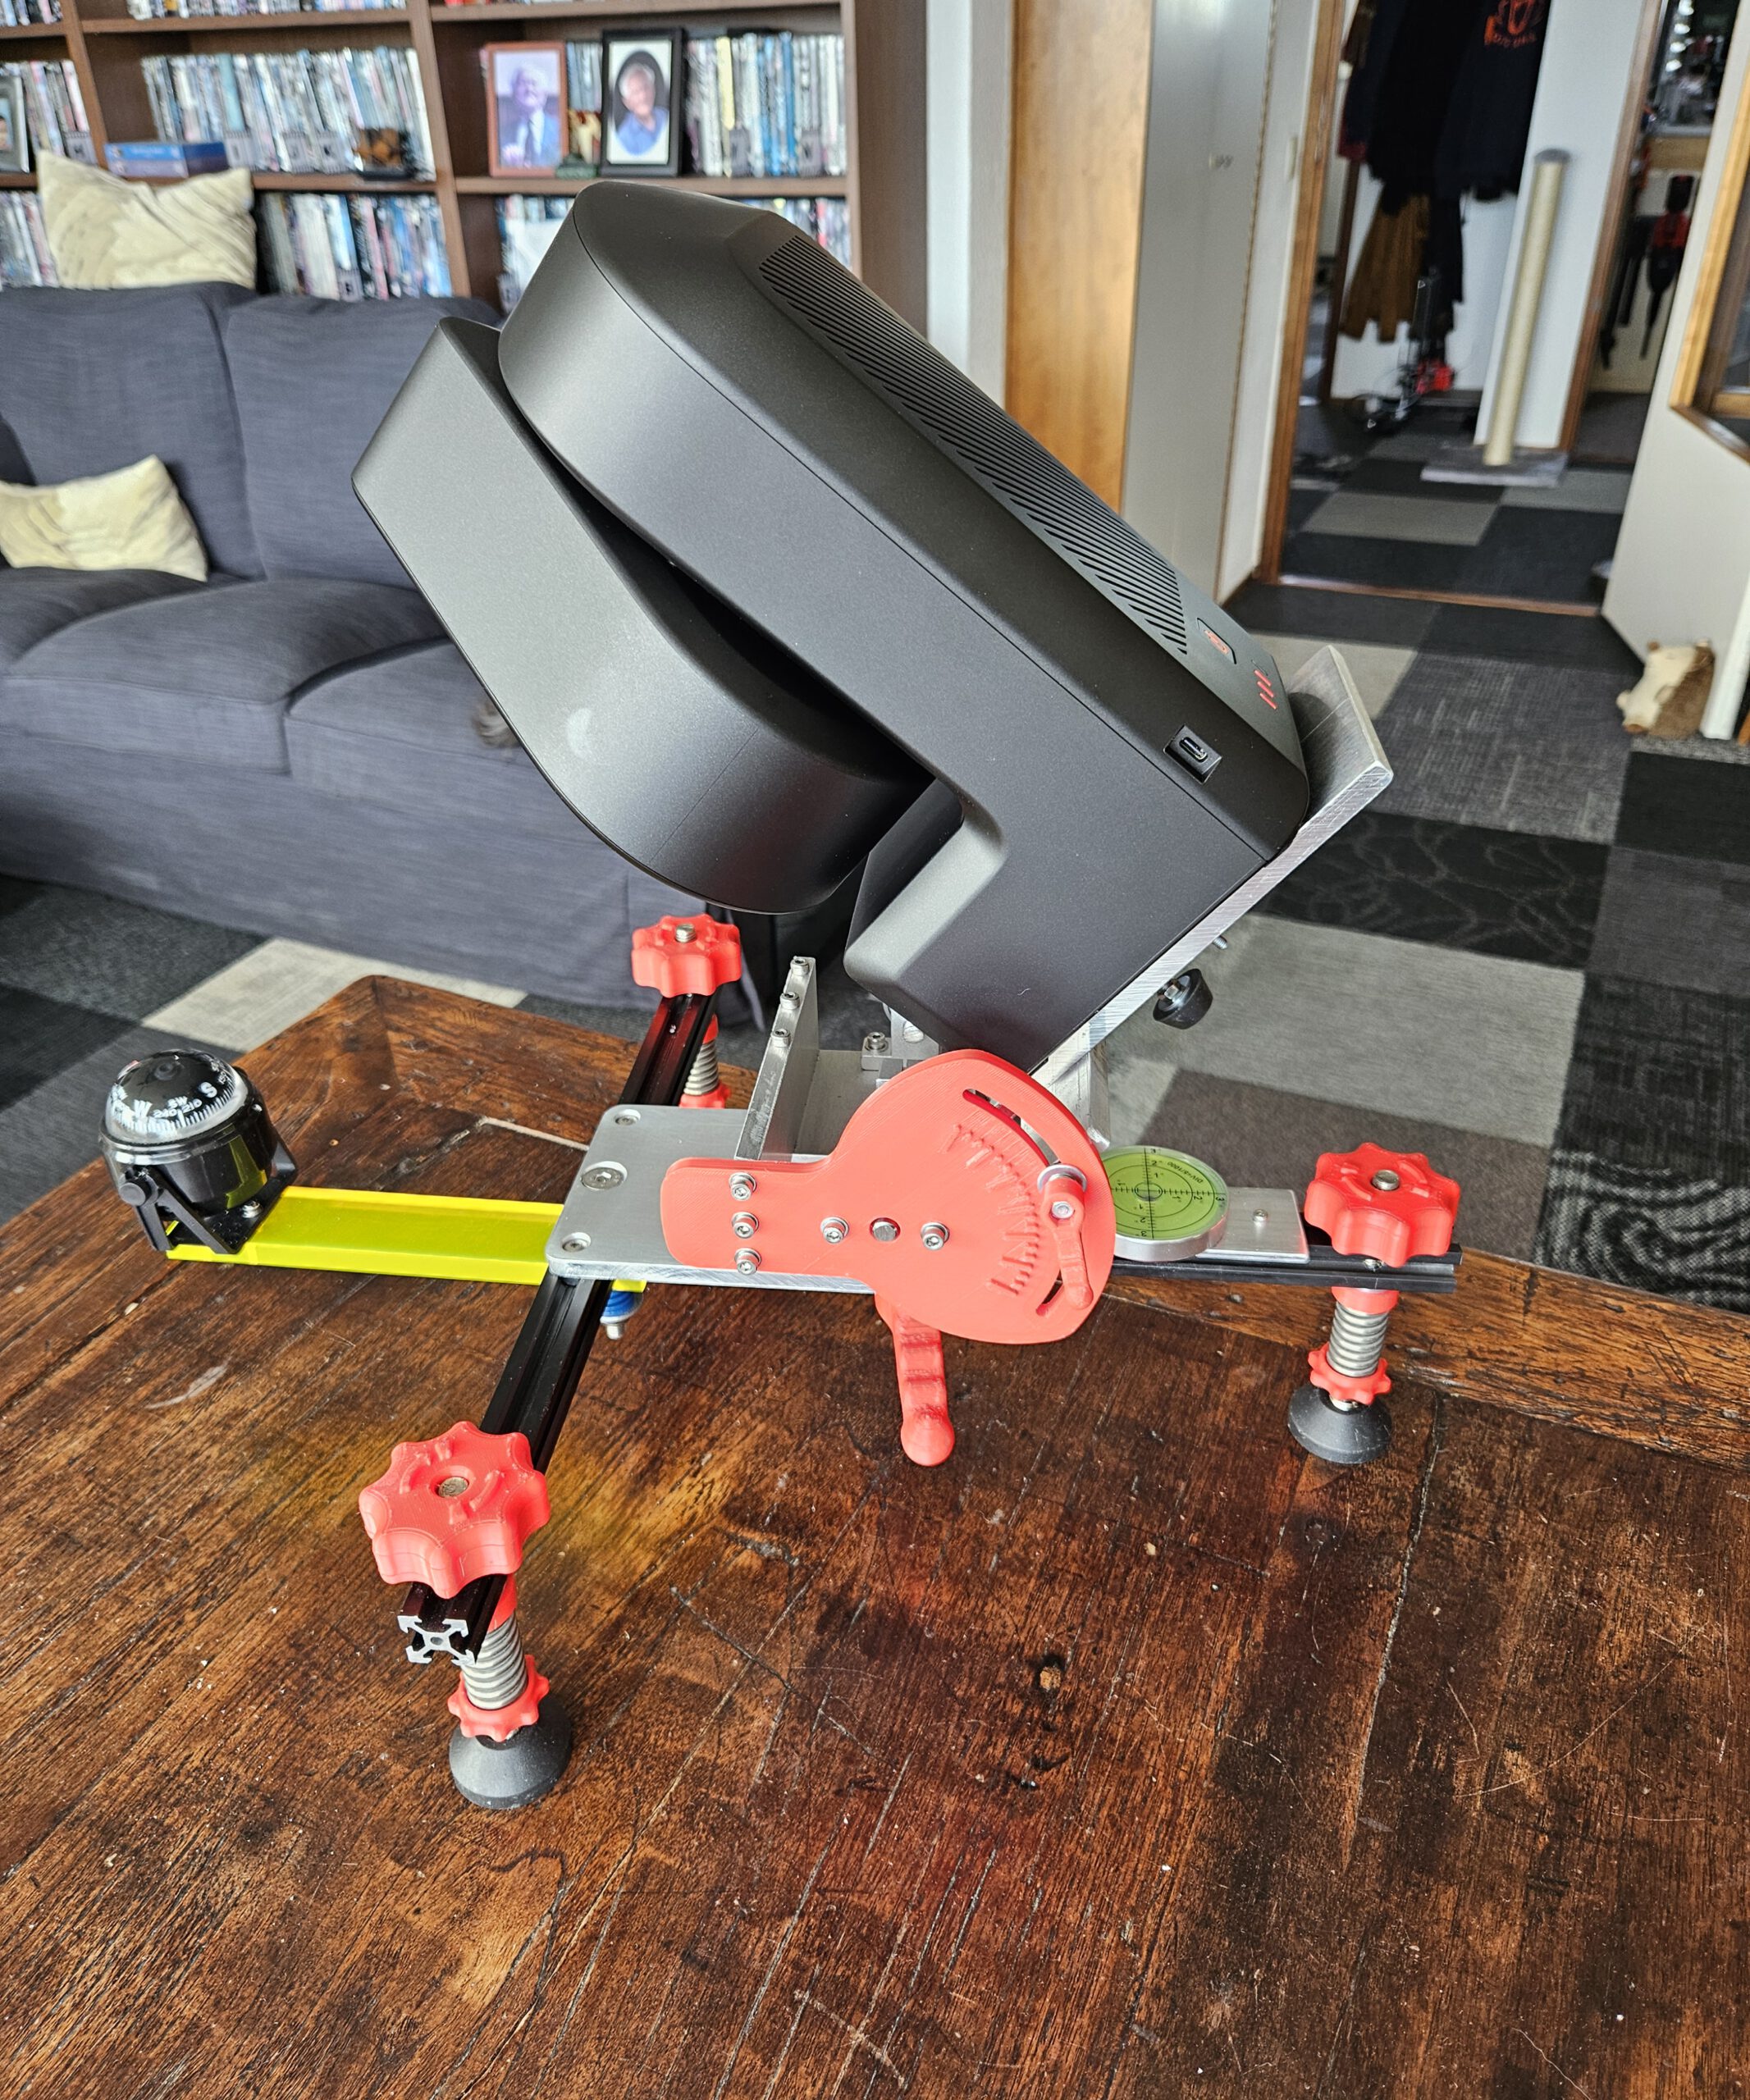
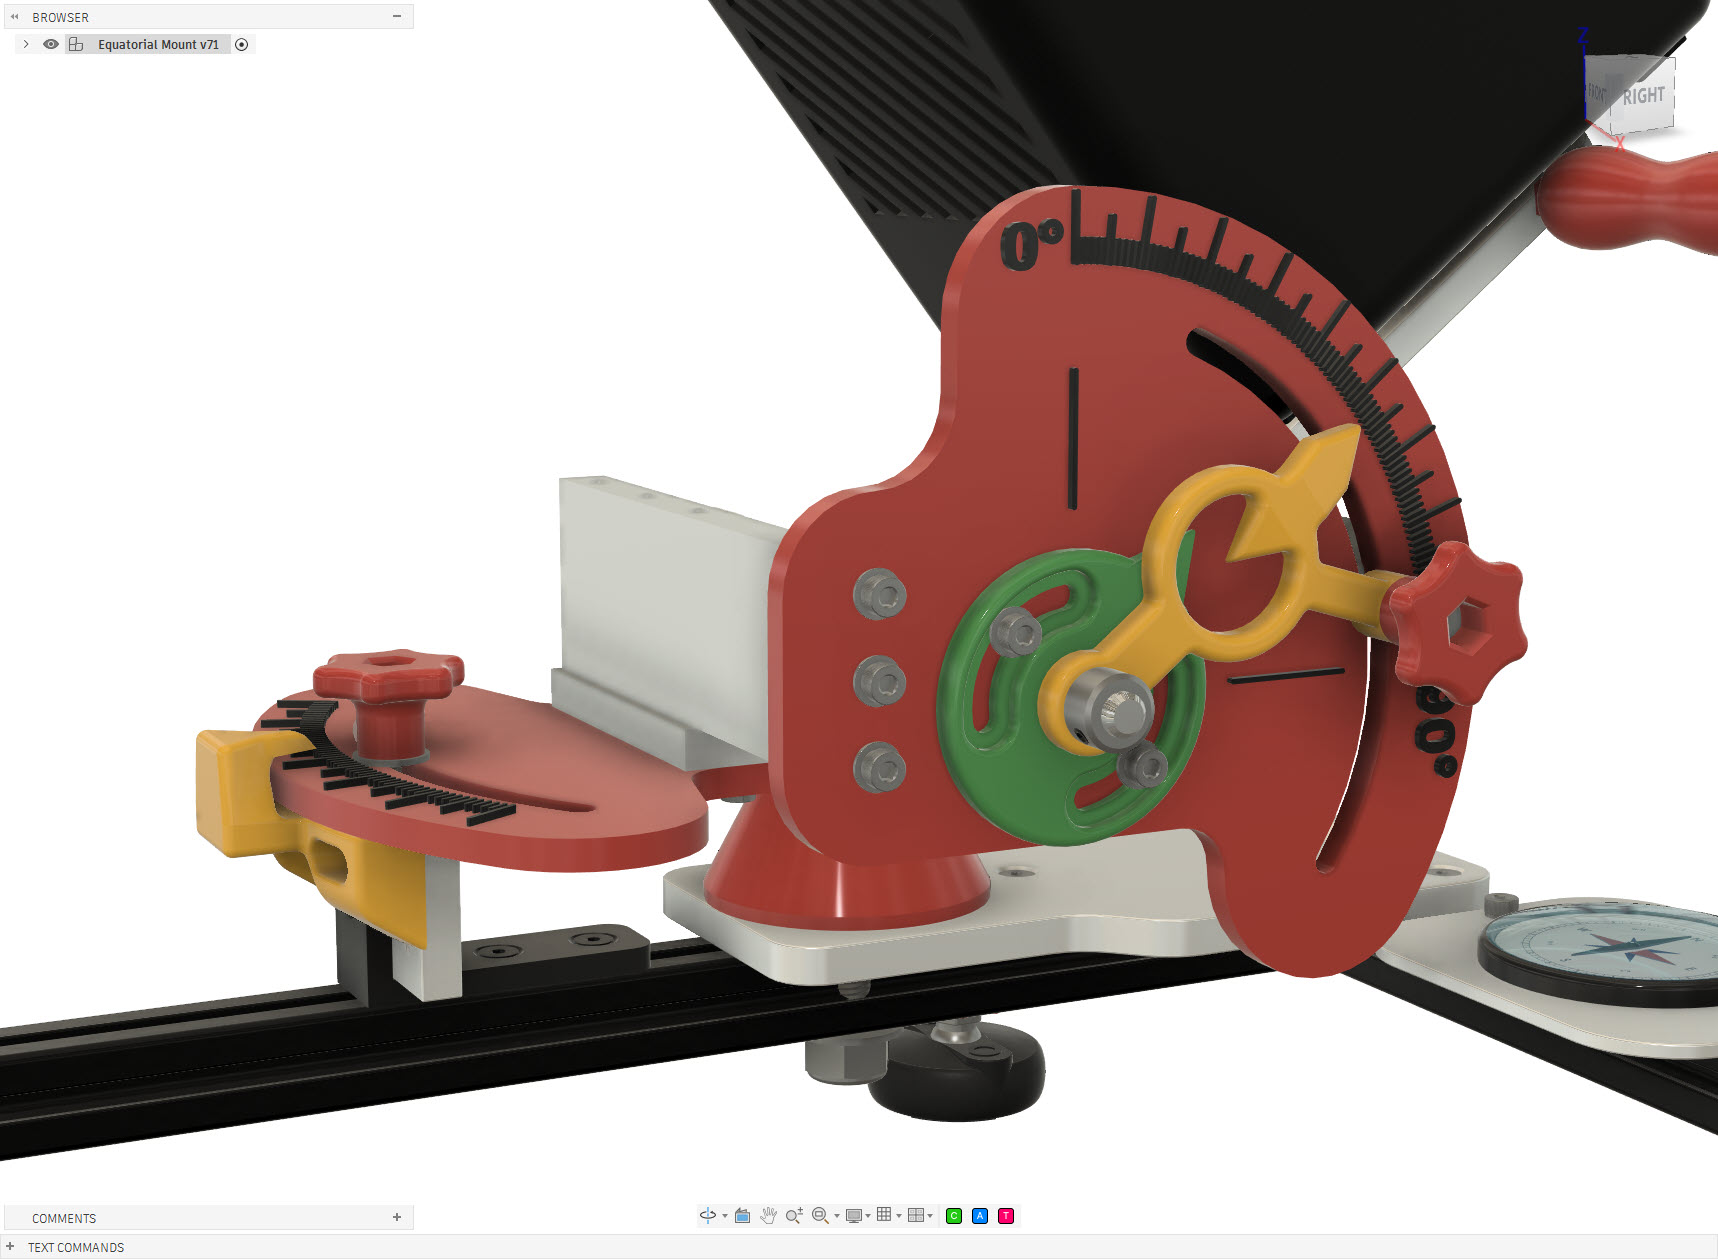
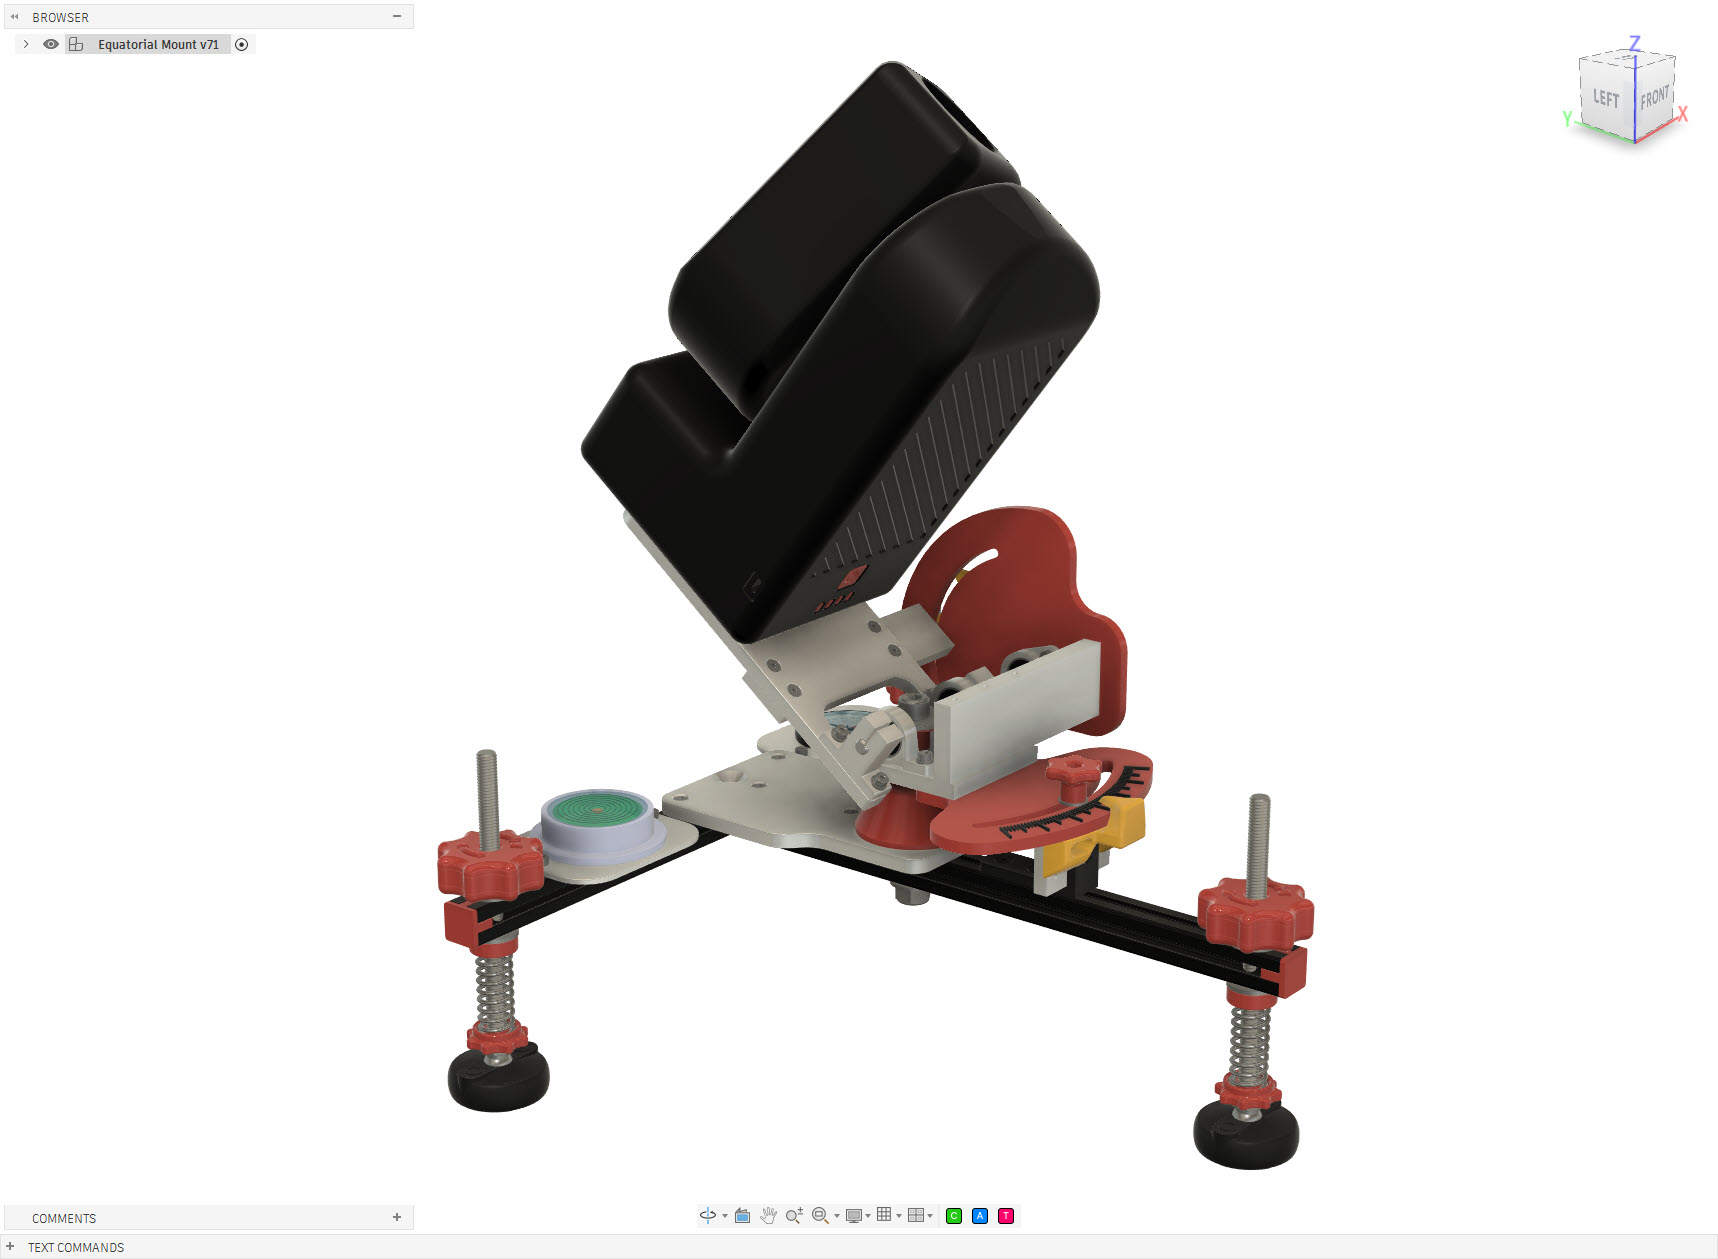
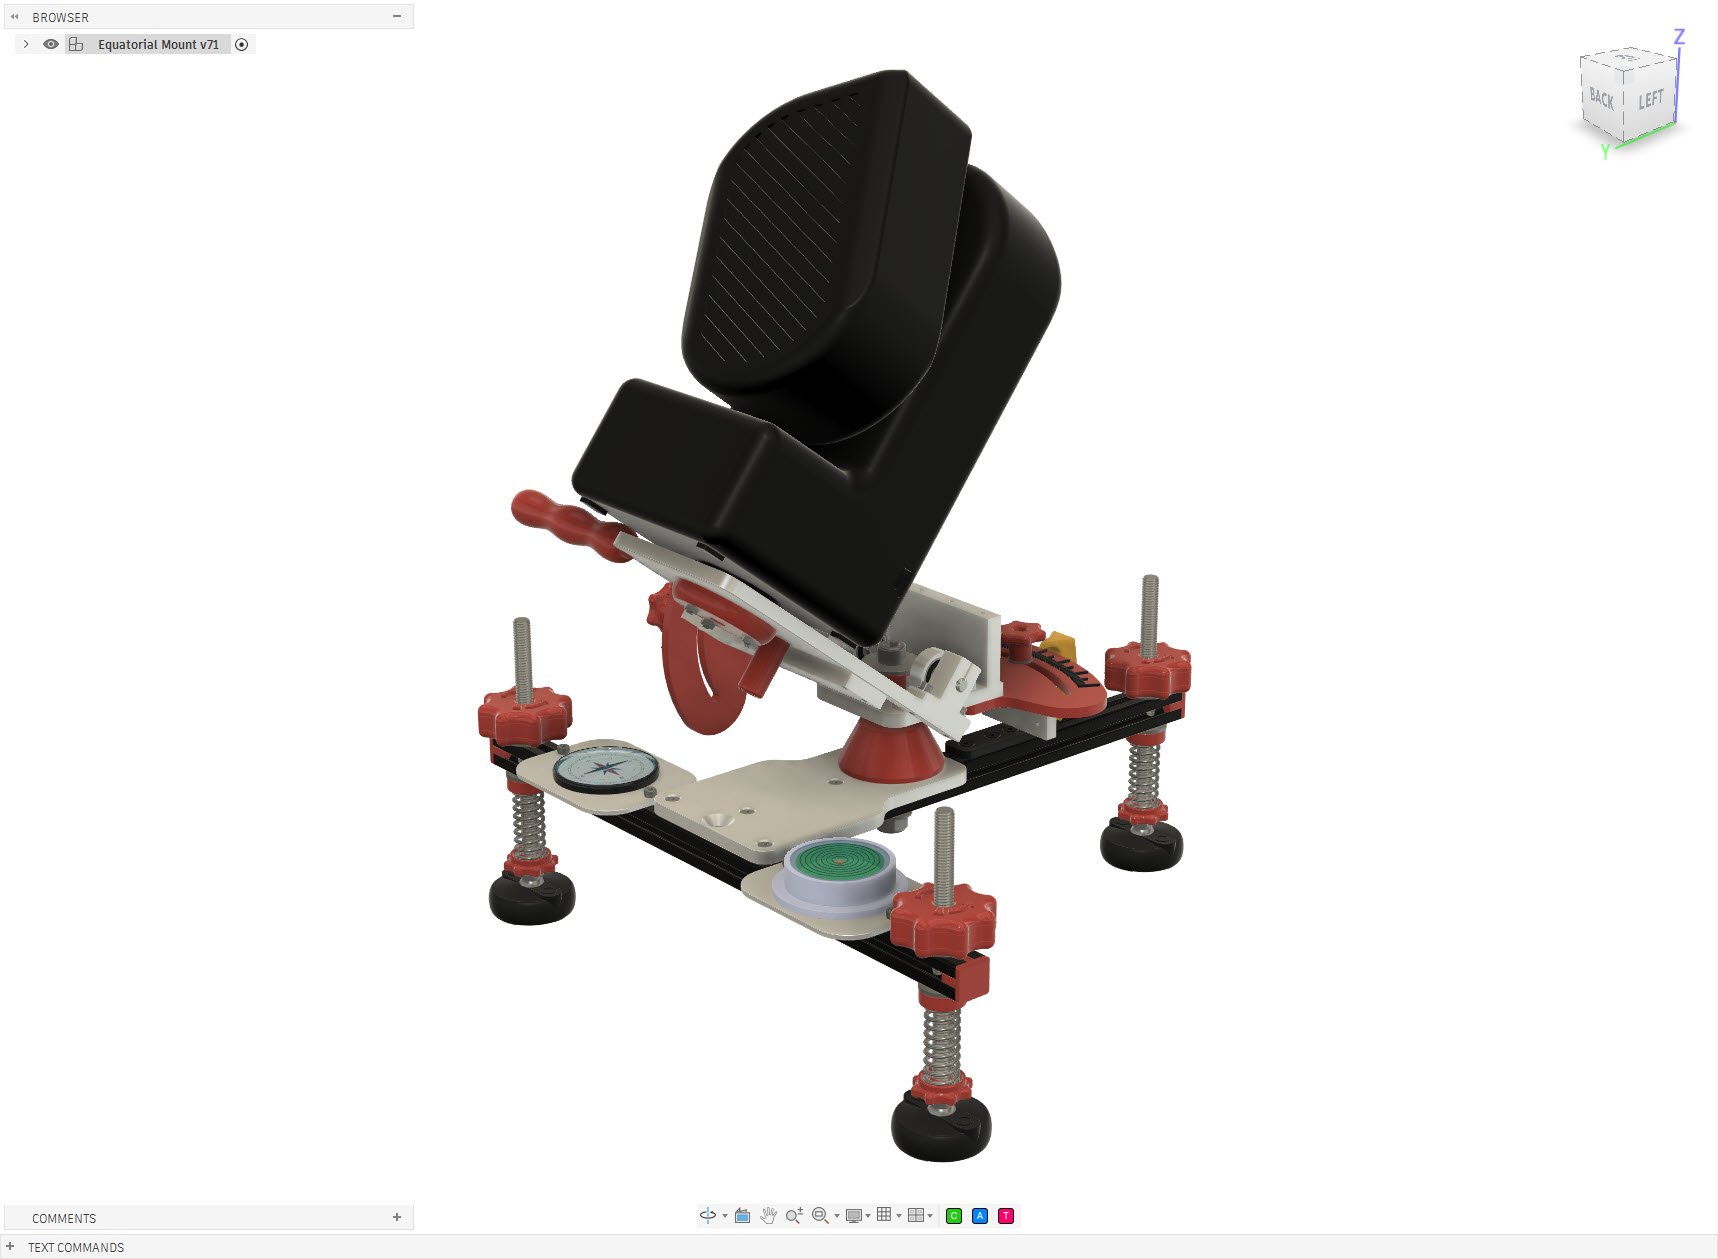
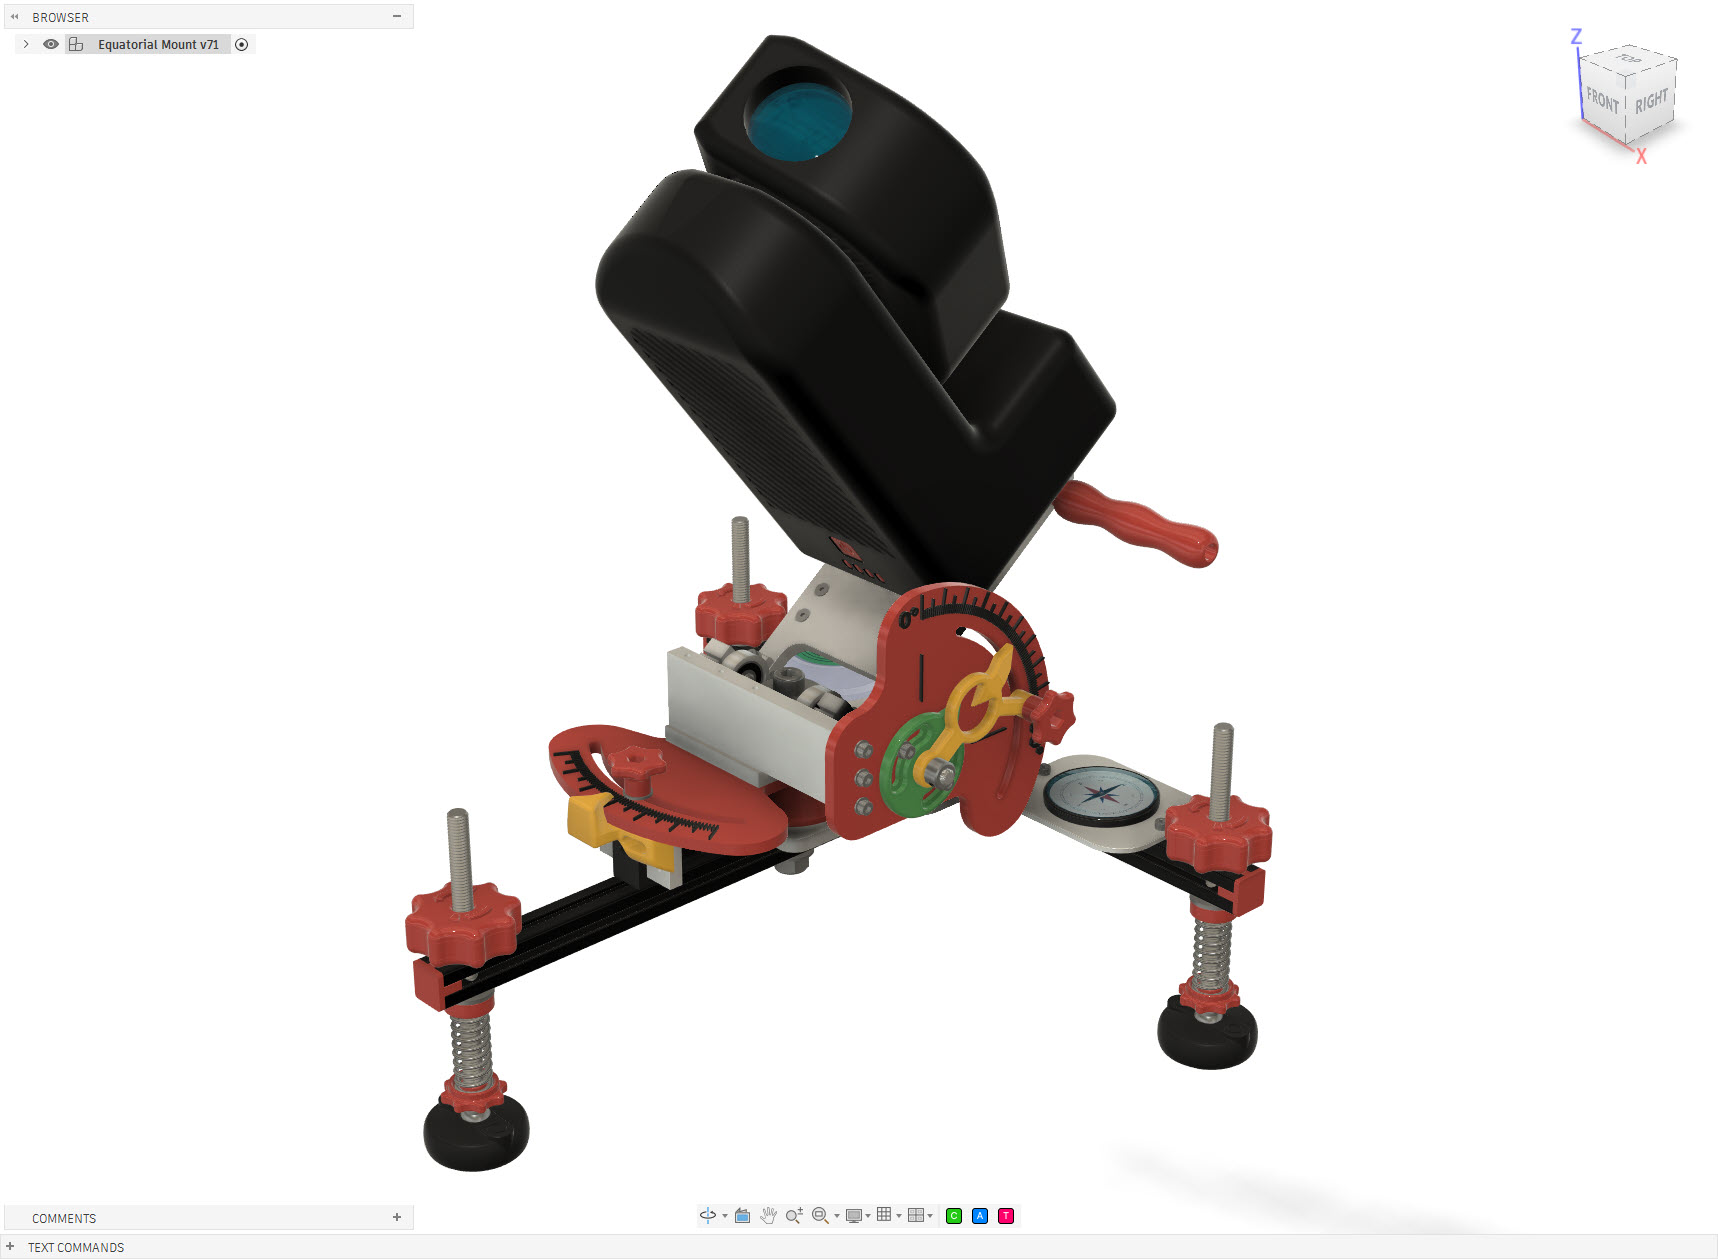
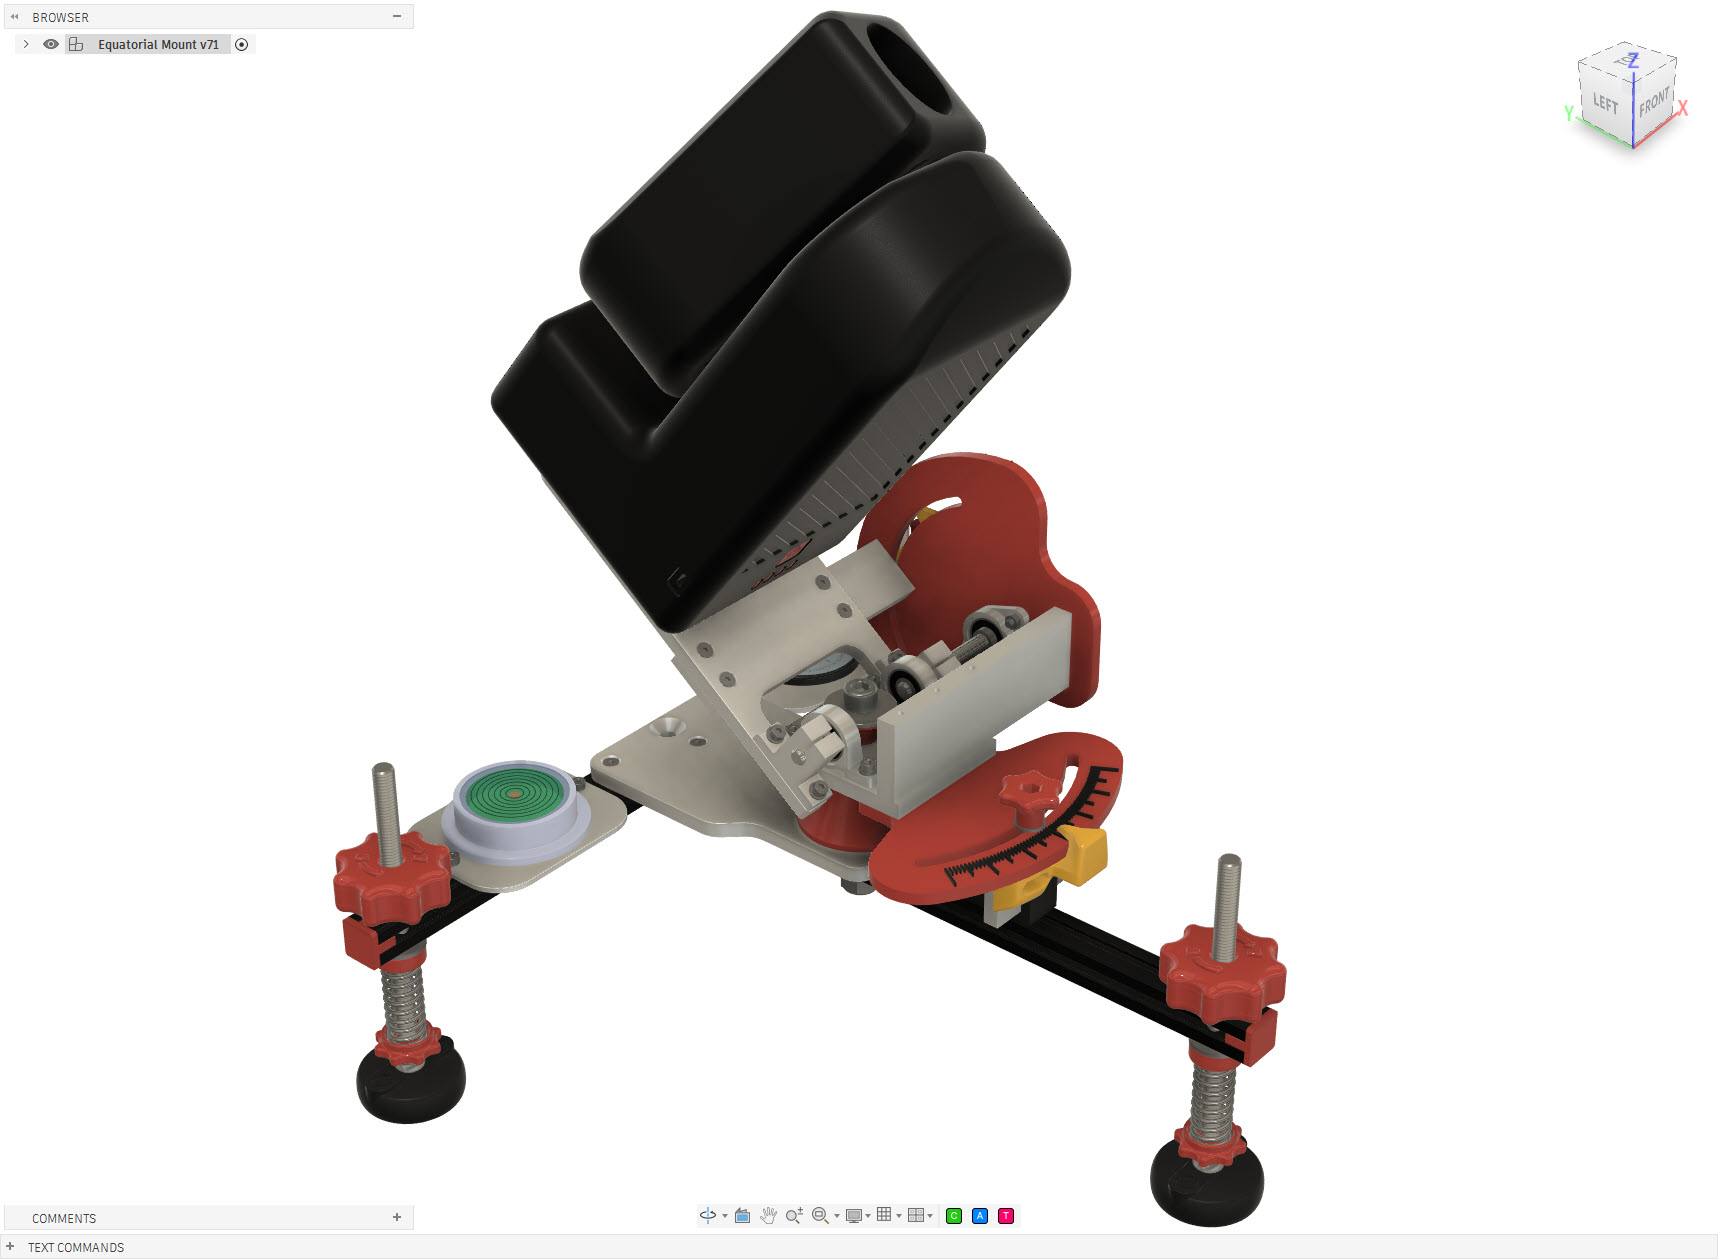
Equatorial Mount for the ZWO Seestar S50 telescope. Giving a smart telescope a different way to follow the sky.
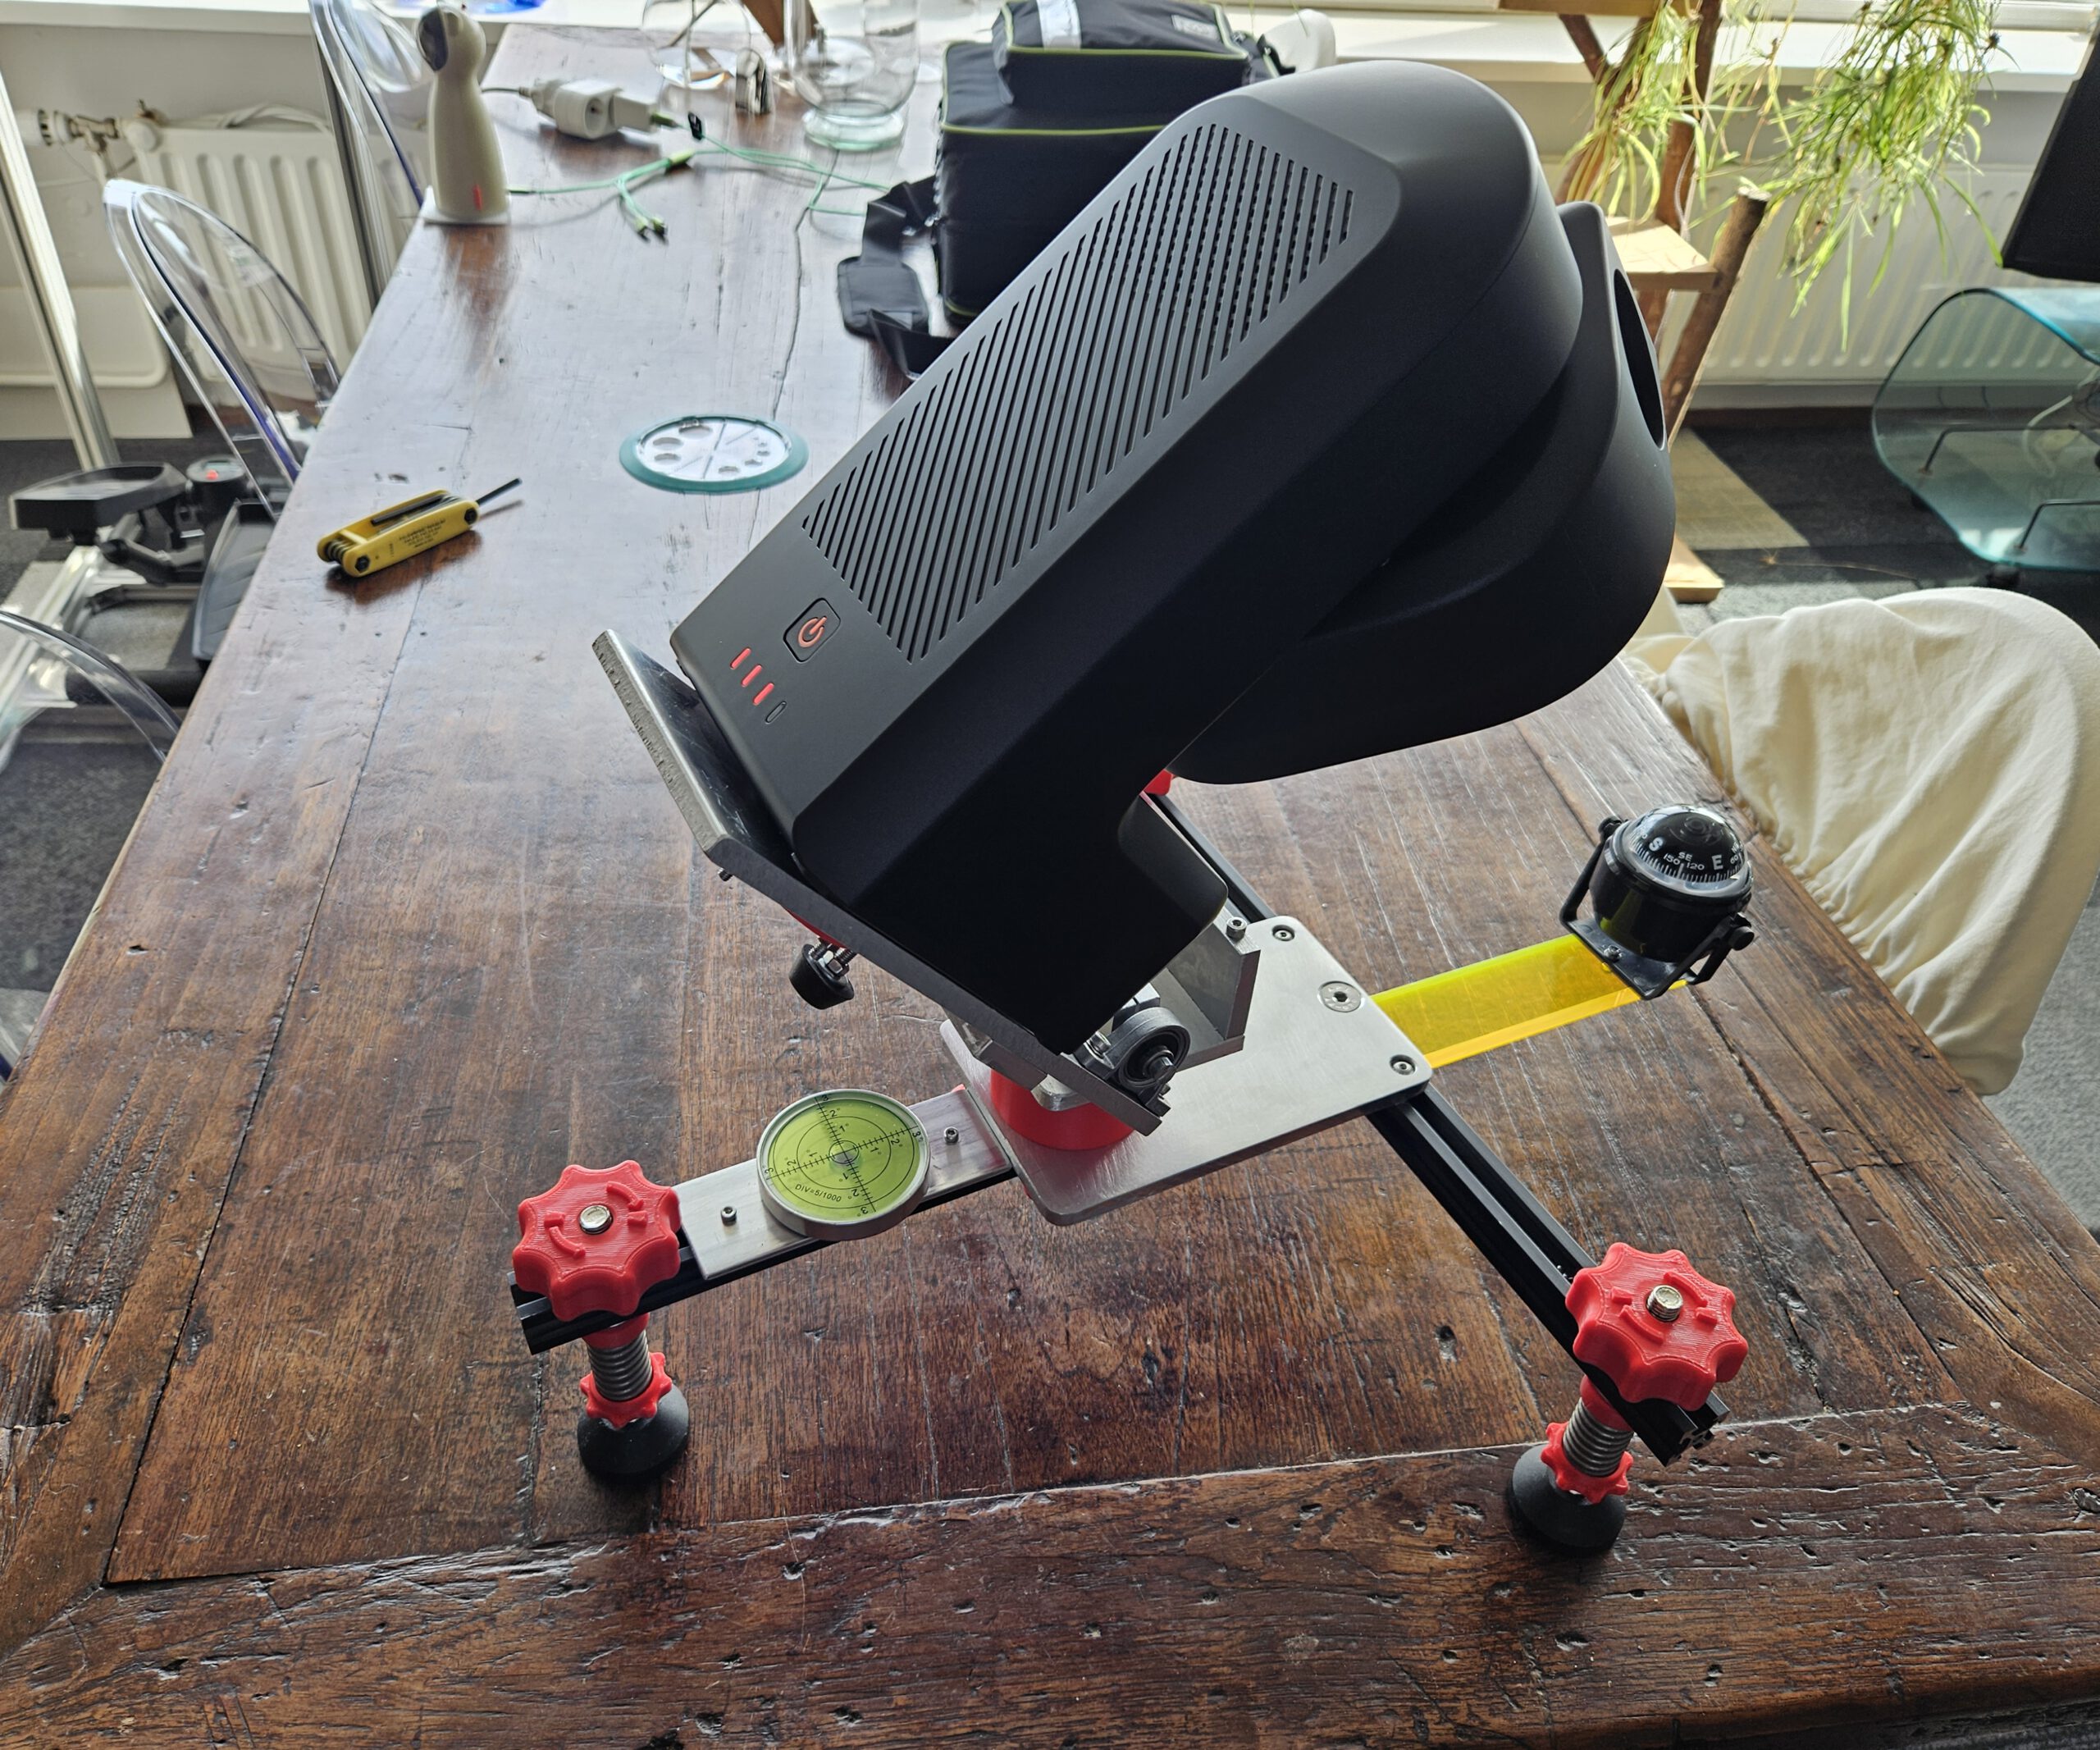
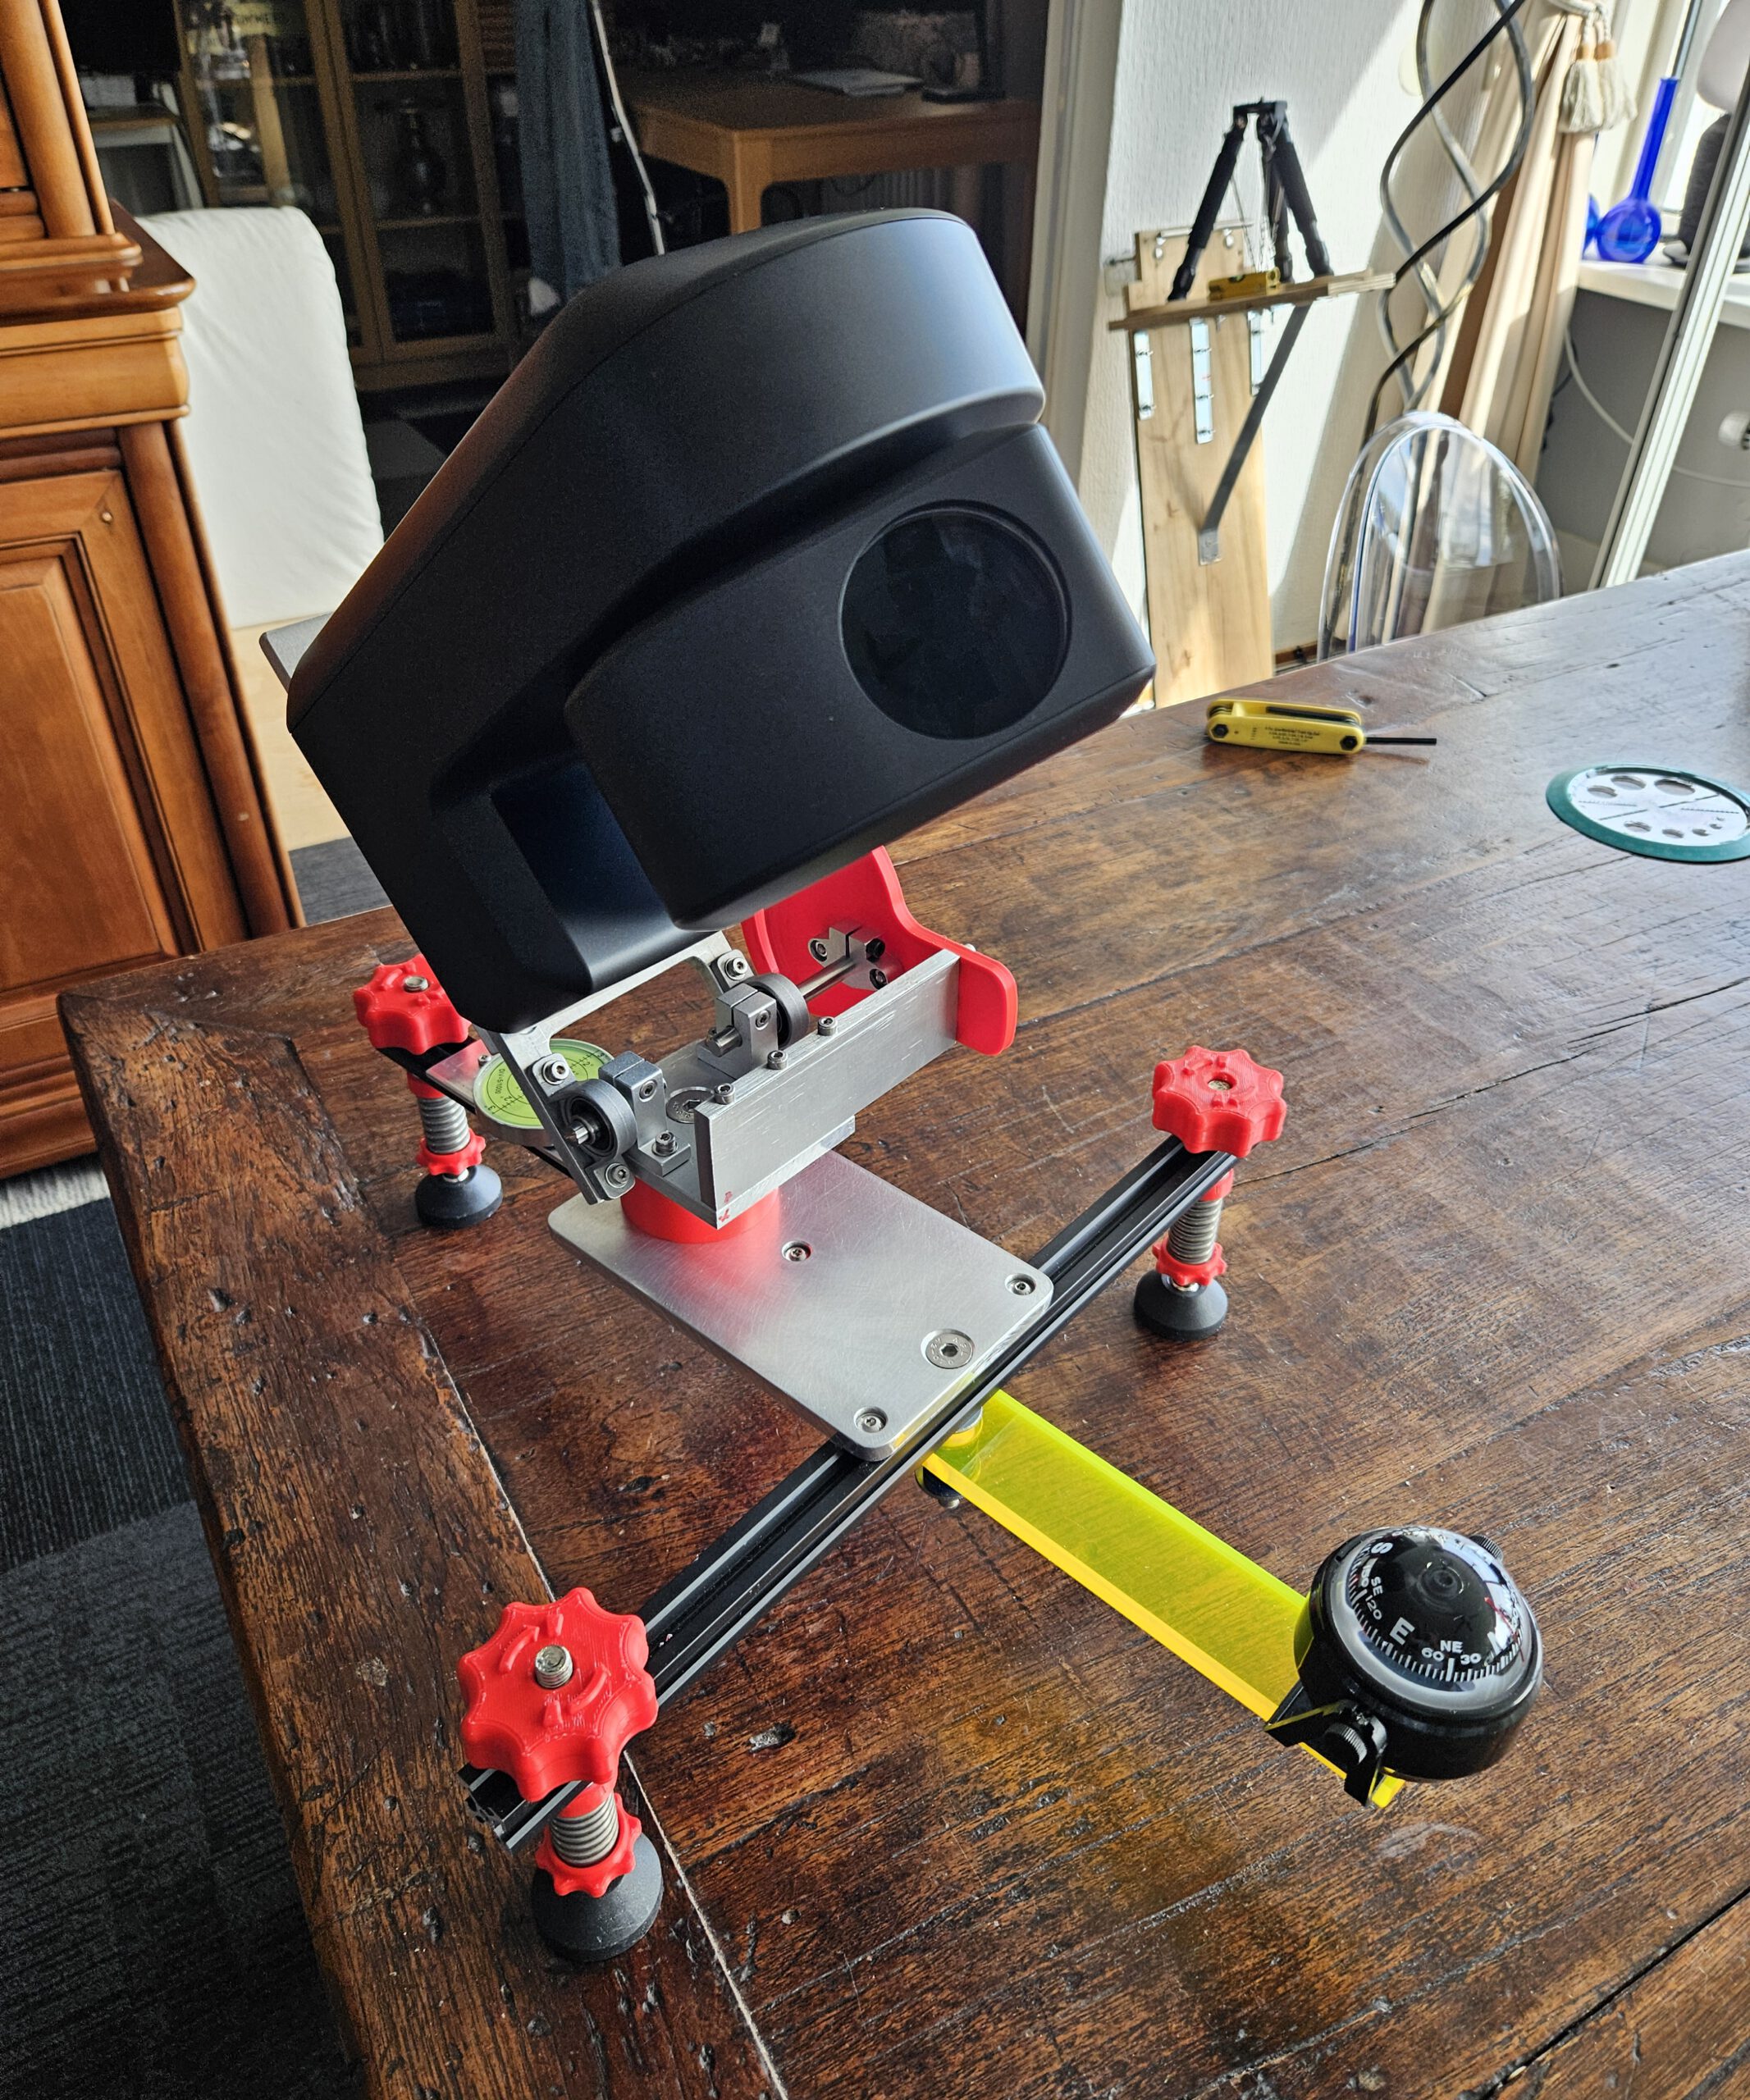
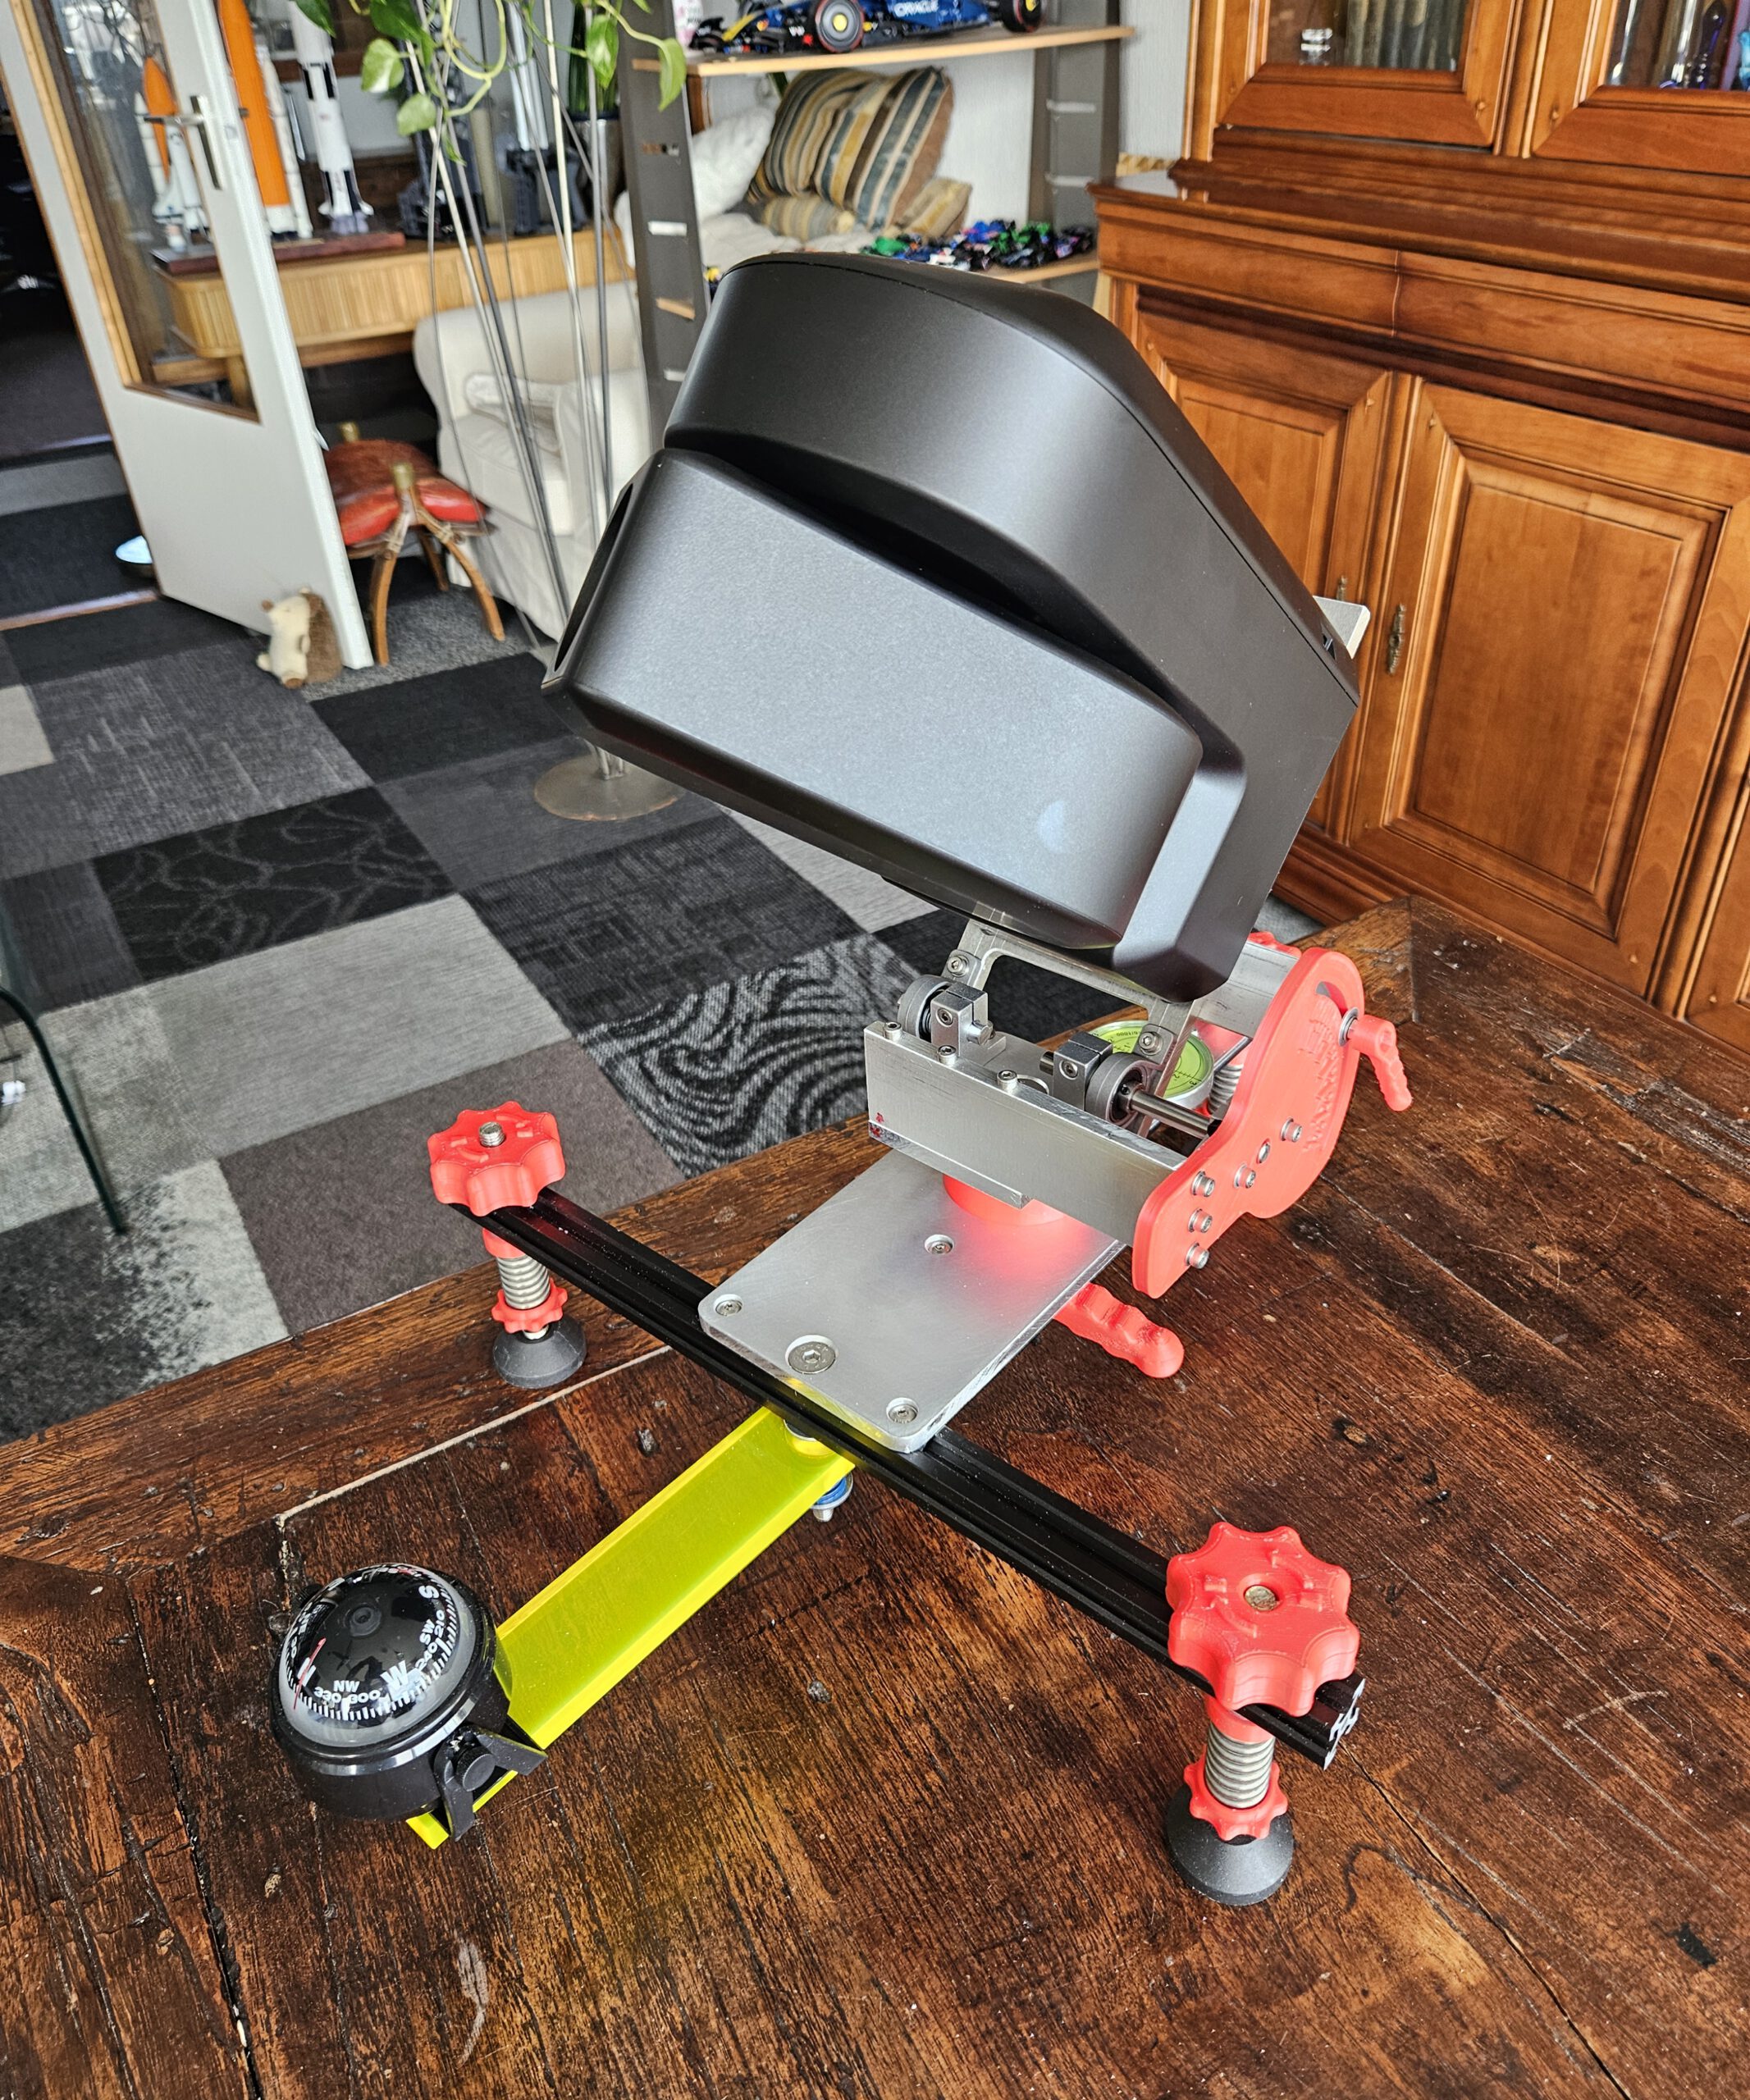
The Seestar S50 is a compact smart telescope capable of automatically locating and tracking objects in the night sky. In its standard configuration it operates as an alt-azimuth telescope, tracking an object by moving in both altitude and azimuth. That works remarkably well, but the Earth still has an annoying habit of rotating. For longer observations and astrophotography, an equatorial setup has an important advantage: instead of continuously correcting two axes, the telescope’s primary rotation axis is aligned parallel to the Earth’s rotational axis. Tracking the apparent motion of the sky can then essentially be reduced to rotation around a single axis. So rather than buying an equatorial wedge or mount, I decided to design and build one specifically for my Seestar S50.
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
How does it work
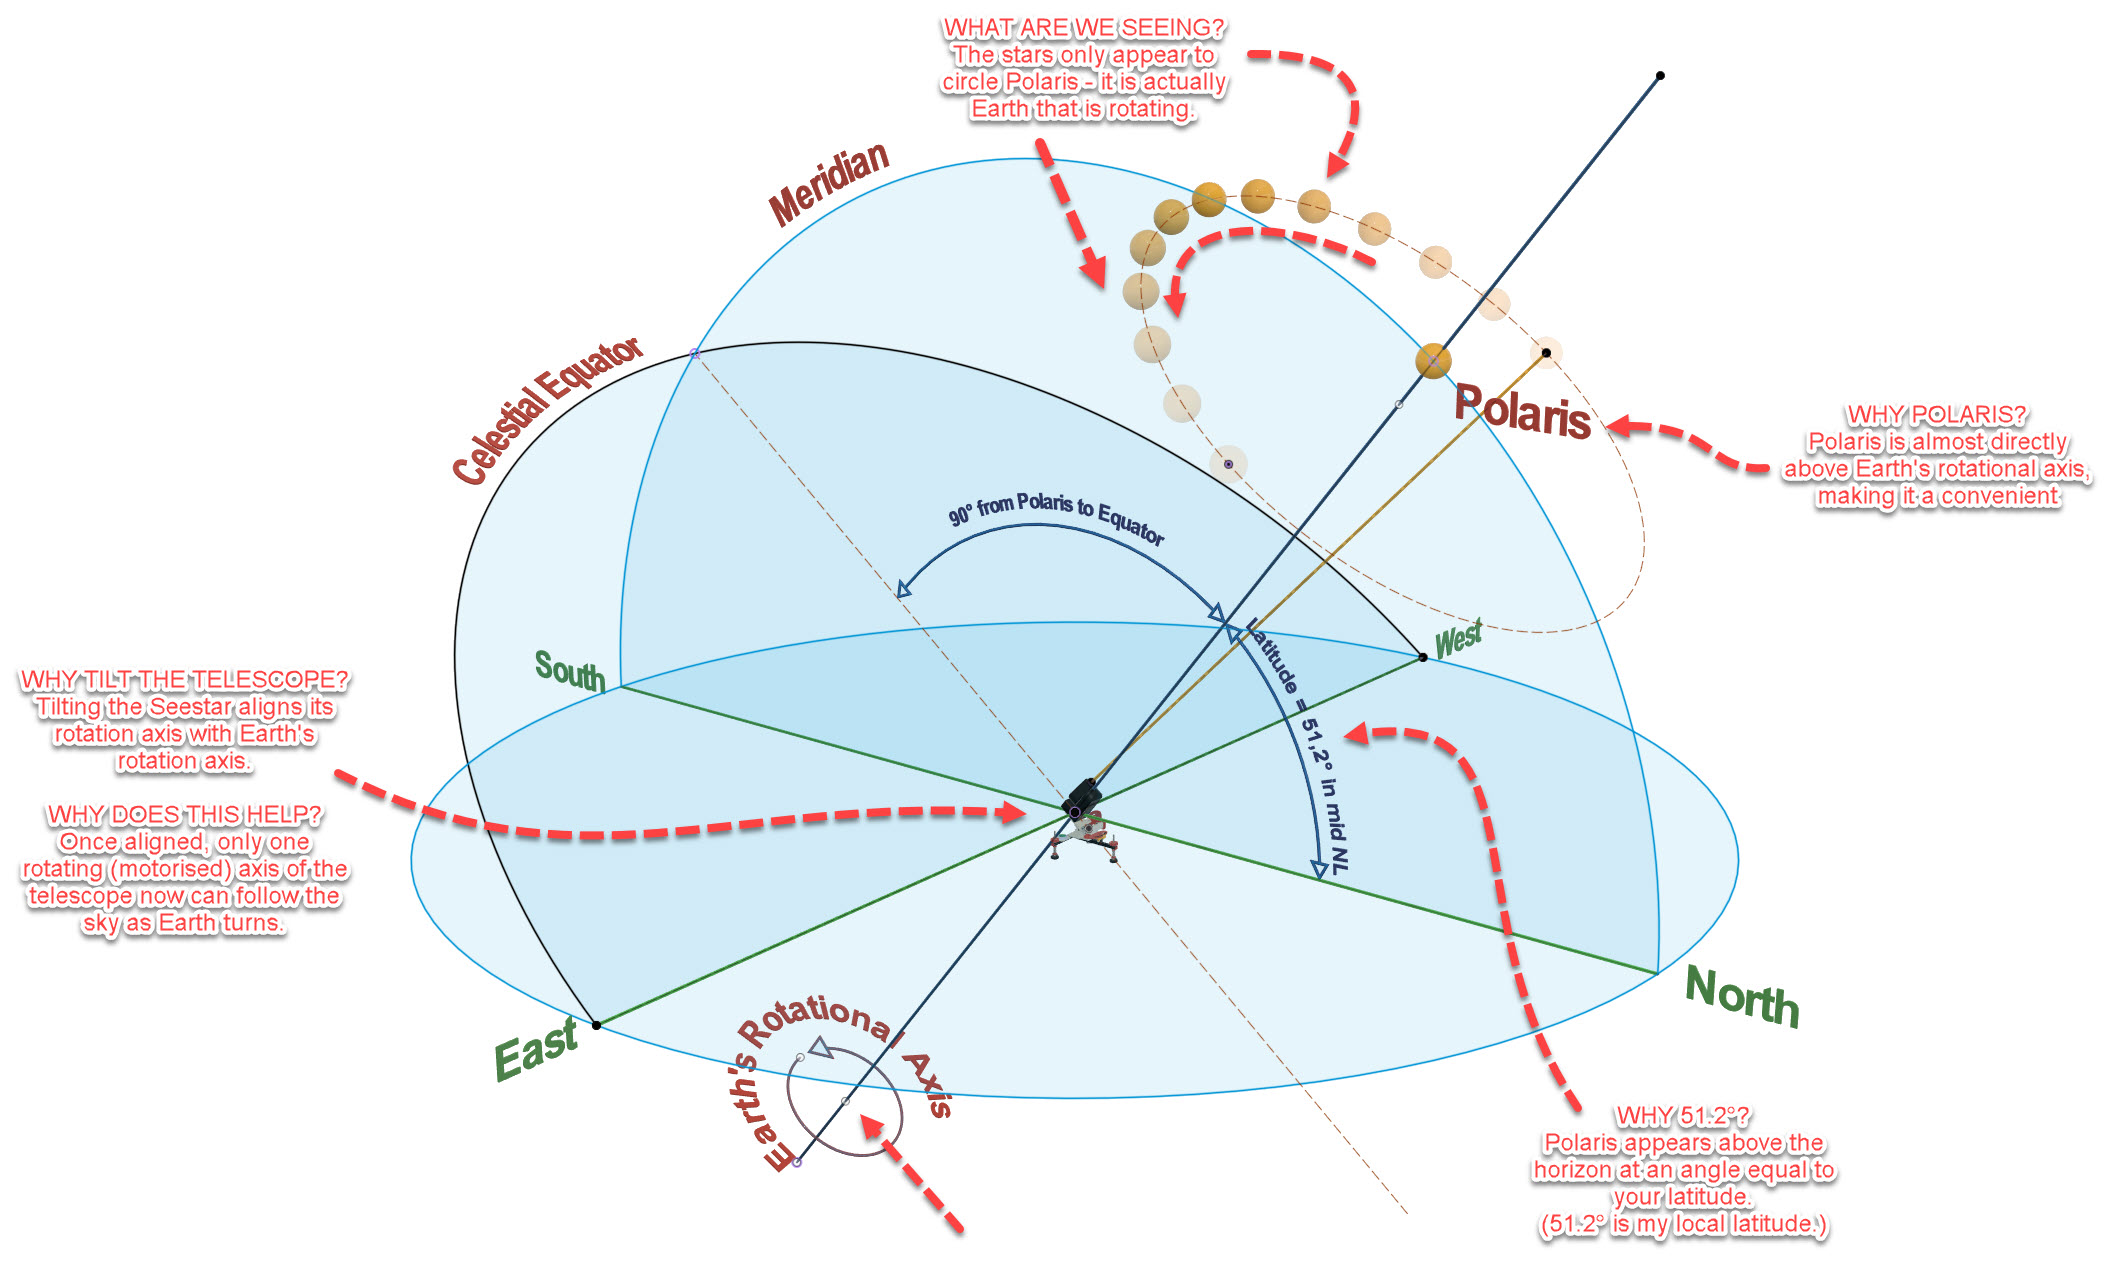
The stars appear to move across the night sky because the Earth rotates. Polaris lies very close to the Earth’s rotational axis and therefore appears almost stationary while the other stars seem to circle around it.
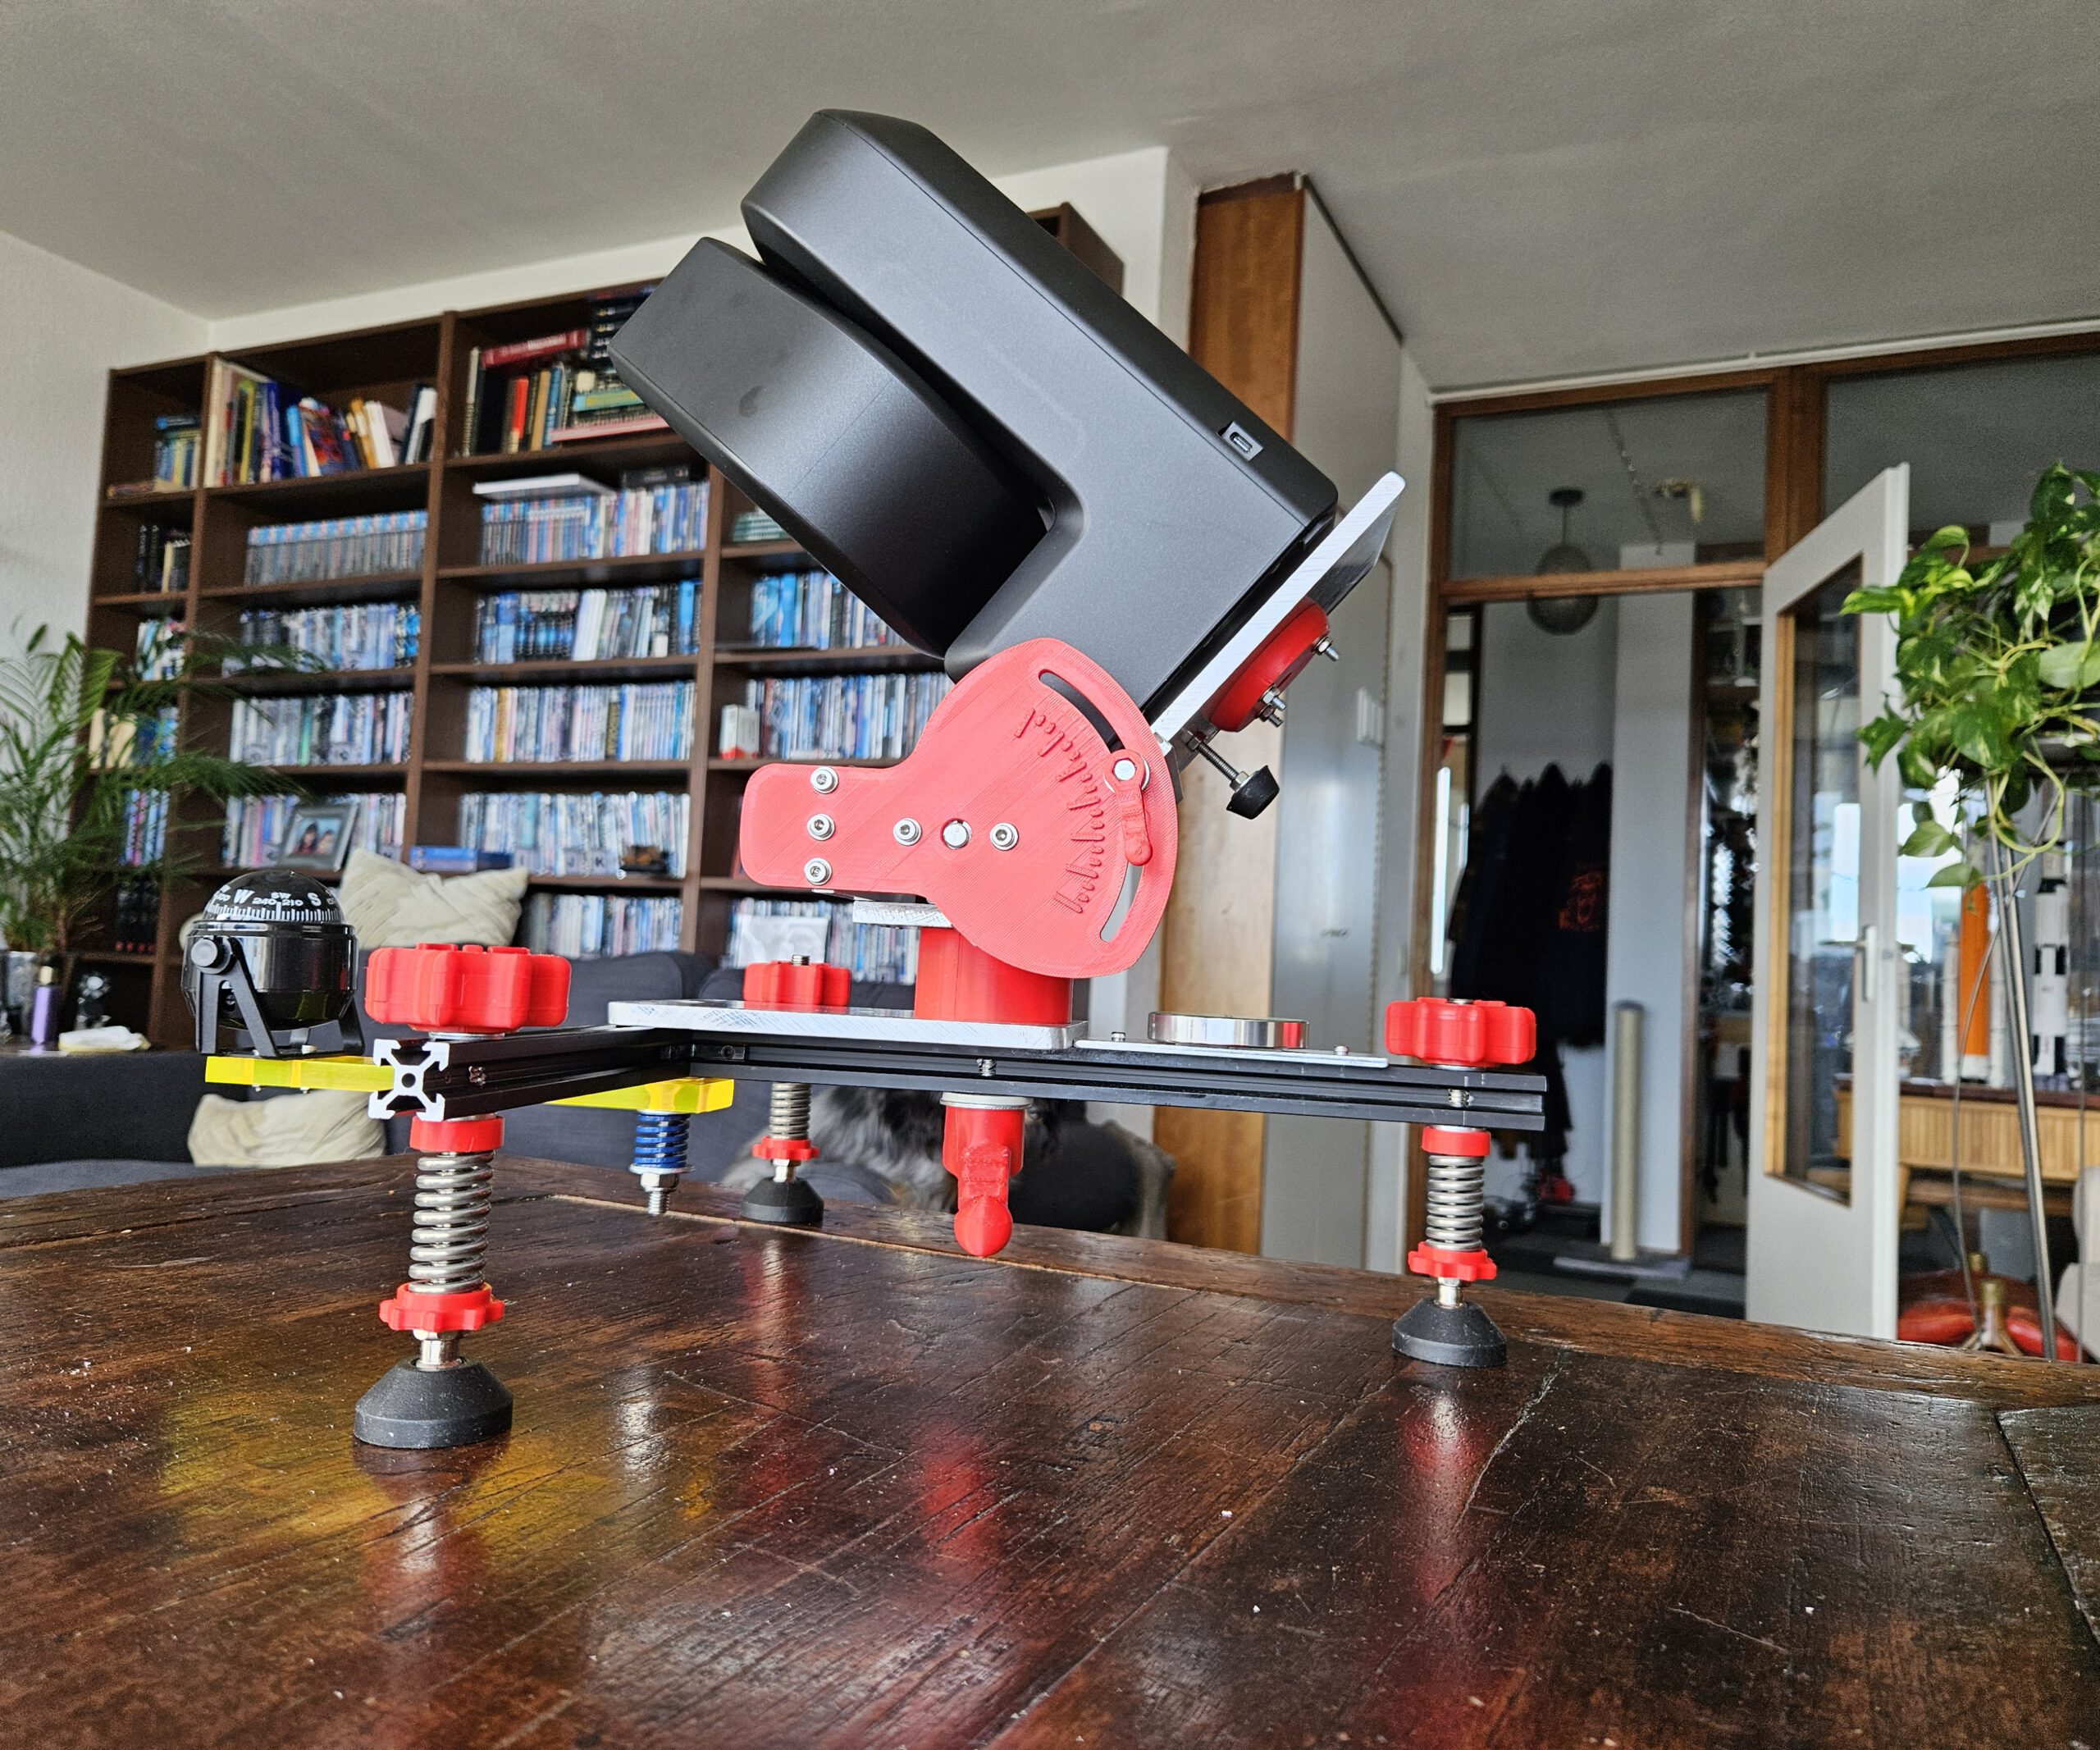
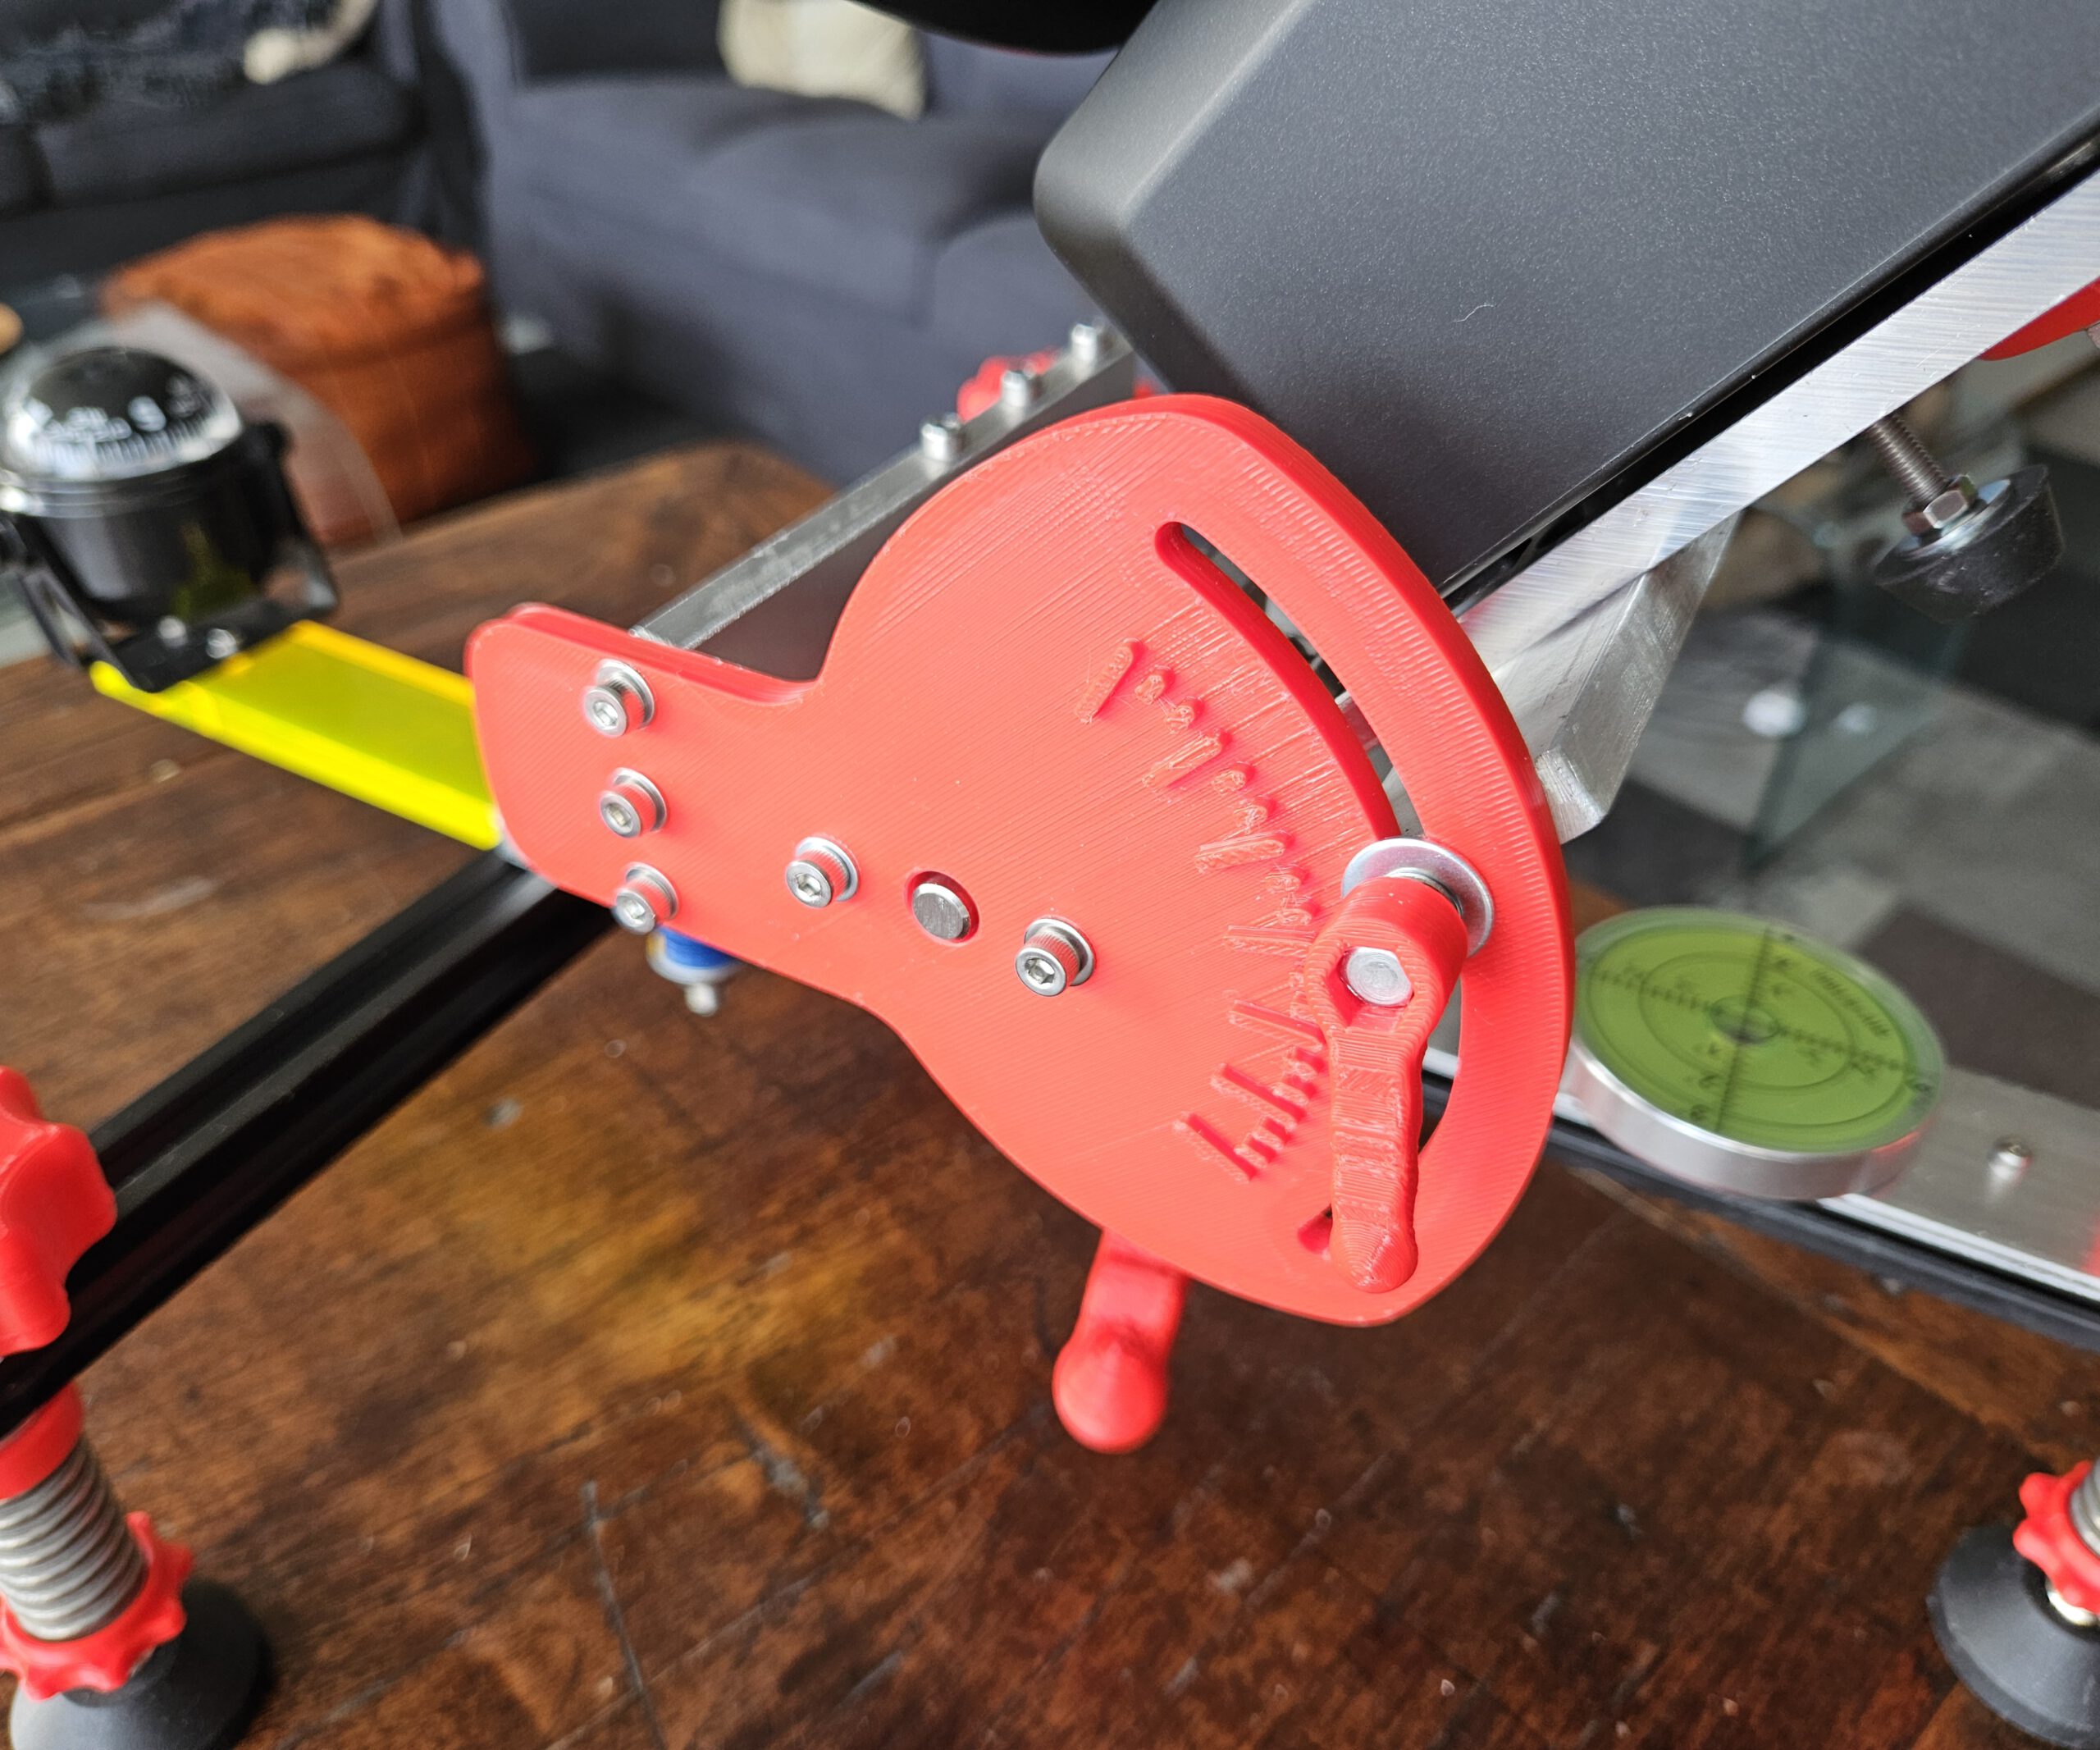
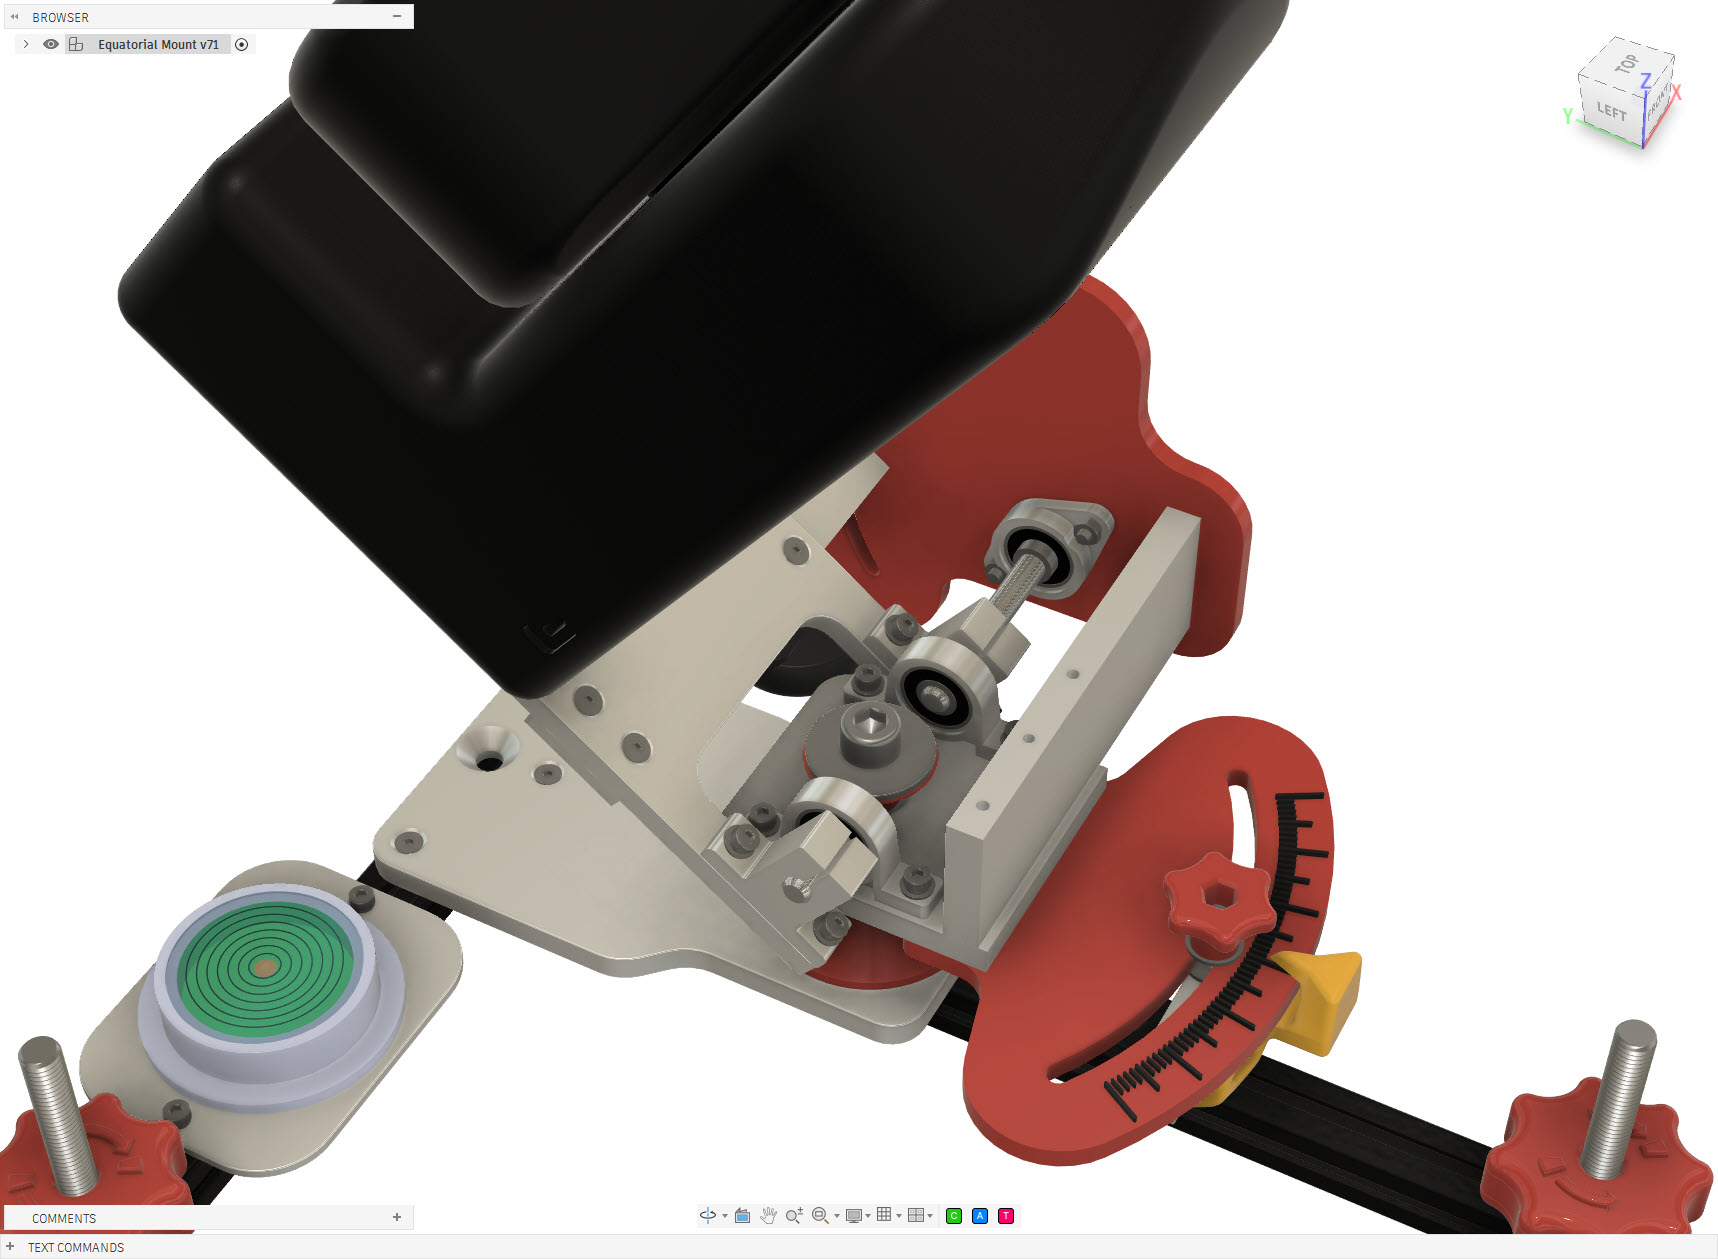
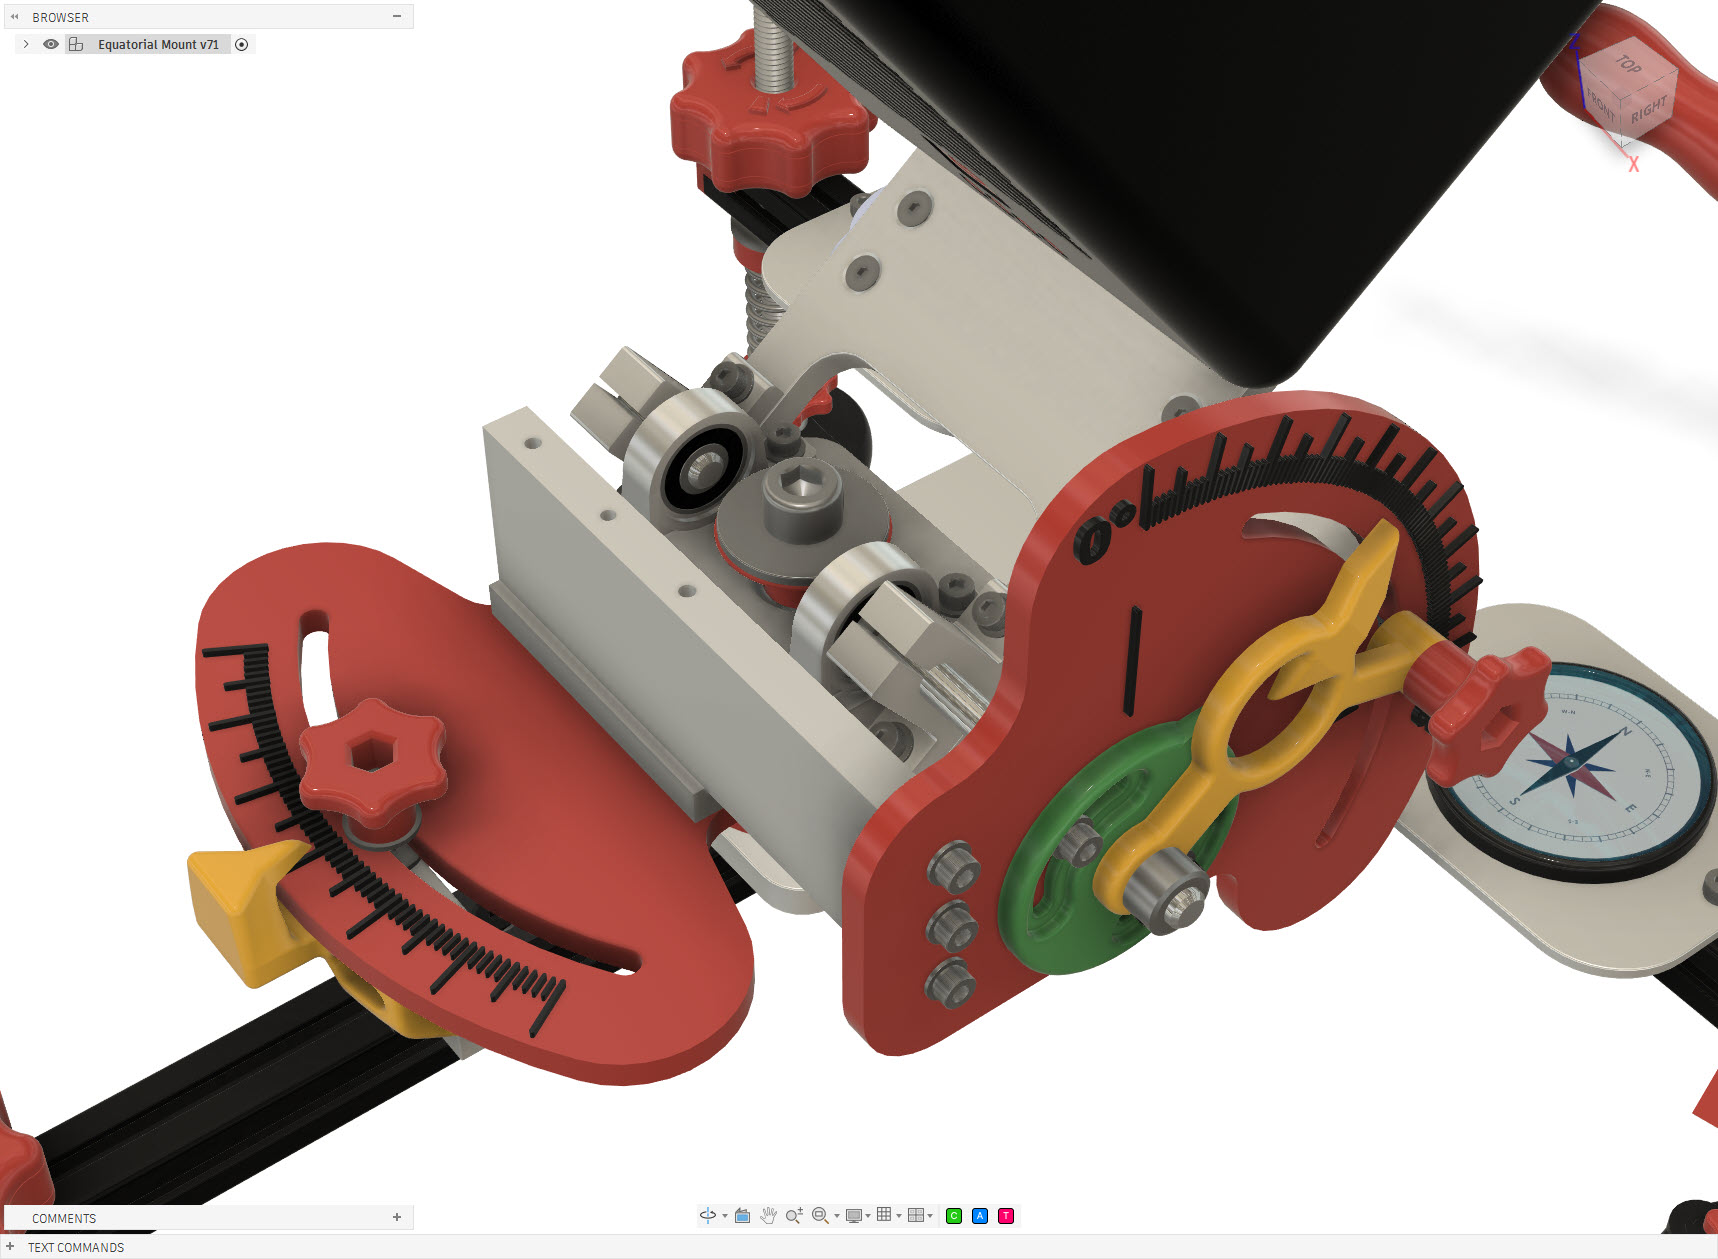
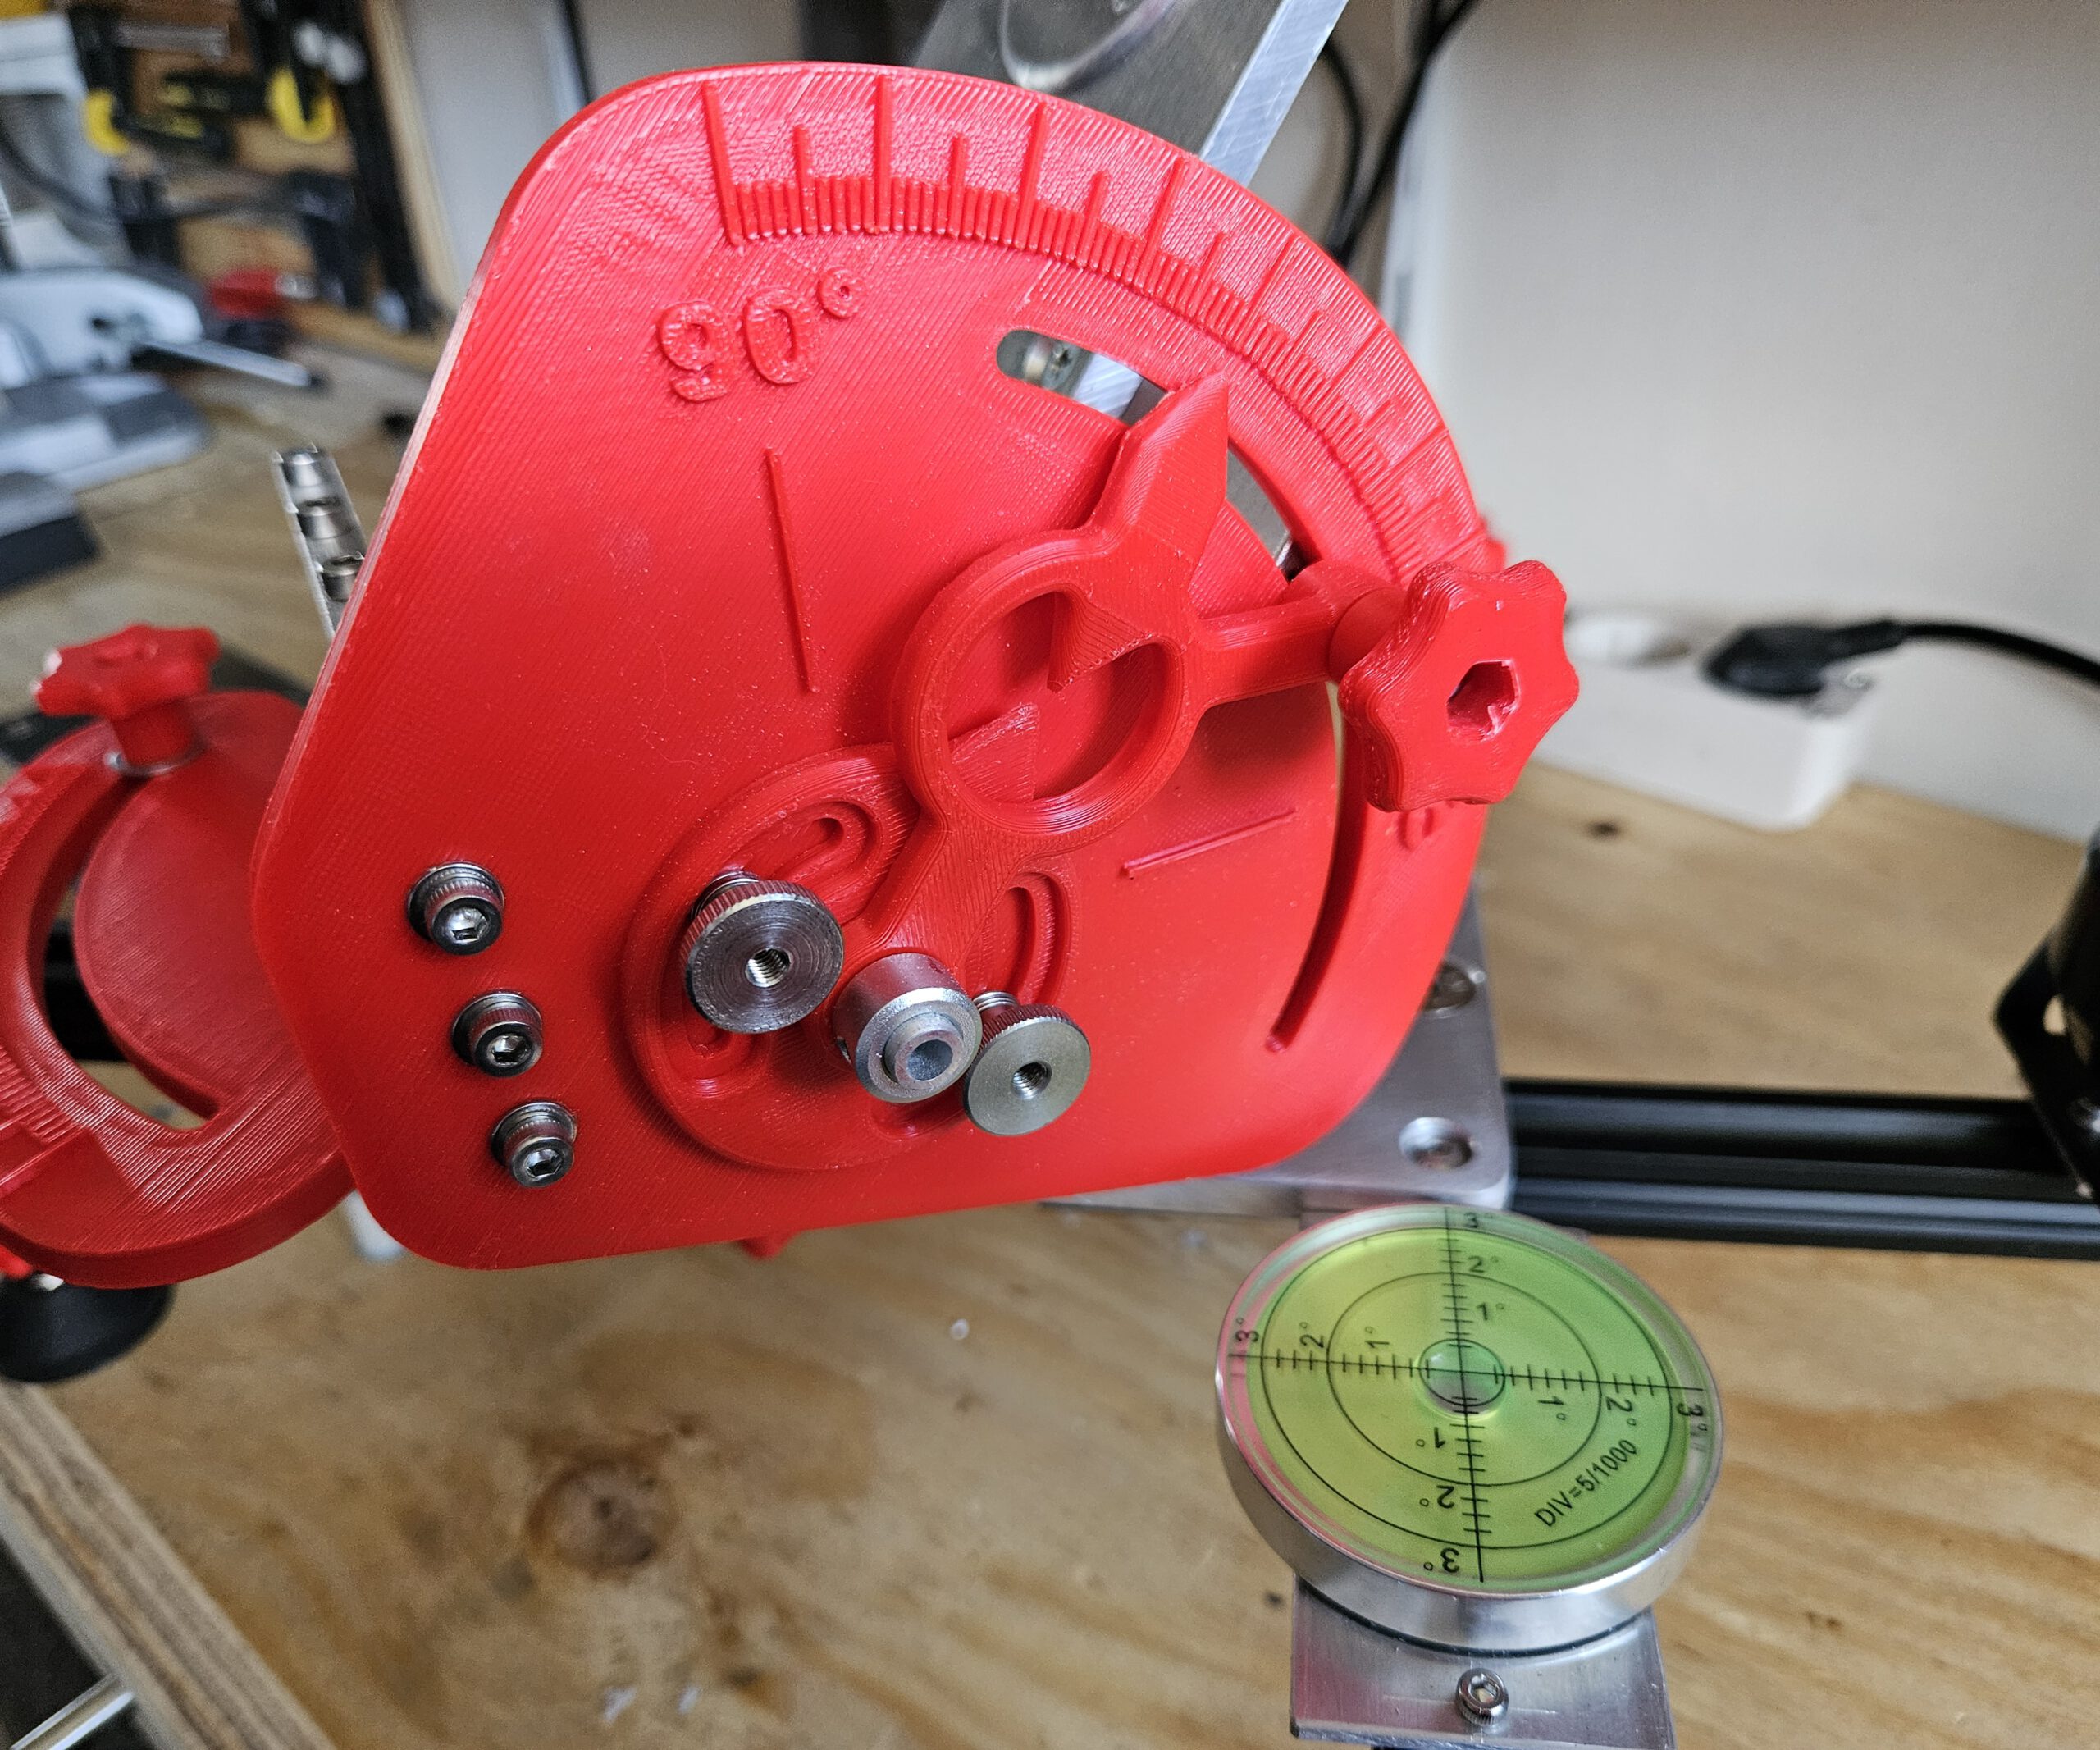
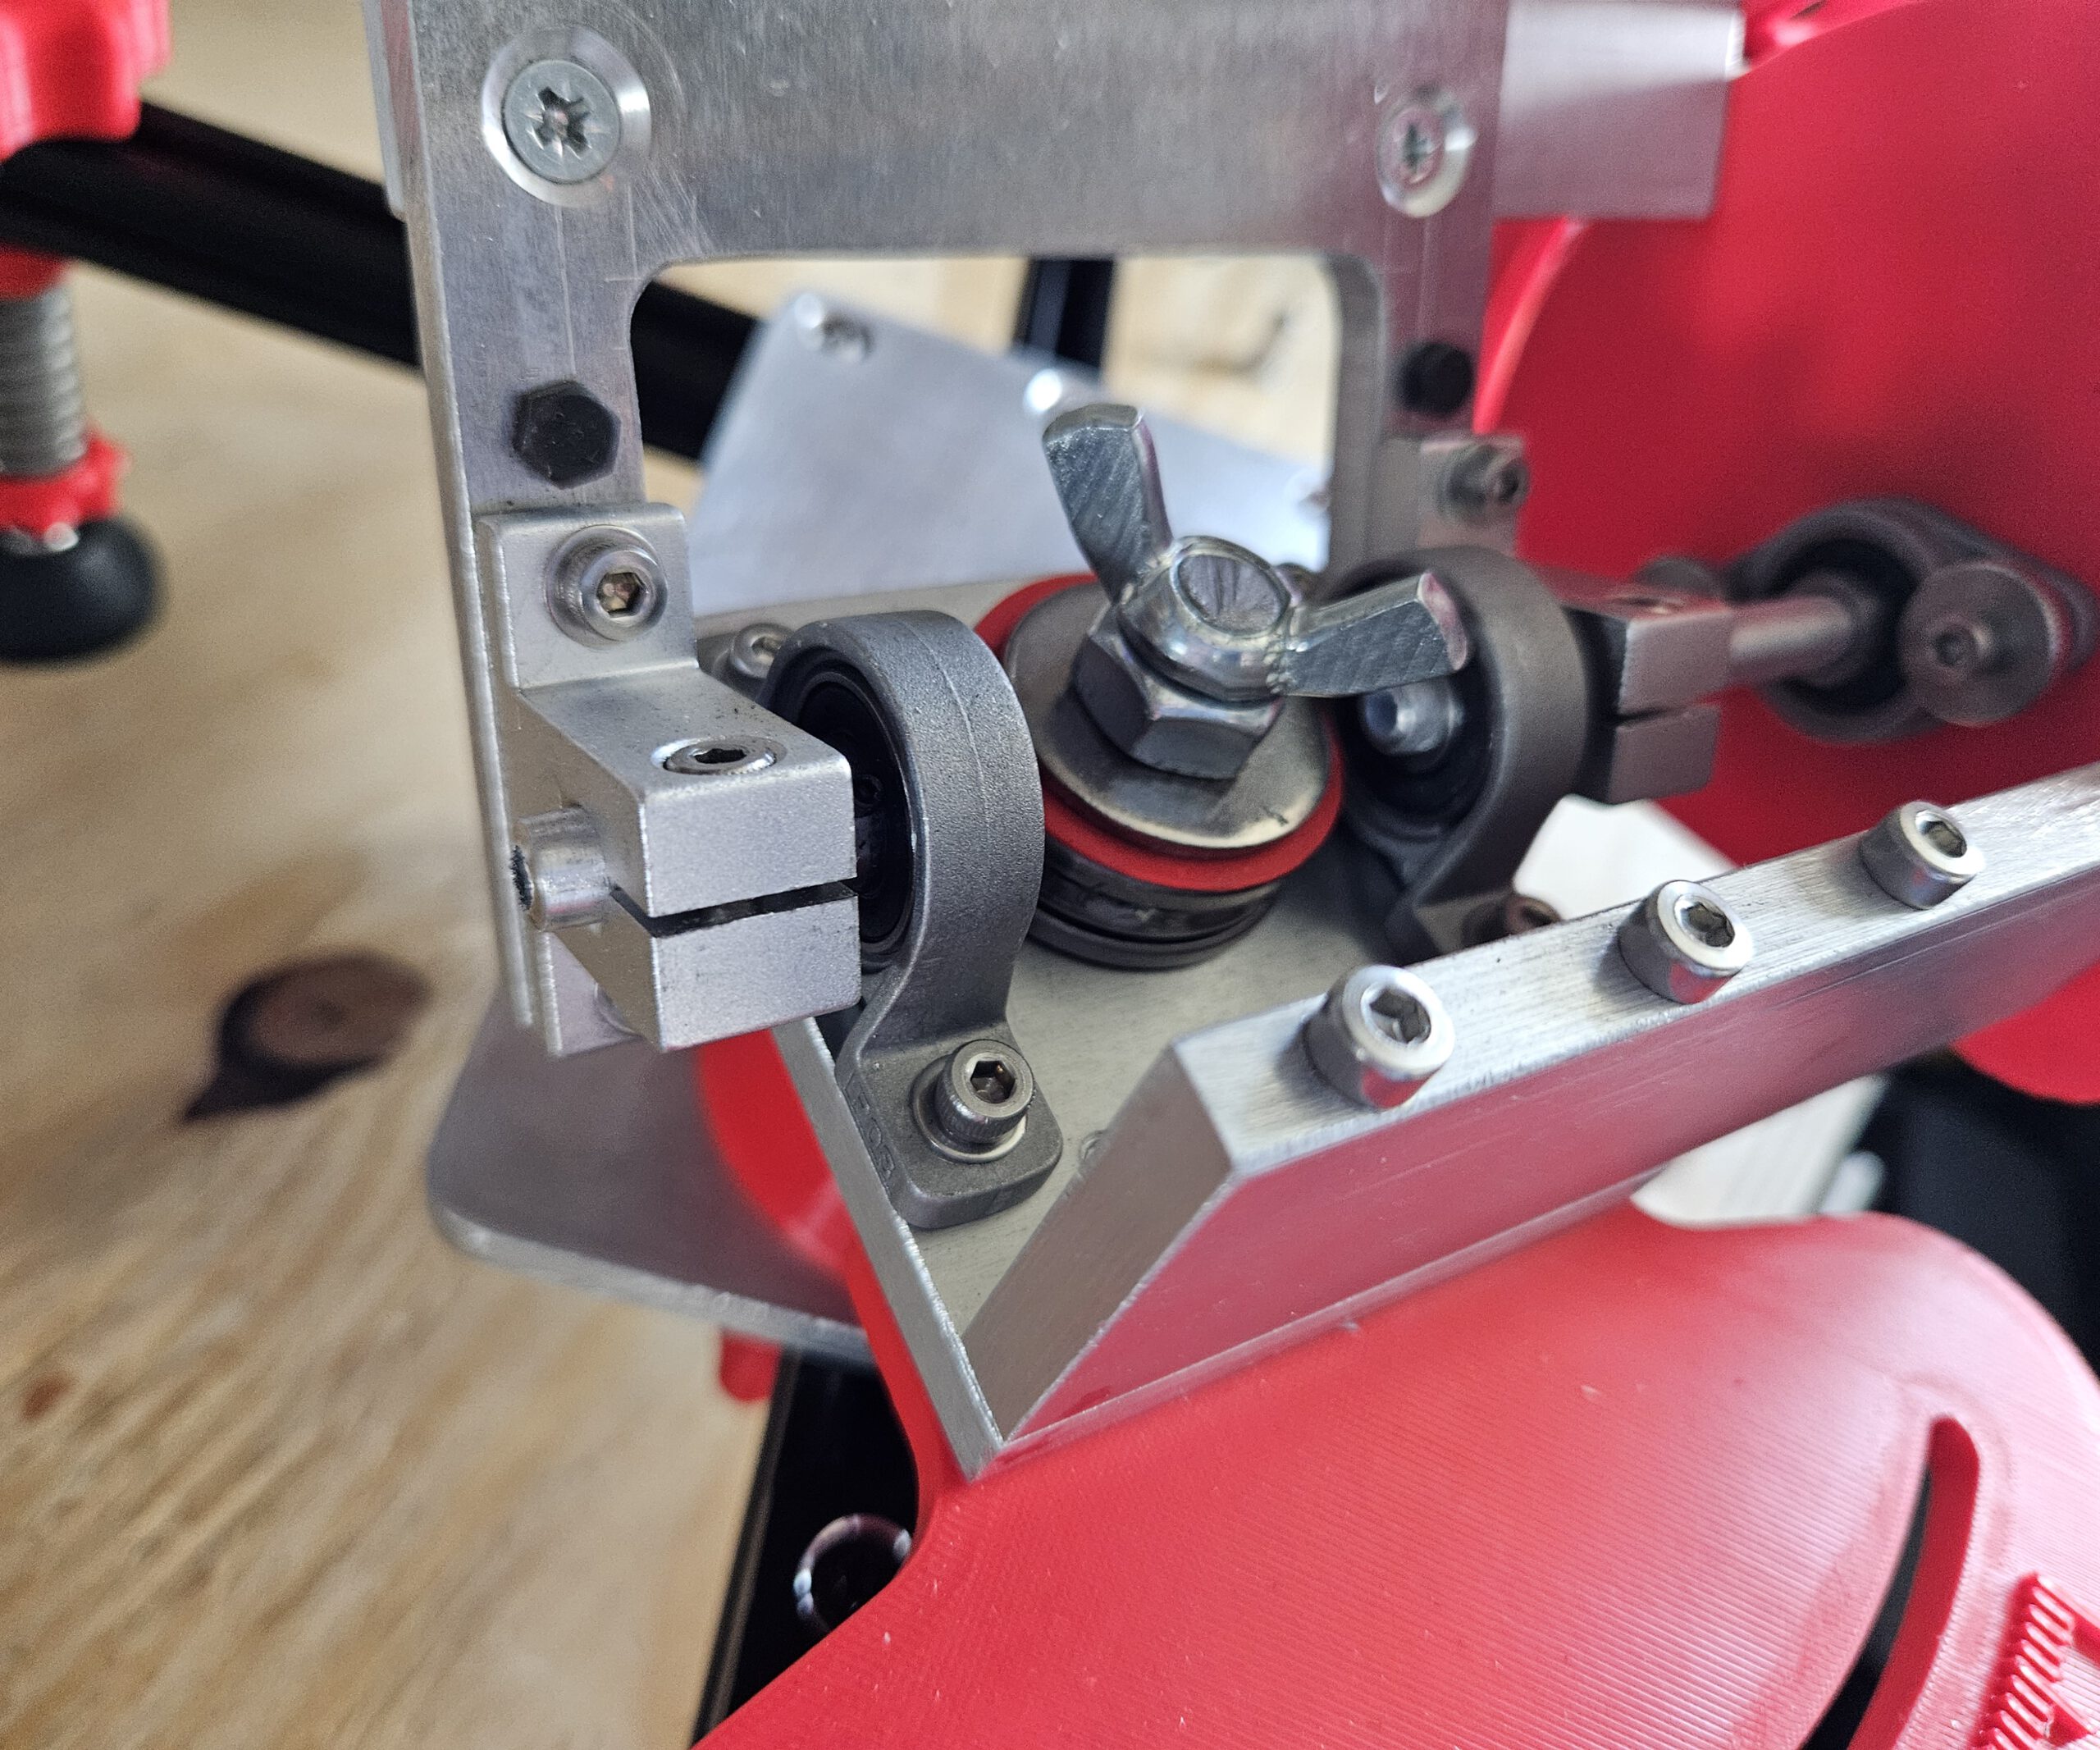
For equatorial tracking, the Seestar’s rotation axis must be aligned parallel to the Earth’s axis. My mount therefore provides adjustment in two directions: altitude sets the angle of the axis to match the local latitude, while azimuth allows the axis to be aimed precisely towards Polaris.
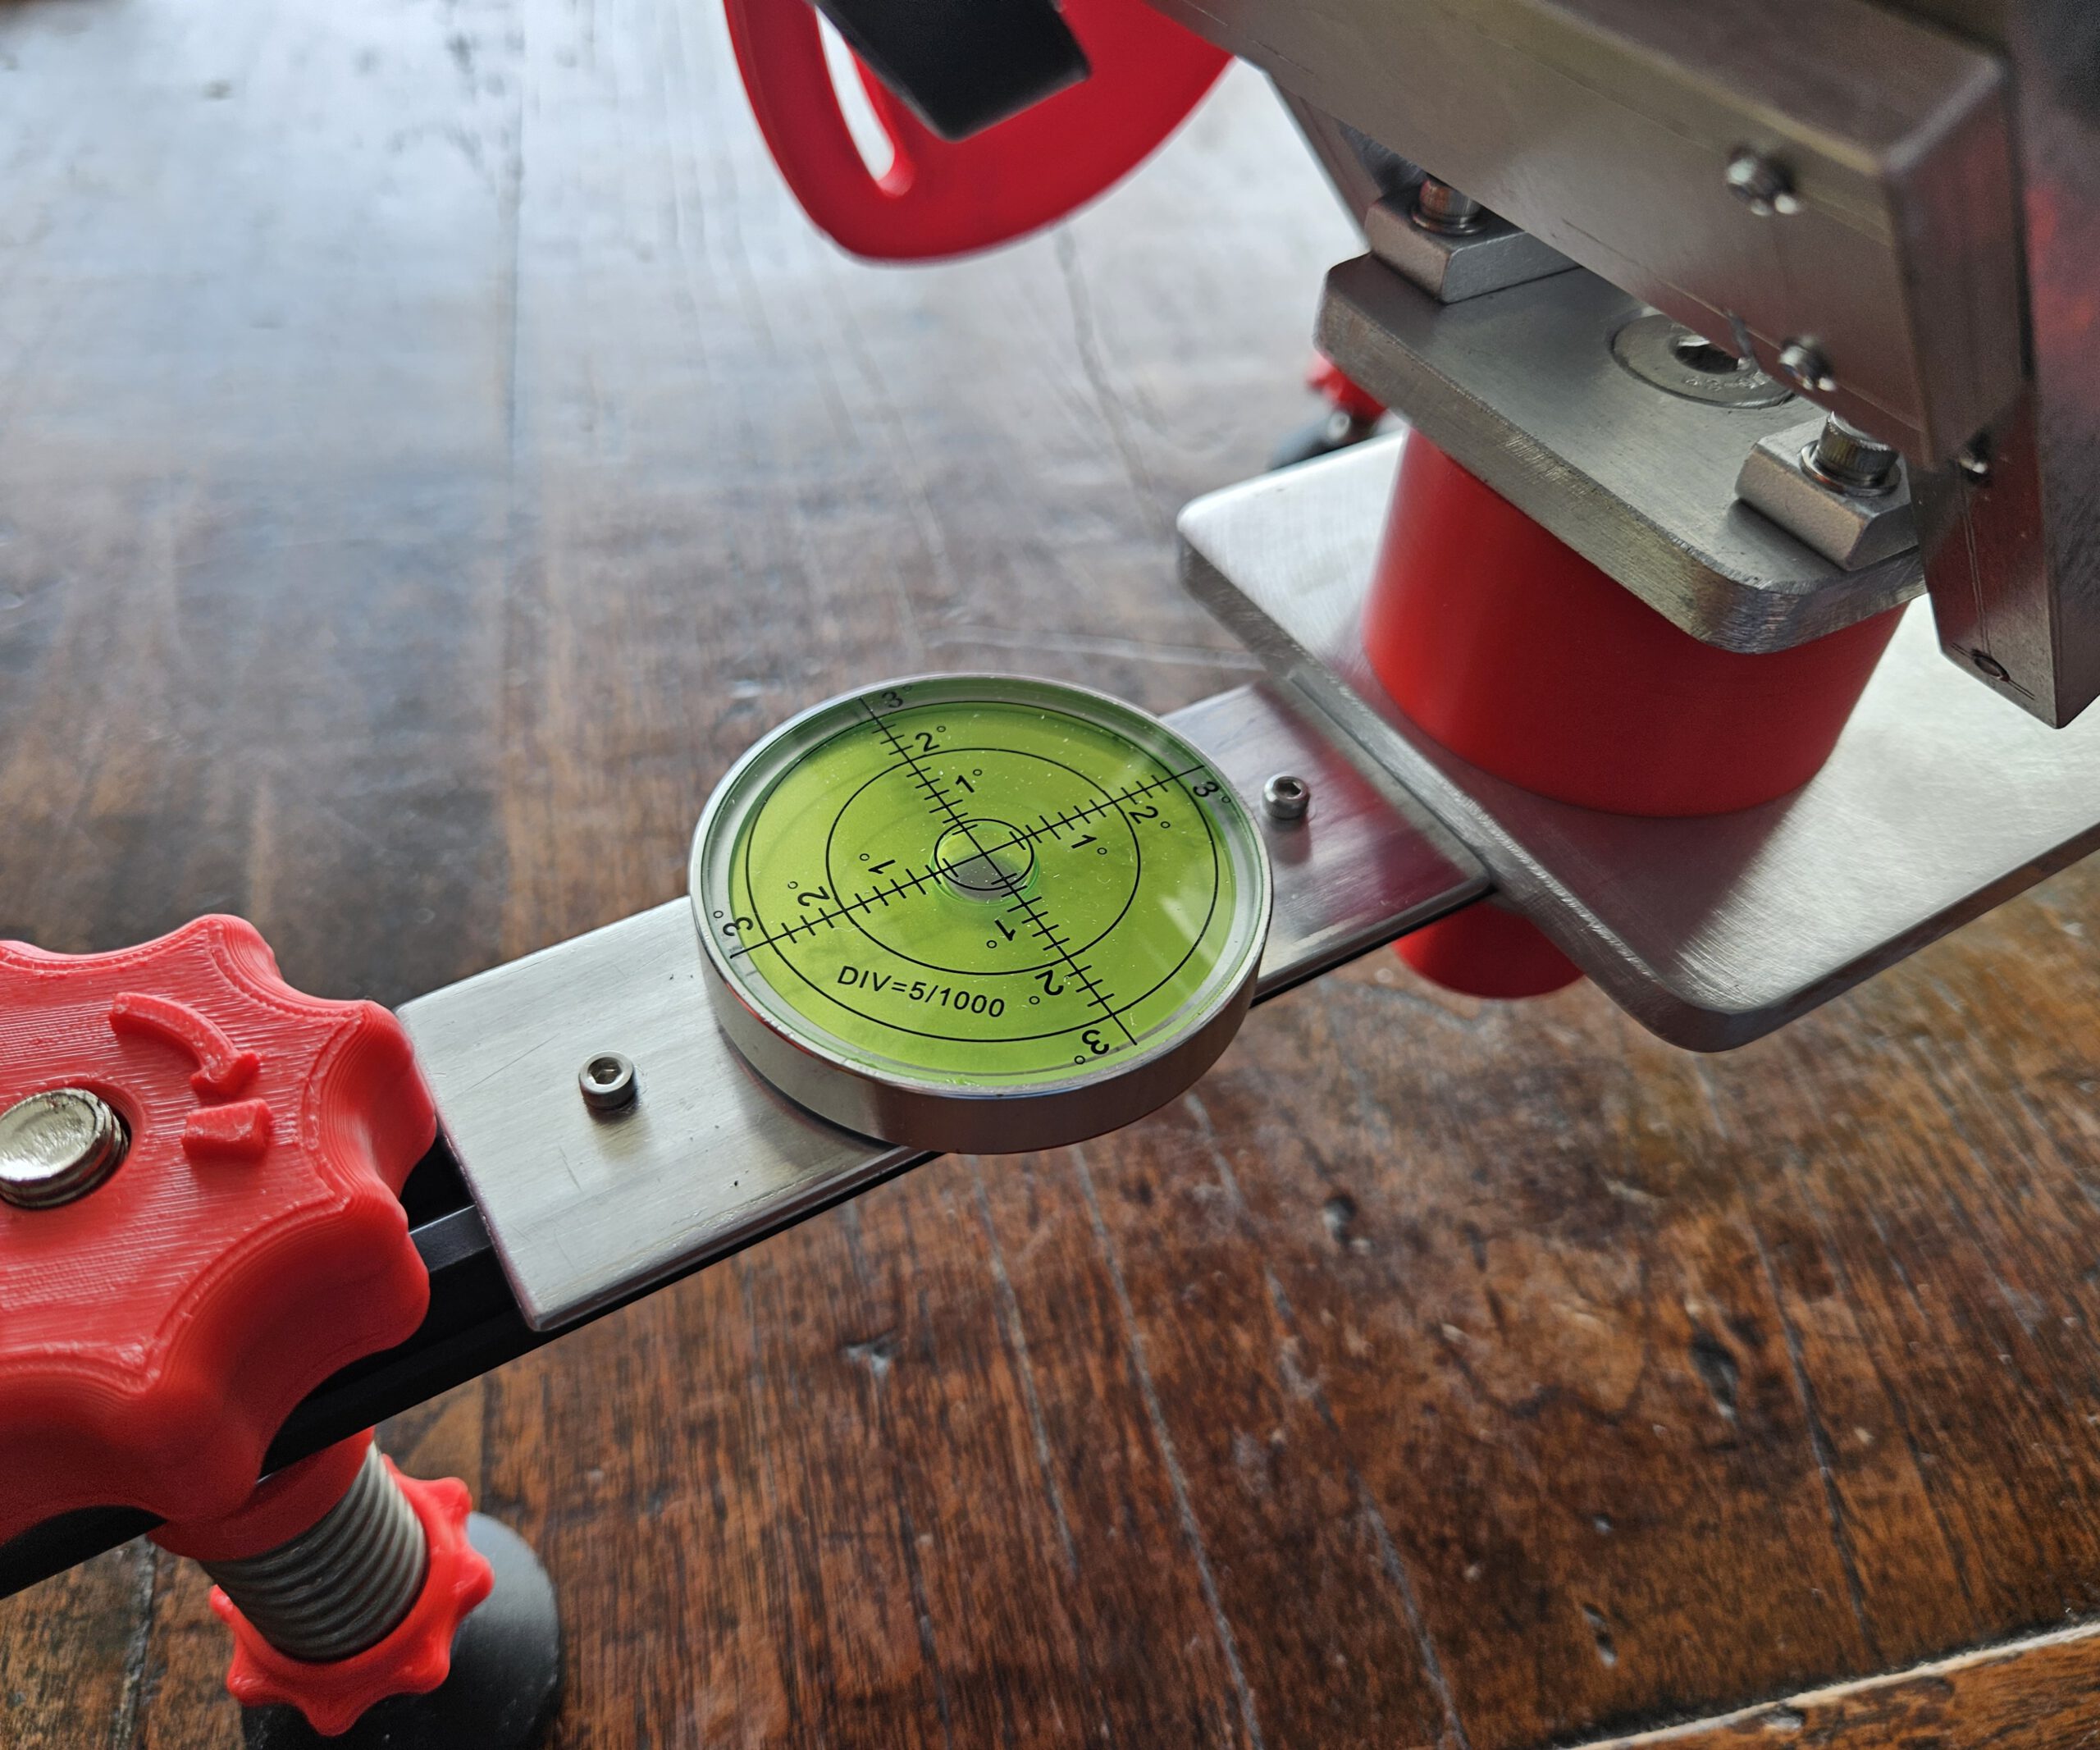
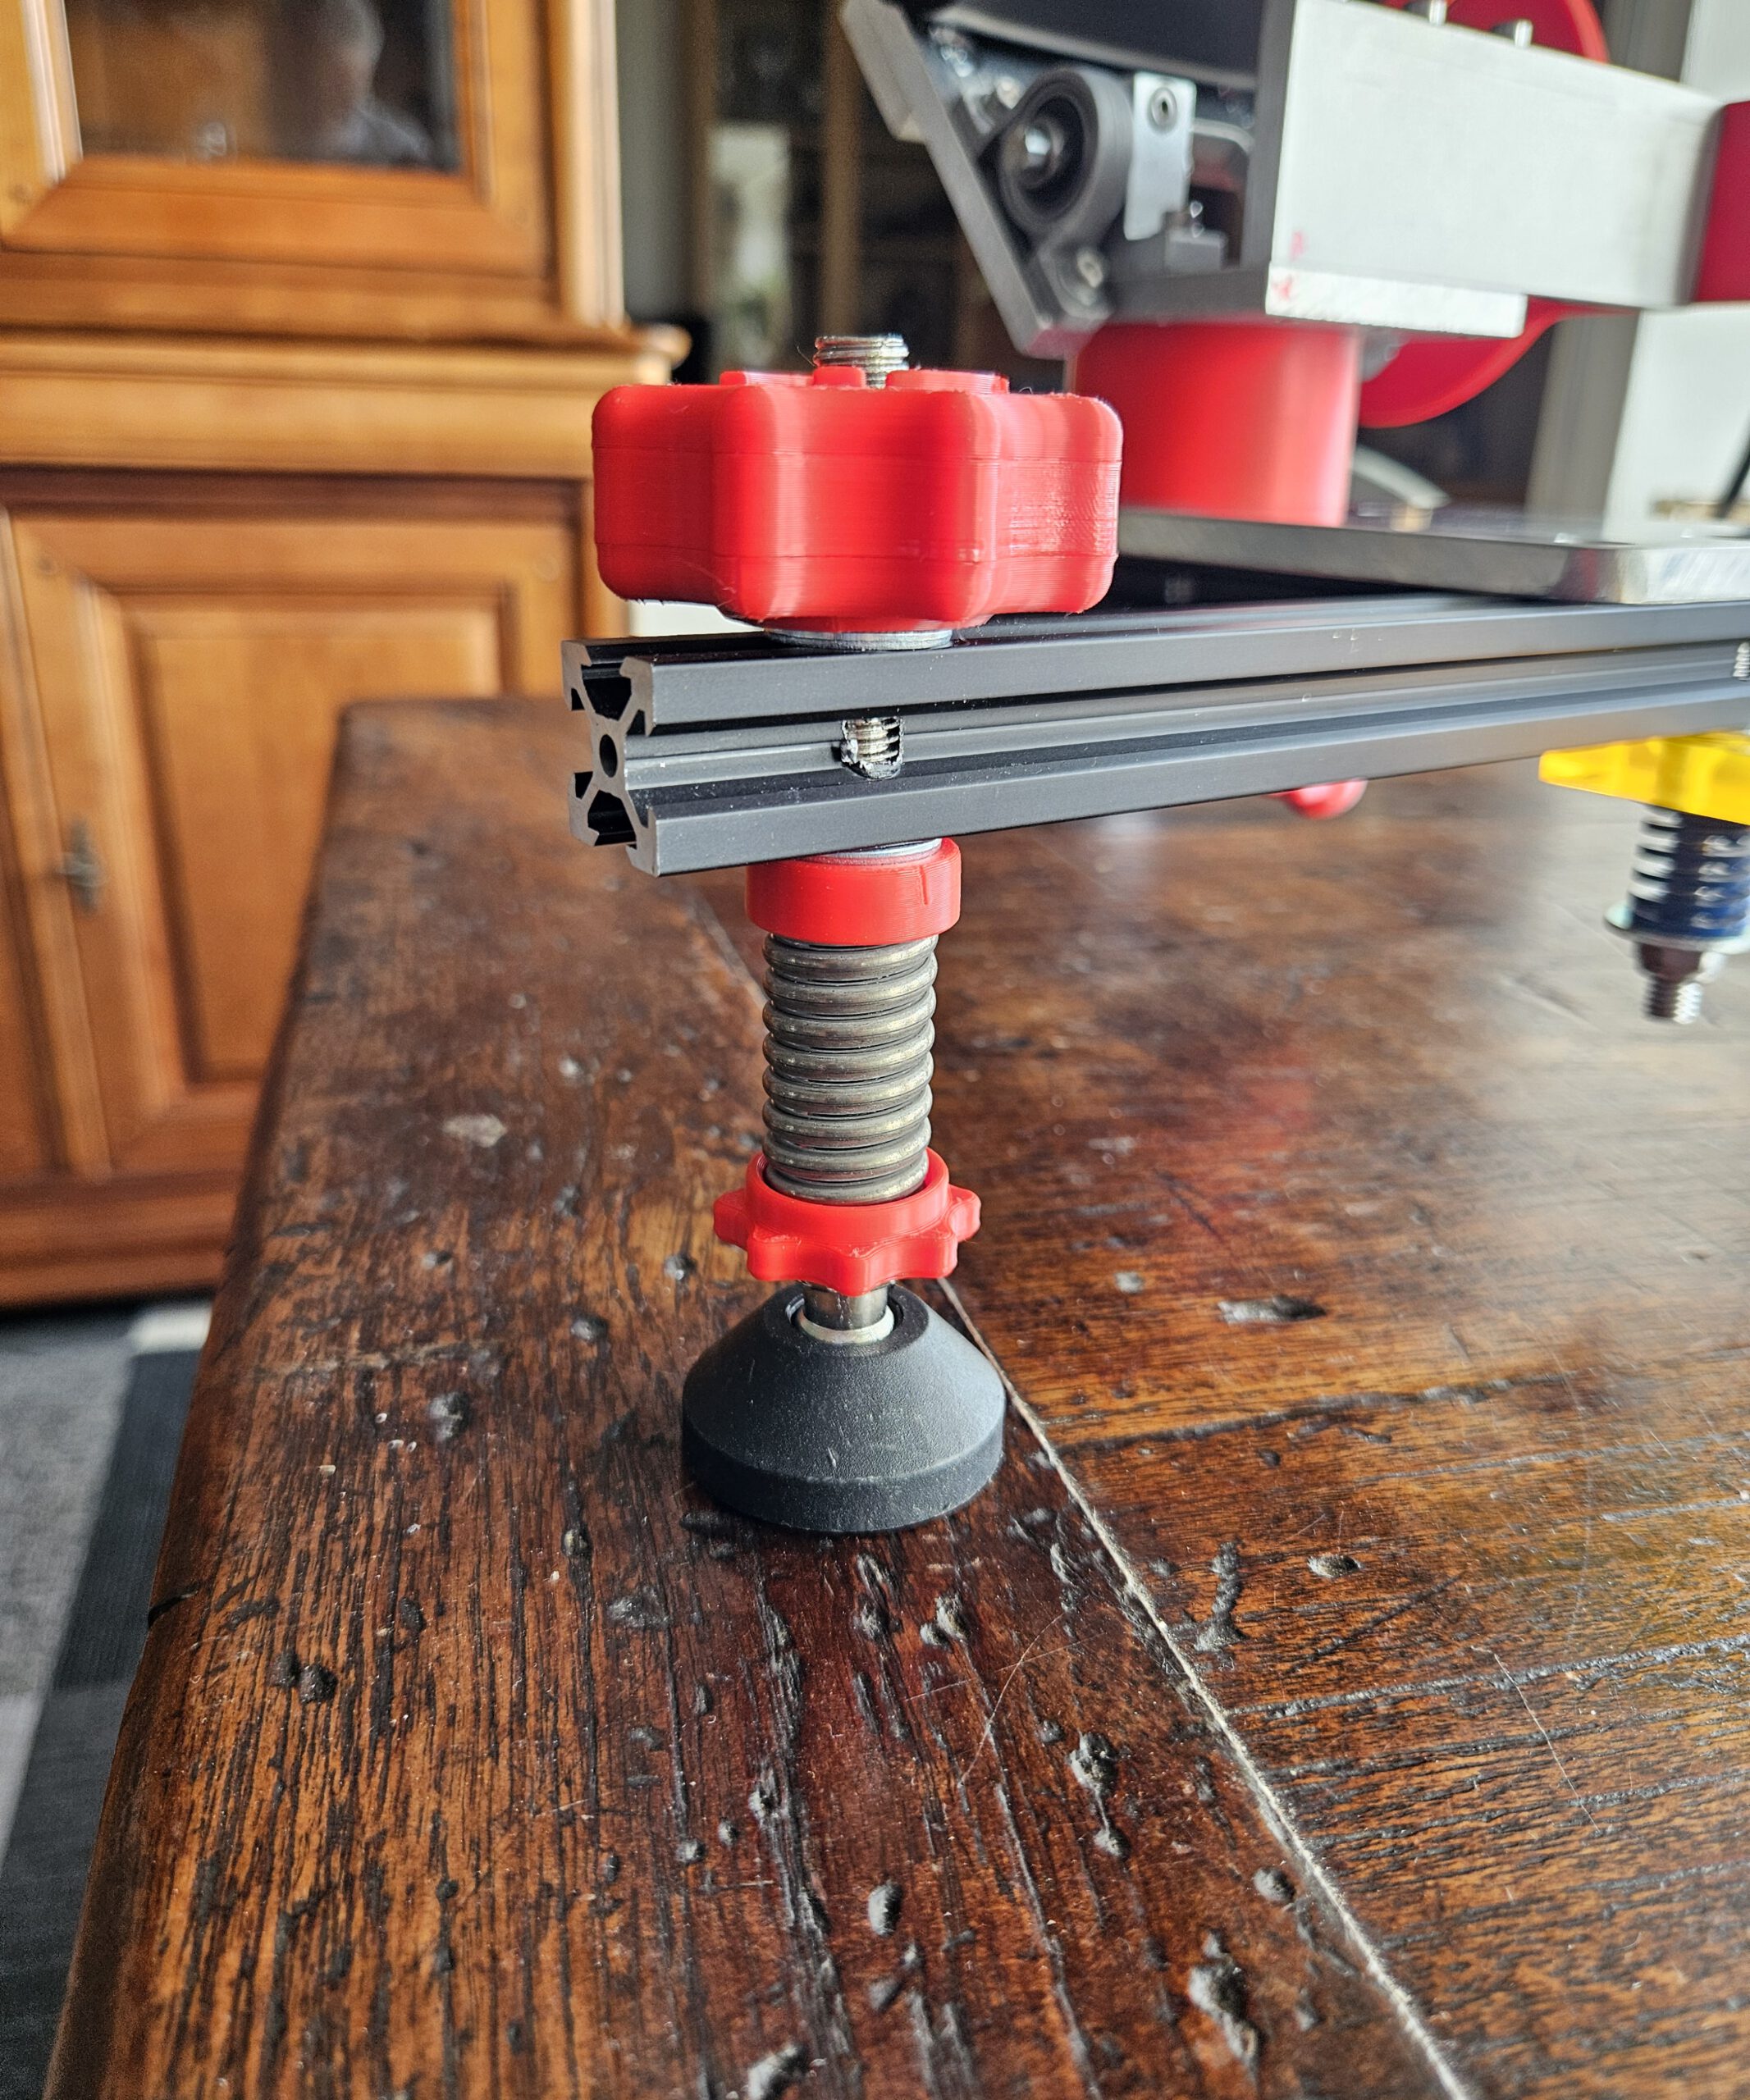
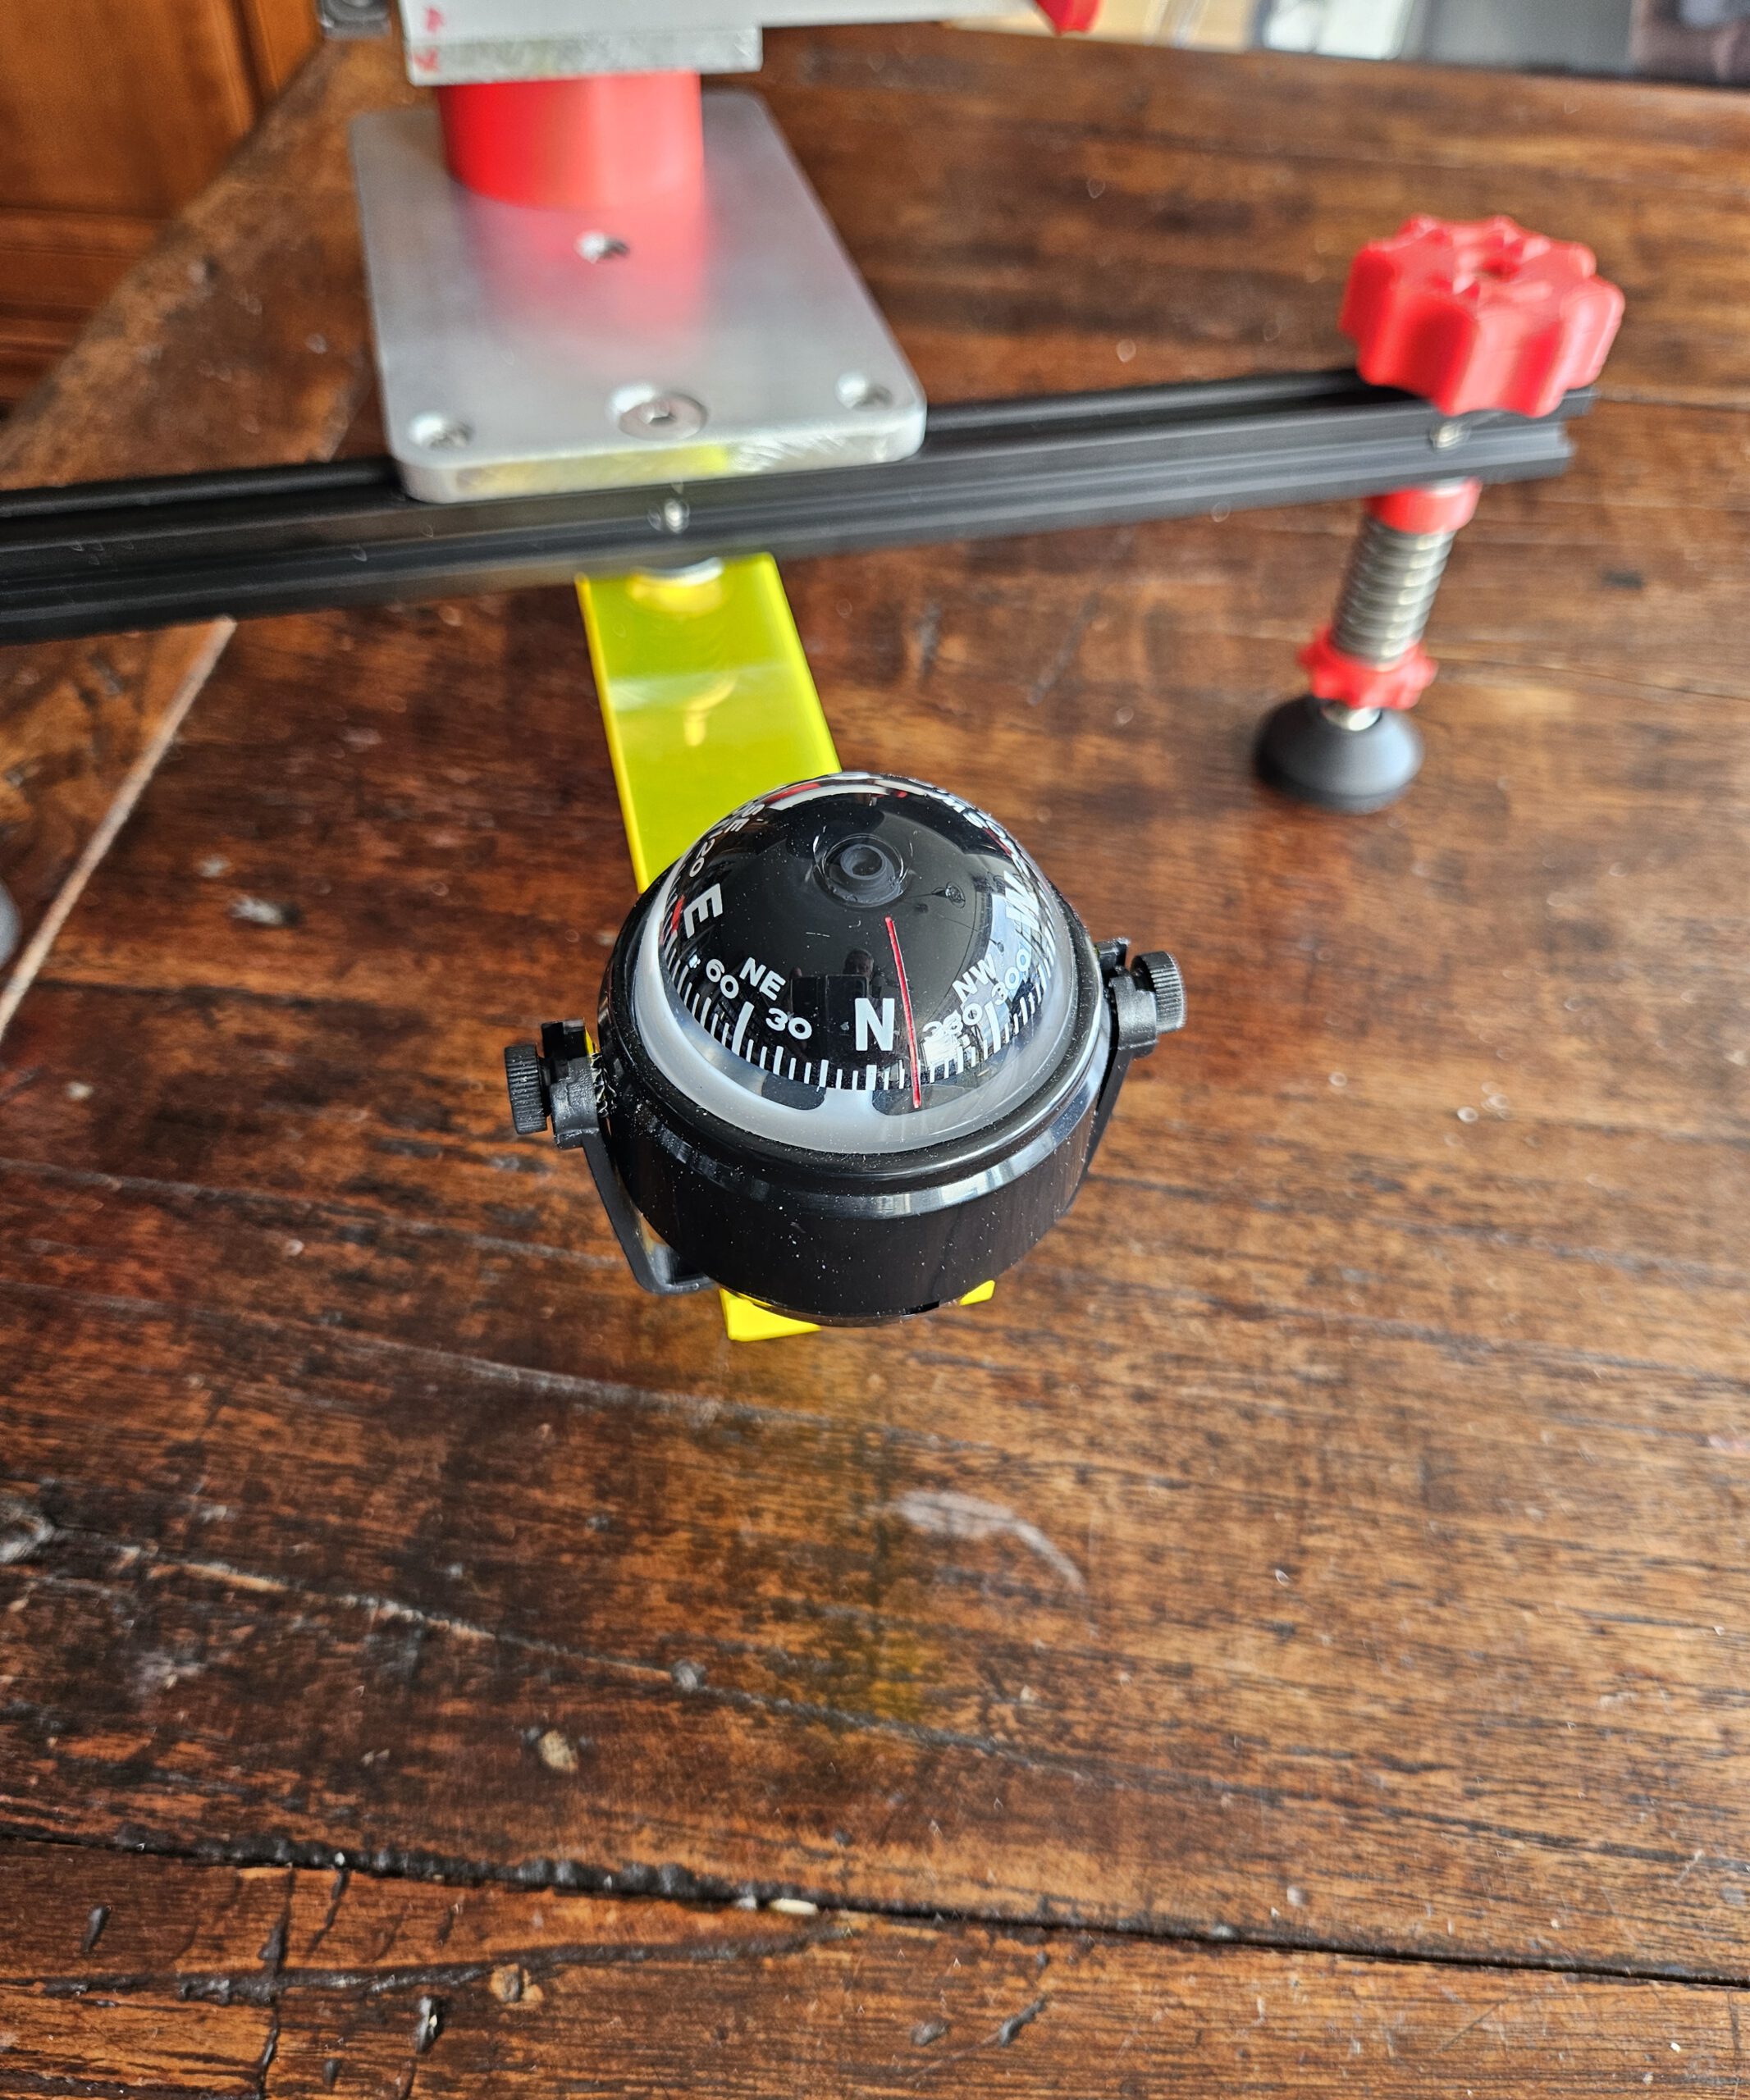
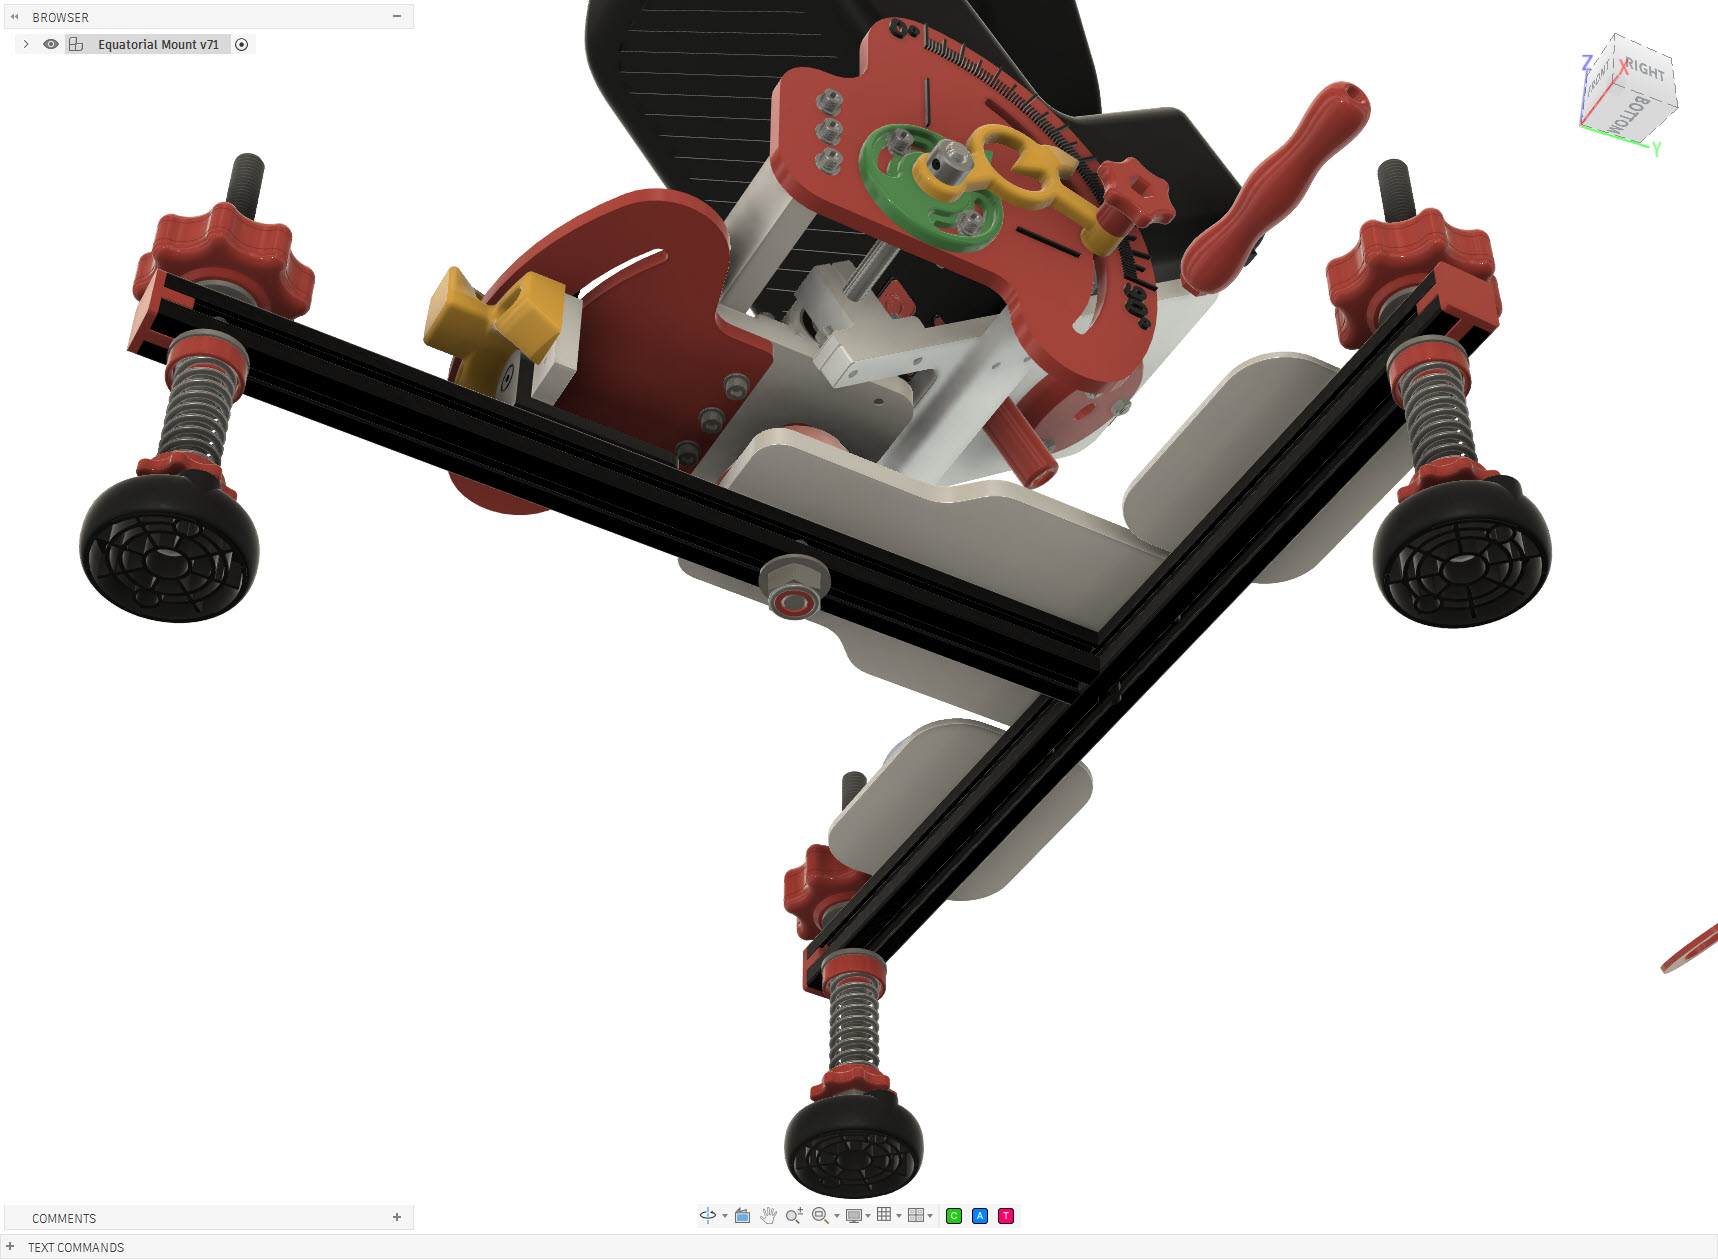
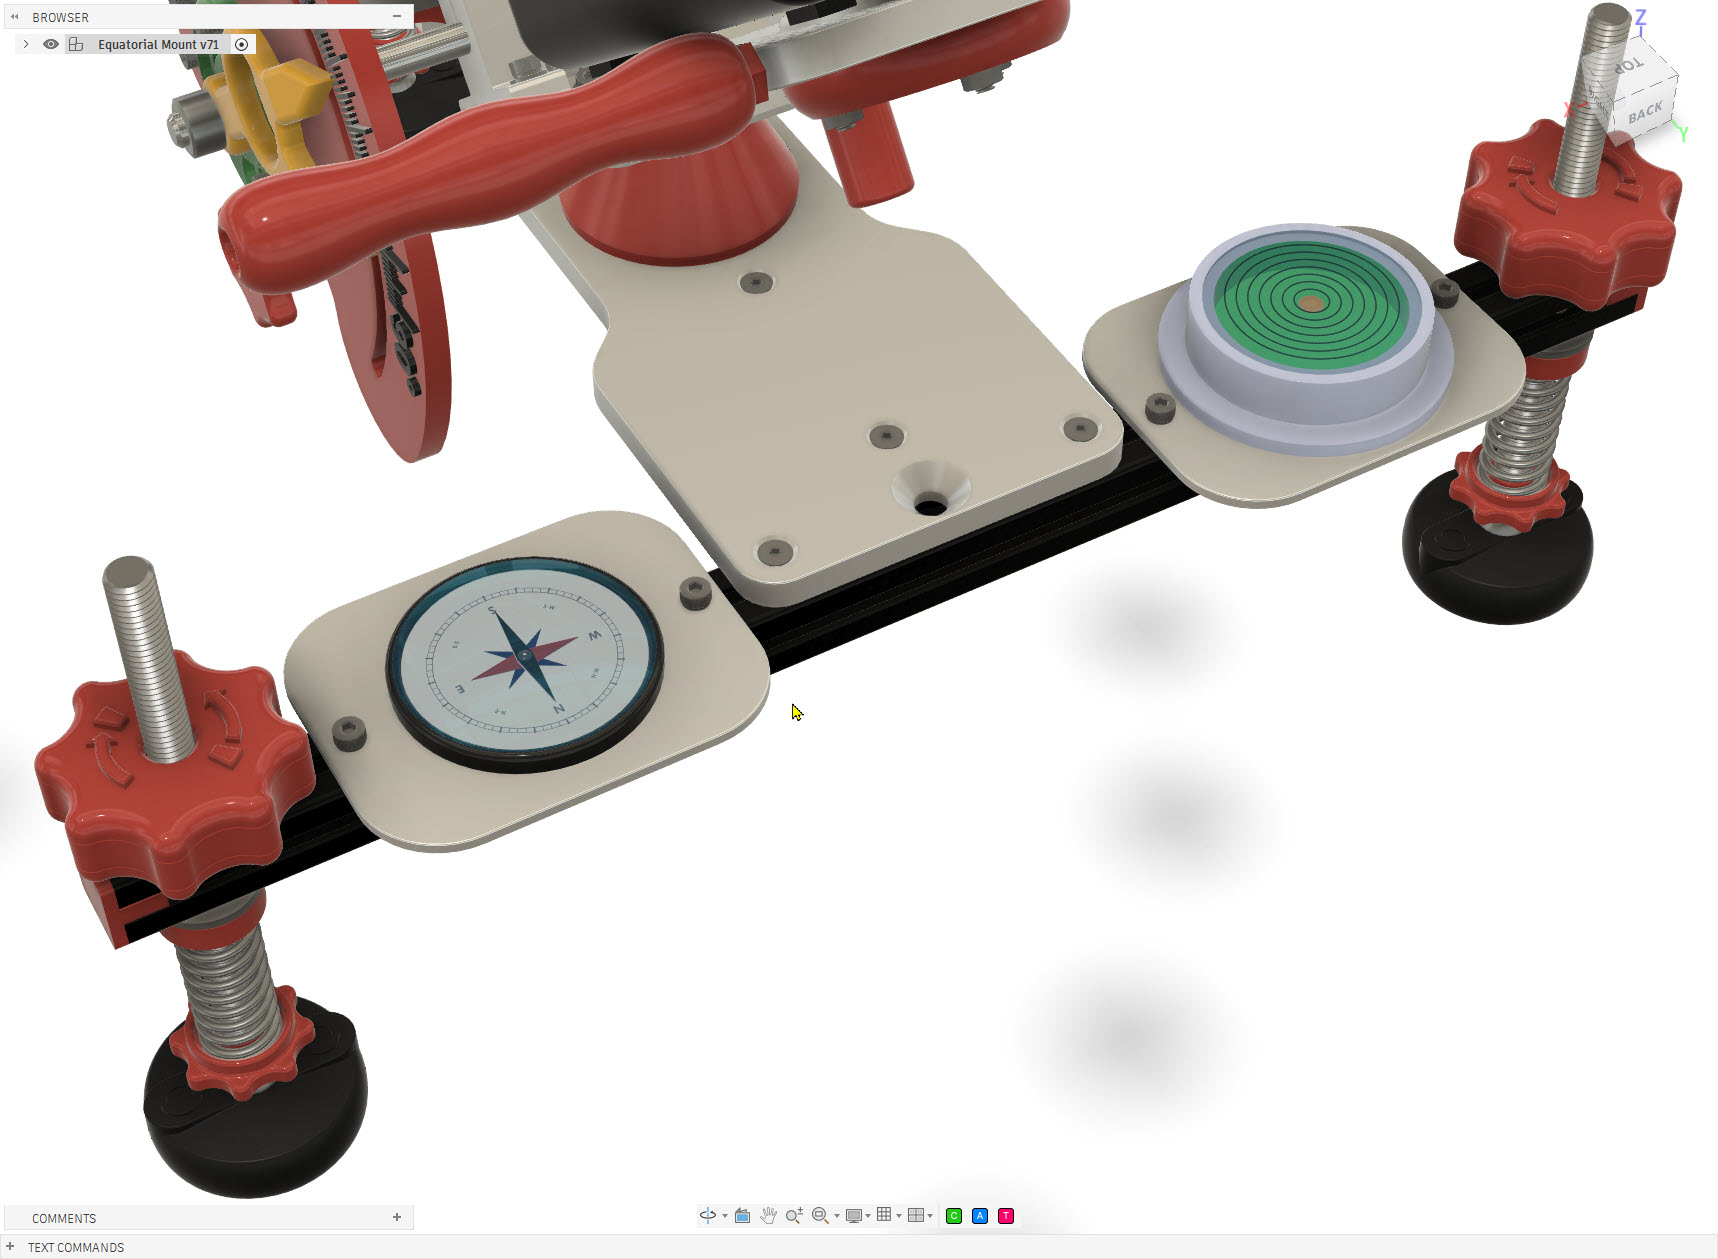
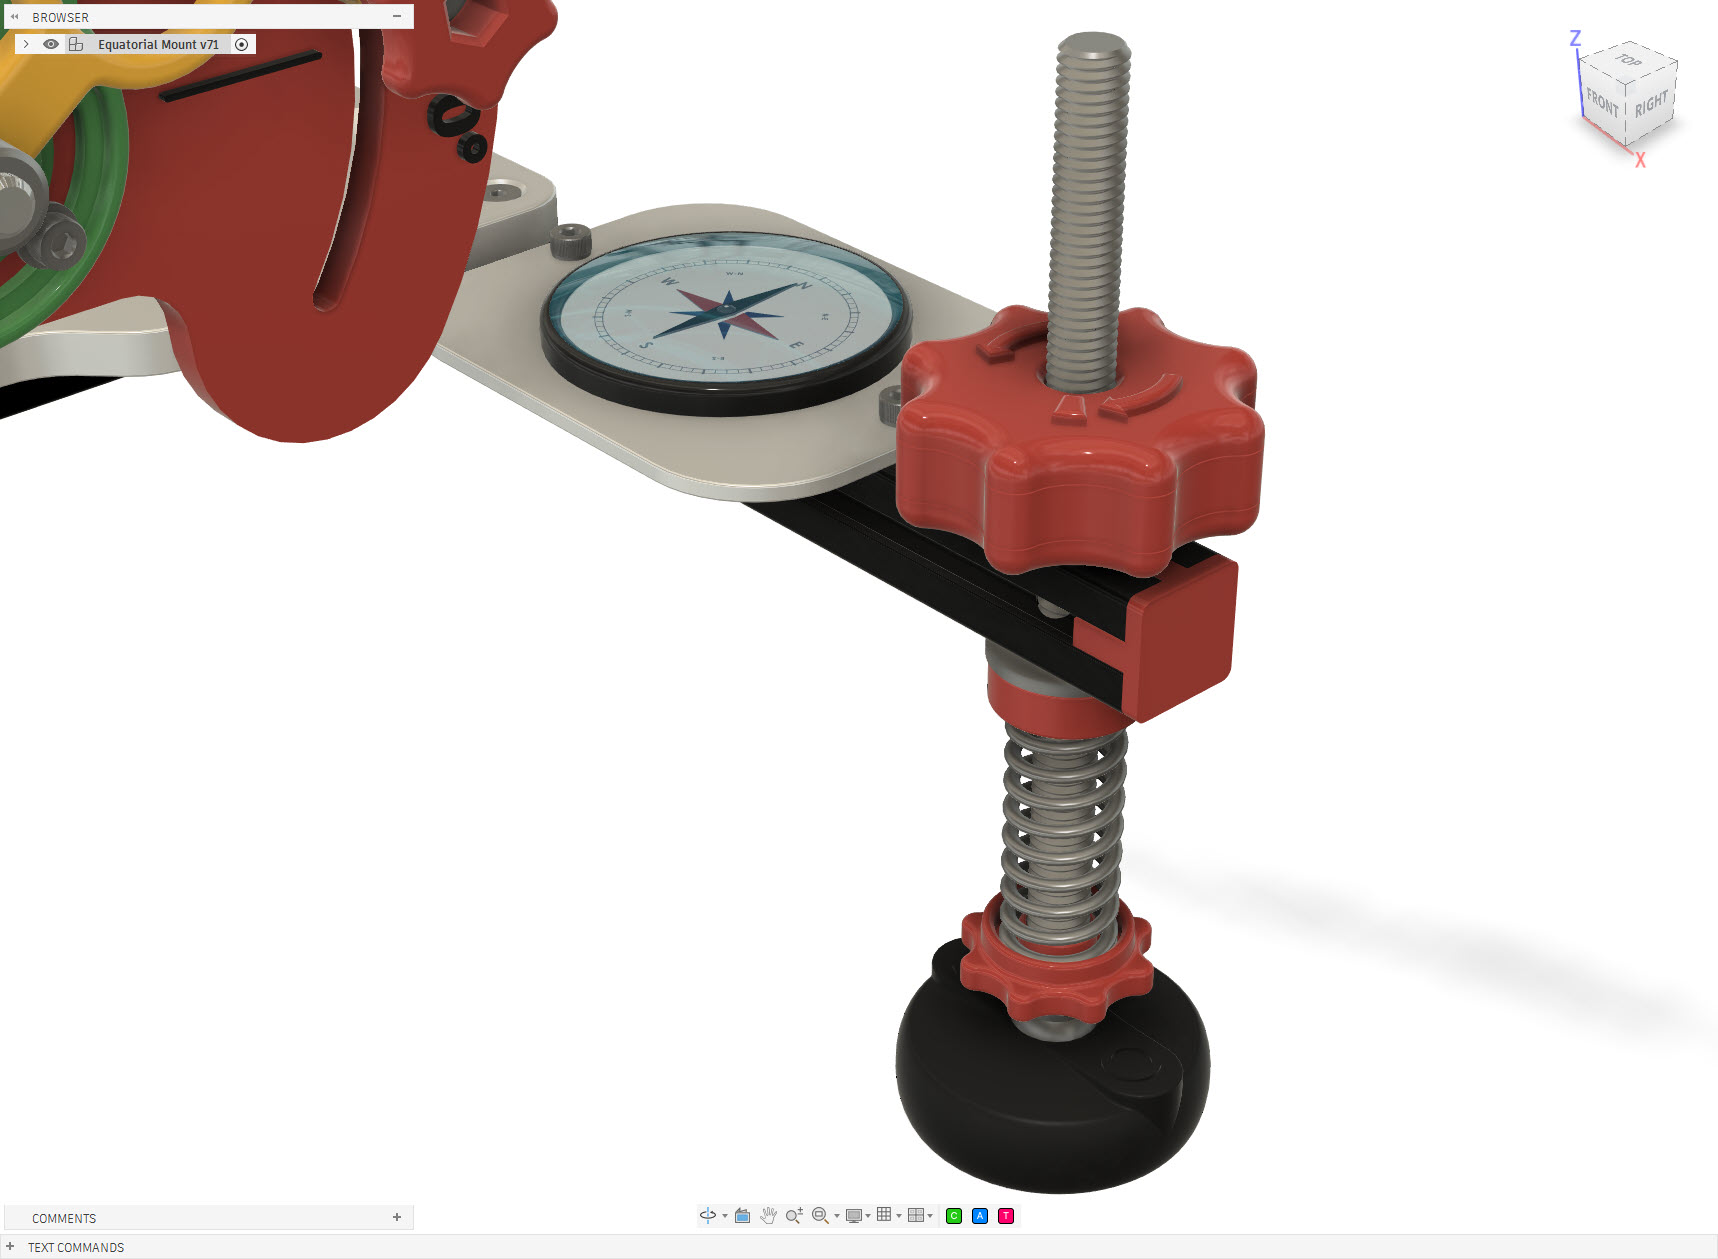
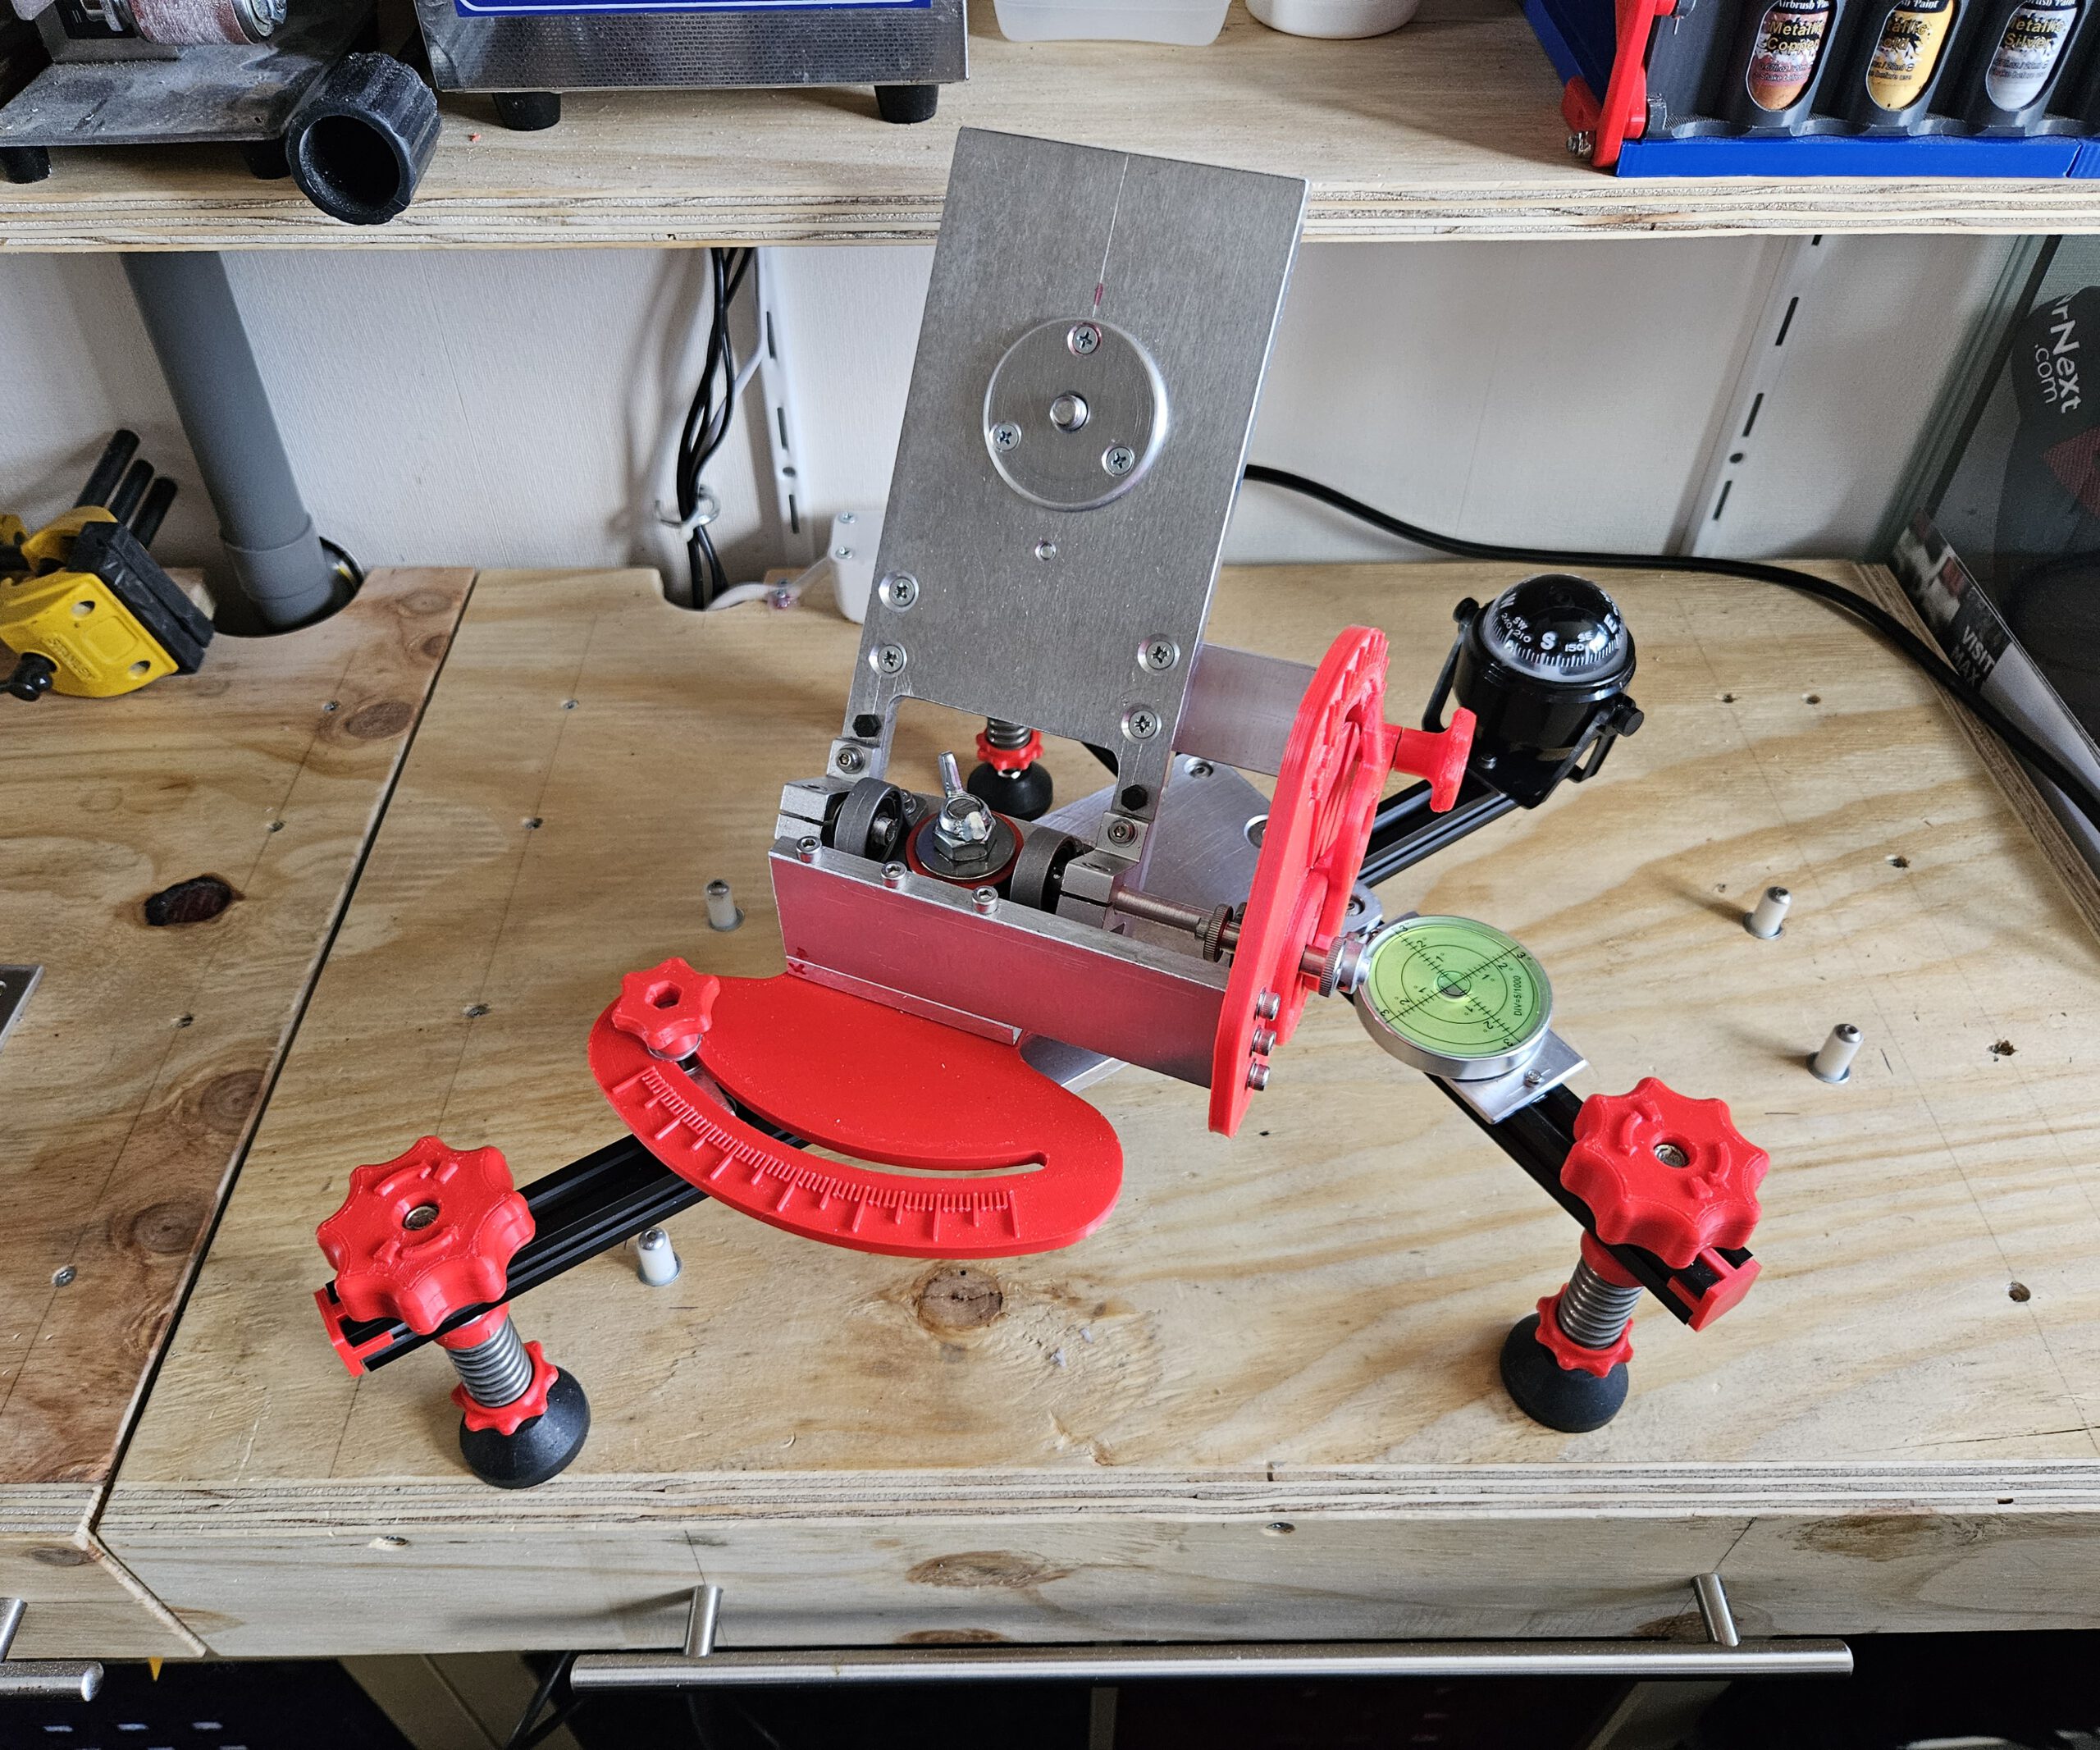
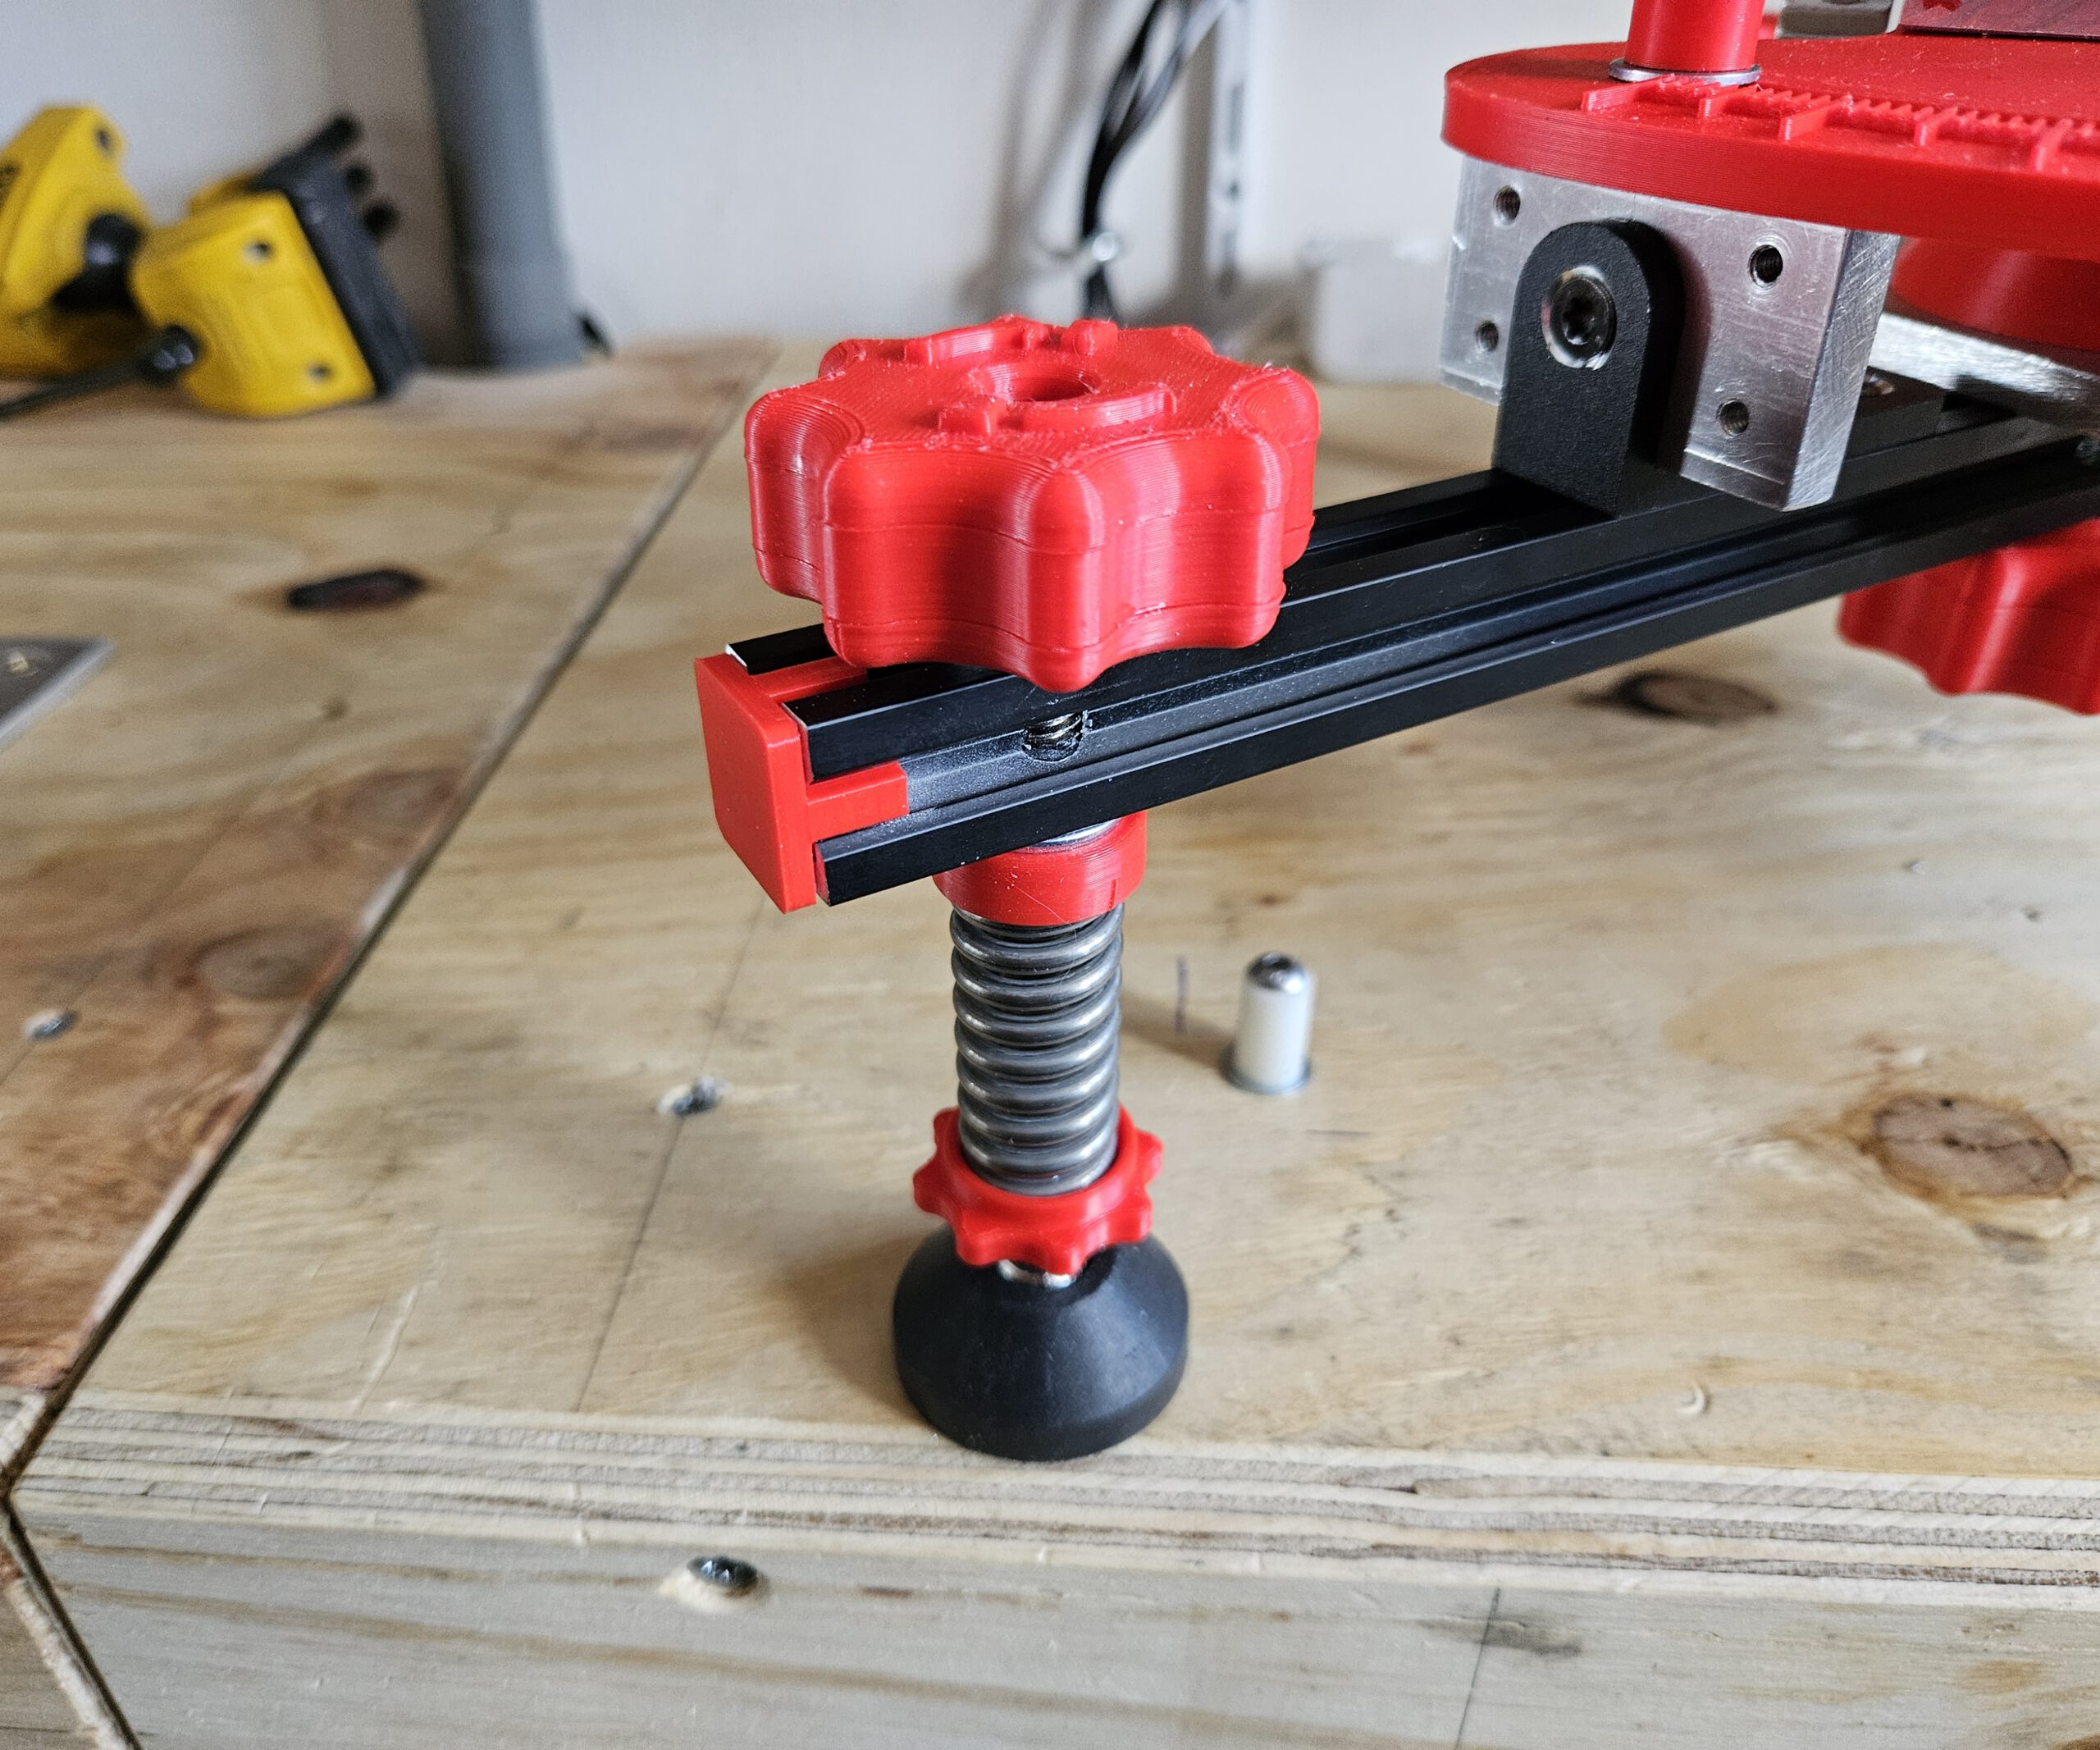
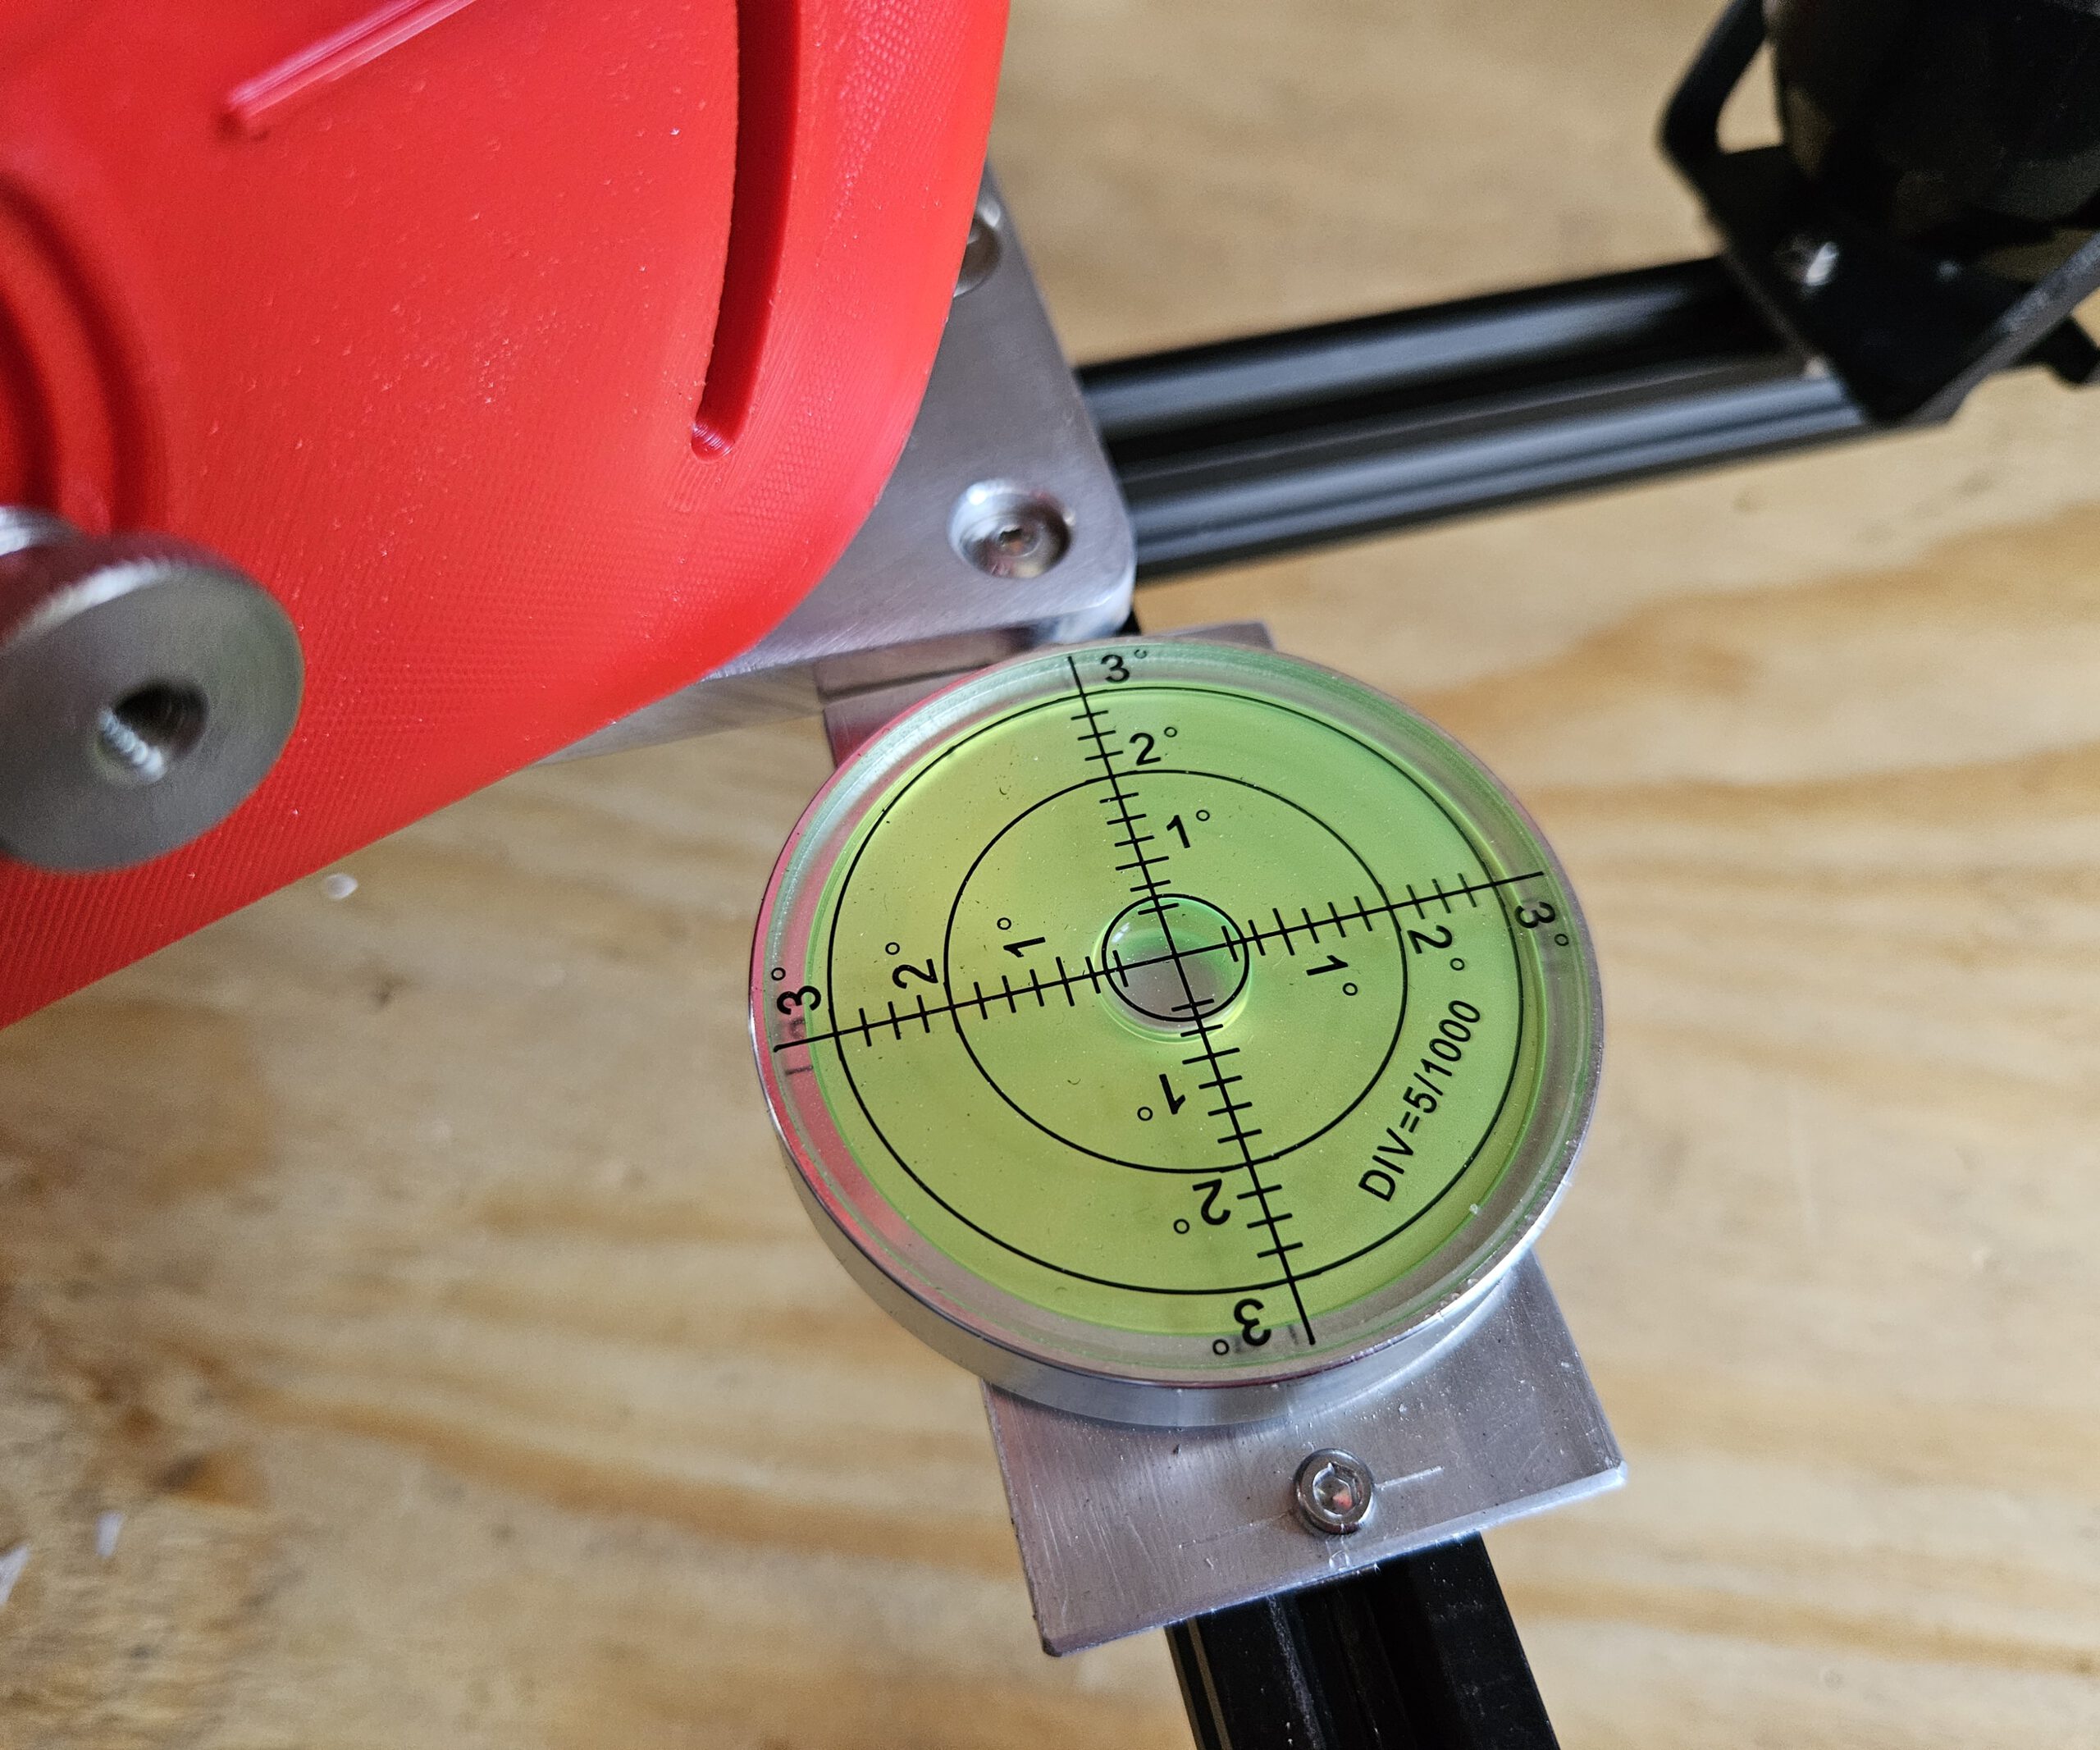
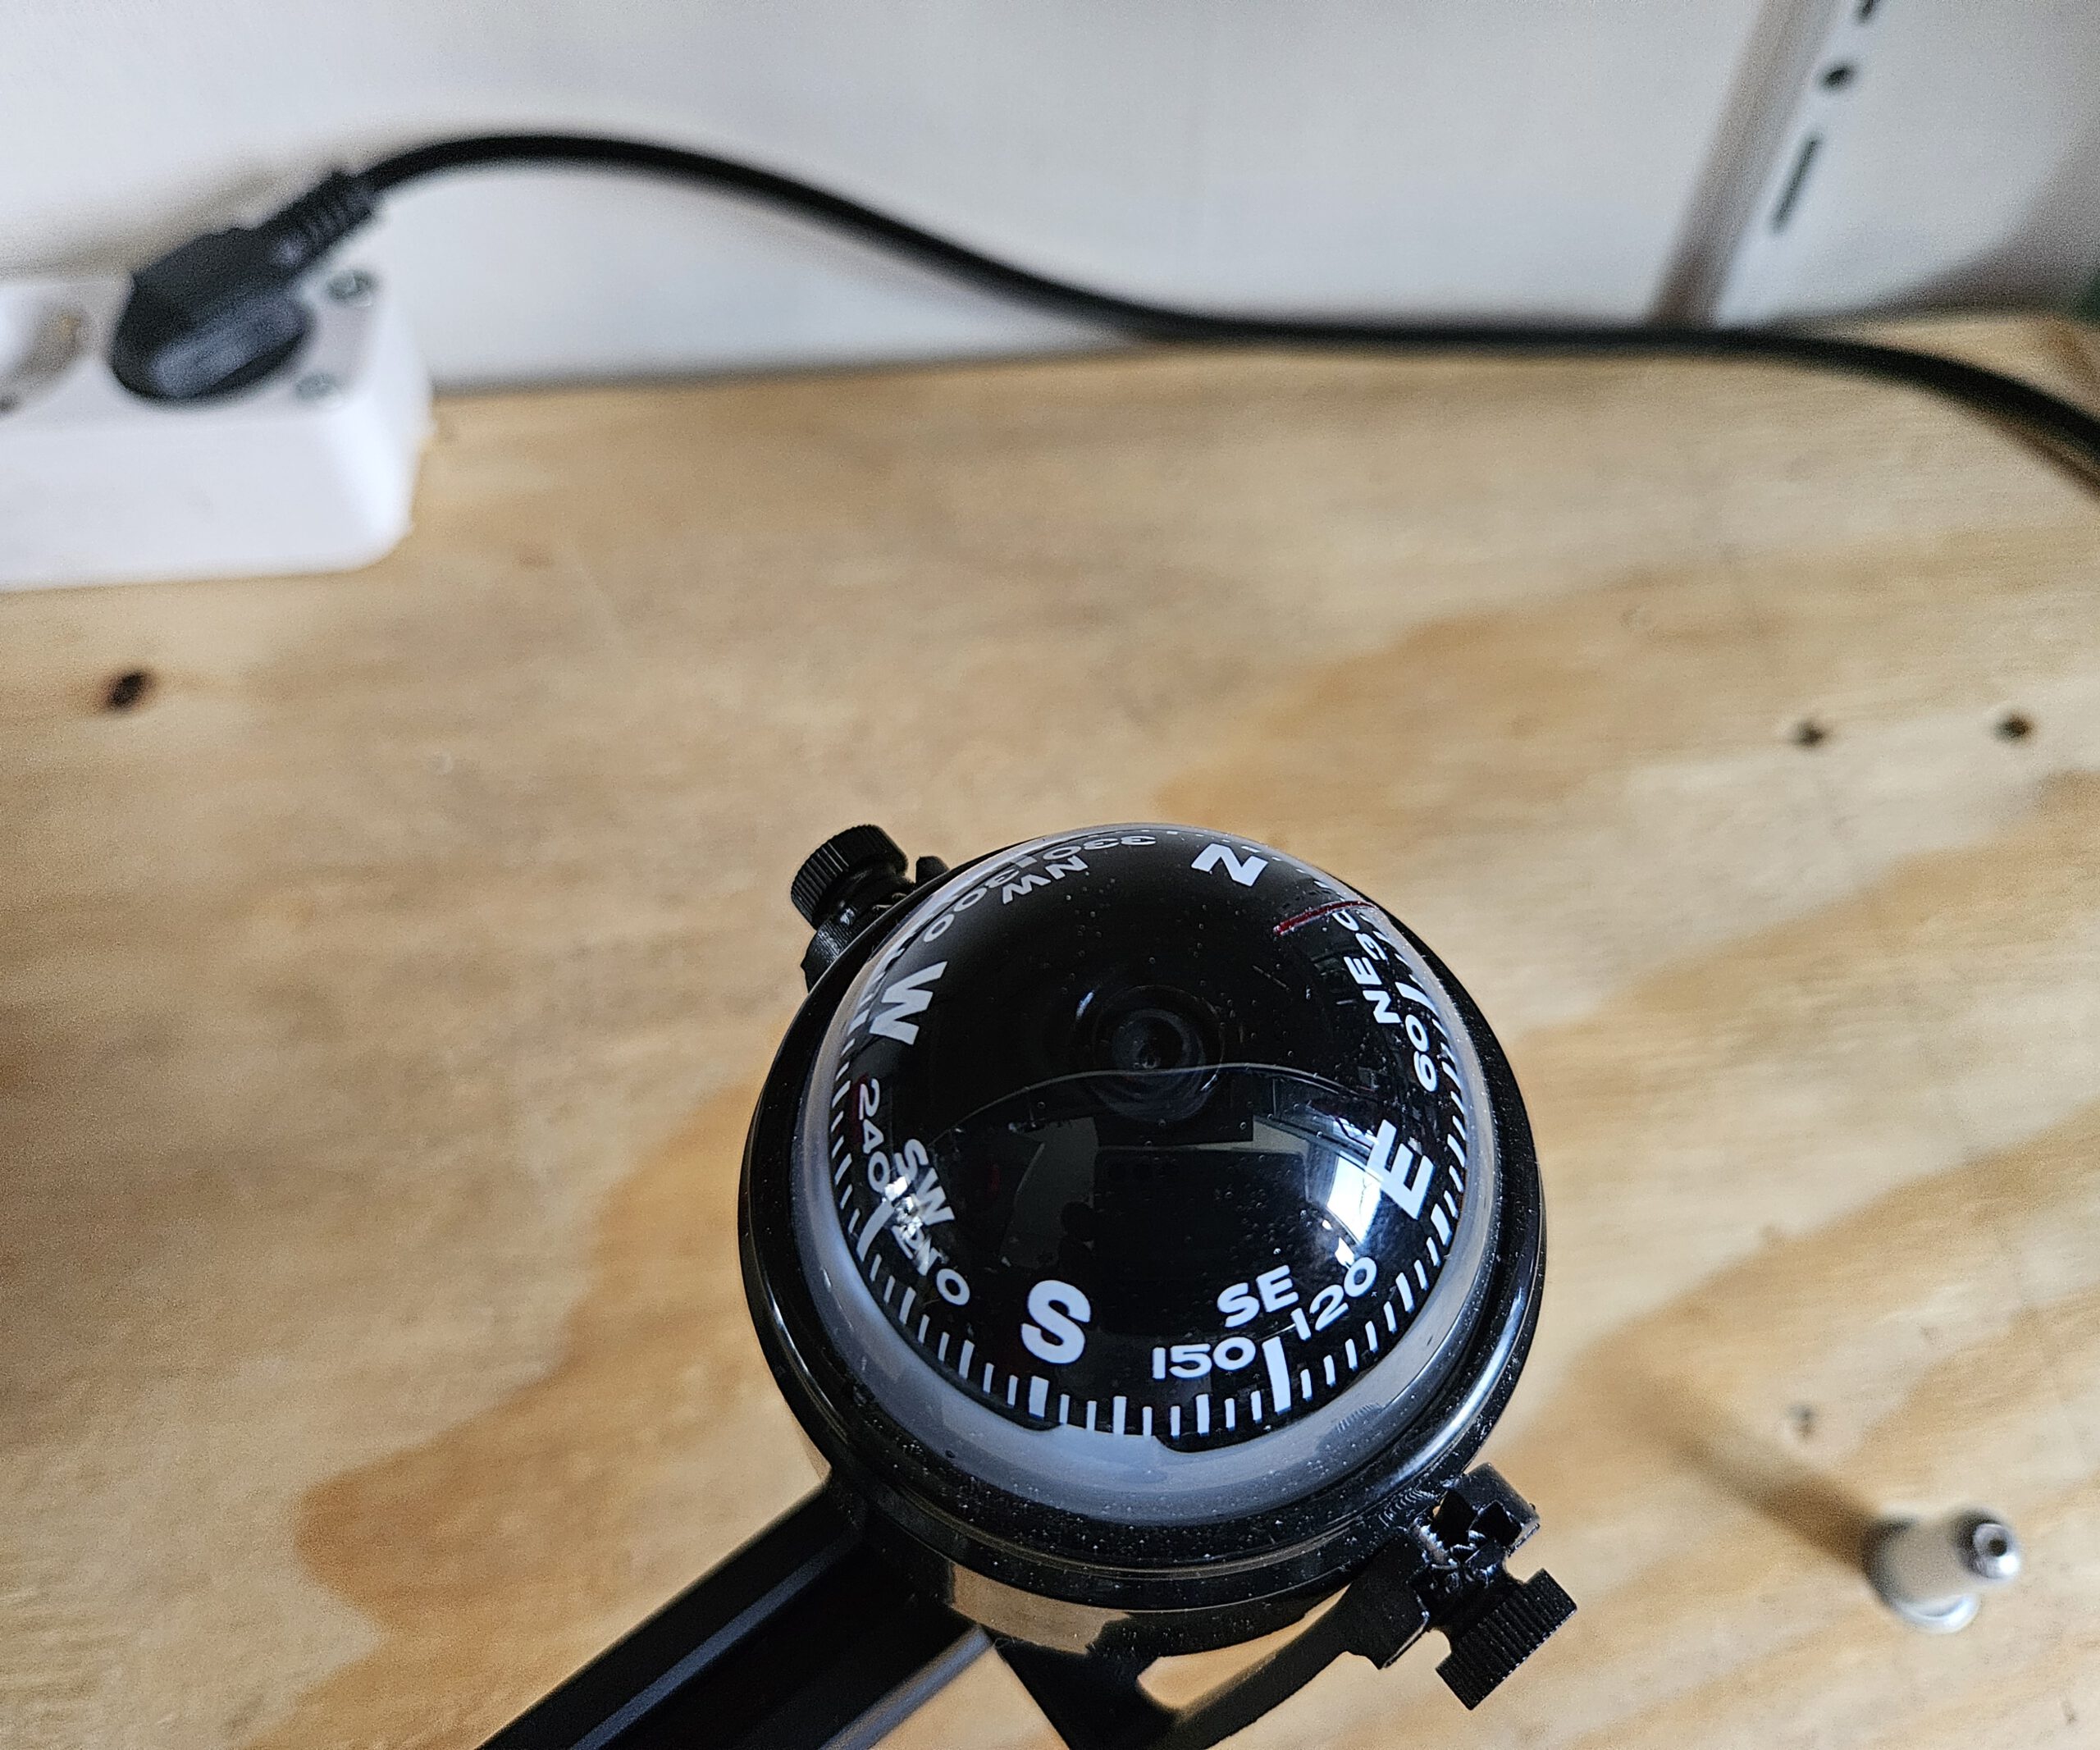
The three adjustable feet are used to level the mount first. A built-in compass and spirit level help with the initial setup, after which the altitude and azimuth controls provide the finer alignment.
Once aligned, the Seestar’s own rotation mechanism can follow the apparent movement of the sky around this axis.
Click the image for a larger version
WHY POLARIS? Polaris is almost directly above Earth’s rotational axis, making it a convenient alignment point.
WHY 51.2°? Polaris appears above the horizon at an angle equal to your latitude.
WHY TILT THE TELESCOPE? Tilting the Seestar aligns its rotation axis with Earth’s rotation axis.
WHY DOES THIS HELP? Once aligned, one rotating axis can follow the sky as Earth turns.
En eventueel bij het rijtje sterren bovenaan, omdat dát volgens mij voor een leek de grootste aha oplevert:
WHAT ARE WE SEEING? The stars only appear to circle Polaris — it is actually Earth that is rotating.
Pictures of the design
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
Seestar S50 Equatorial Mount
1/1
Design drawings for the Aluminium parts
The scales can be printed, but please use ABS or Nylon for stability. The other parts:
Azimuth Platform
Equatorial Mount
Rotaton Plate
Must be made from metal for stability. I used easy to work thick Aluminium plates. Back then I worked it by hand and hand tools. Nowadays I woult put it in mij CNC milling machine. But some old fashion workmanship will do too.
Quantities shown are for one tripod leg. Three identical legs are required for the complete mount.
Base Platform BOM
Qty
Component
Specification / Notes
3D printed
1
Aluminium Plate
220 × 100 × 8 mm
n/a
1
Washer
M10
n/a
1
Locknut
M10
n/a
5
Flat Head Hex Bolt
M4 × 30
n/a
1
Socket Head Bolt
M10 × 120
n/a
1
APS Lock
n/a
ABS/Nylon
1
Top Azimuth Support
n/a
ABS/Nylon
1
Bottom Azimuth Support
n/a
XABS/Nylon
Altitude Platform BOM
Qty
Component
Specification / Notes
3D printed
1
Aluminium Plate
205.2 × 100 × 8 mm
n/a
1
Lens Head Bolt
3/8″-16 × 3/4″
n/a
1
External-Tooth Lock Washer
3/4″
n/a
2
Flat Head Hex Bolt
M4 × 30
n/a
4
Flat Head Hex Bolt
M4 × 14
n/a
1
Hex Bolt
M4 × 15
n/a
1
Hex Bolt
M4 × 40
n/a
1
Socket Head Bolt
M4 × 30
n/a
4
Socket Head Bolt
M4 × 13
n/a
3
Hex Nut
M4
n/a
15
Washer
M4
n/a
1
Steel Axle
Ø8 mm × 100 mm
n/a
1
Steel Axle
Ø8 mm × 30 mm
n/a
1
Shaft Collar
ID 8 mm, OD 14 mm, H 8 mm
n/a
1
Cup Point Hex Set Screw
M4 × 3
n/a
2
SK8 Axle Support
42 × 32 × 14 mm, ID 8 mm
n/a
1
Adjustable Handle Block Alt
n/a
ABS/Nylon
1
Alt Grip
n/a
ABS/Nylon
1
Aluminium Turning Base
n/a
ABS/Nylon
1
Alt Platform 0 Degree Support
n/a
ABS/Nylon
1
Scale Pointer
n/a
Any
1
Thumb Screw
n/a
Any
1
Placeholder for Lens Head Bolt
n/a
Any
Azimuth Platform BOM
Qty
Component
Specification / Notes
3D printed
4
Flat Head Bolt
M4 × 20
n/a
3
Roll Bearing Block
42 × 32 × 14 mm, ID 8 mm
n/a
8
Socket Head Bolt
M4 × 13
n/a
8
Washer
M4
n/a
2
Socket Head Bolt
M4 × 13, additional hardware
n/a
2
Nut
M3
n/a
2
SKF 51203 Thrust Bearing
51203 / S1203 XC
n/a
1
Azimuth Scale & Lock
n/a
ABS/Nylon
1
Altitude Lock Plate V5
n/a
ABS Nylon
1
Lockable Home Altitude Pointer
n/a
Any
1
Adjustable Handle Block Azi
n/a
ABS/Nylon
And then came the ultimate field test: a solar eclipse.
With the mount polar-aligned and the Seestar tracking the Sun, I could leave the telescope to follow the event instead of repeatedly repositioning it by hand. The result was a complete time-lapse of the eclipse — and, more importantly from a maker’s perspective, proof that the design actually worked outside Fusion 360.
Towards the end of the solar eclipse clip, the image starts to shift. This happened because the telescope eventually ran into the window frame without me noticing. A bit unfortunate, but it is what it is. Apart from that, the recording was successful and the mount did exactly what it was supposed to do.
Custom-built storage solutions for tools, wire and all the other stuff that somehow keeps multiplying.
1. Wire Spool Rack
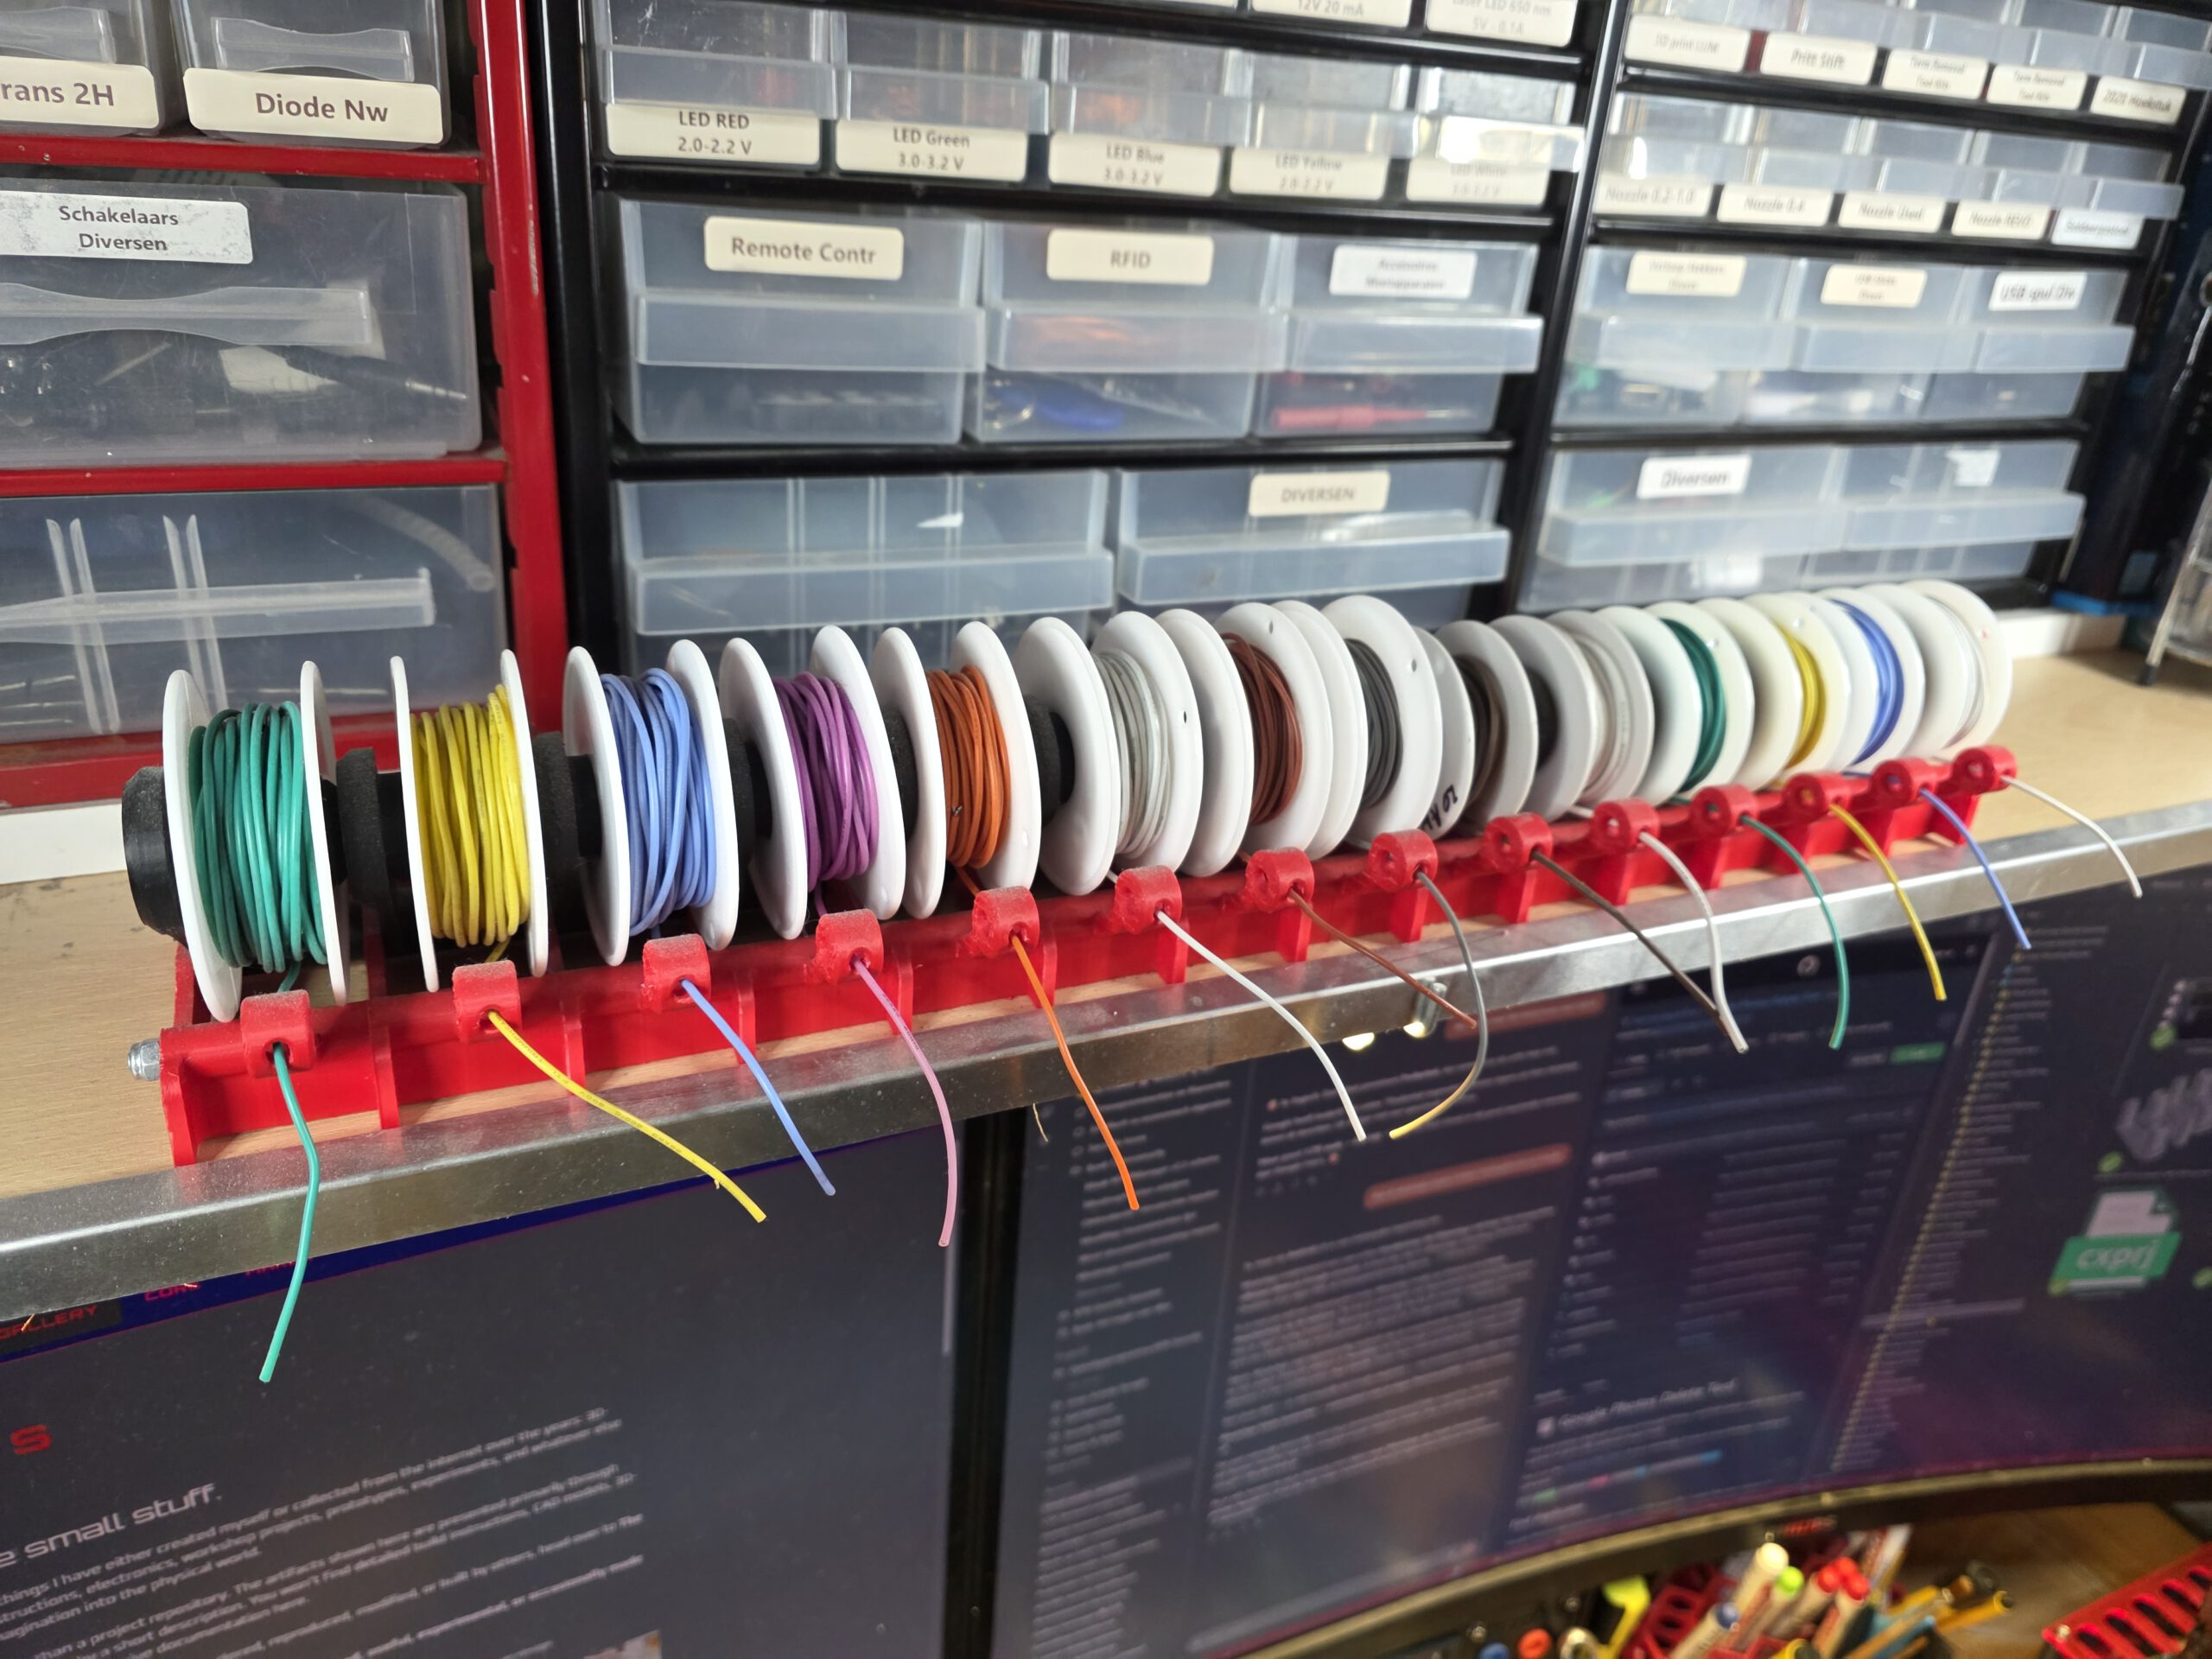
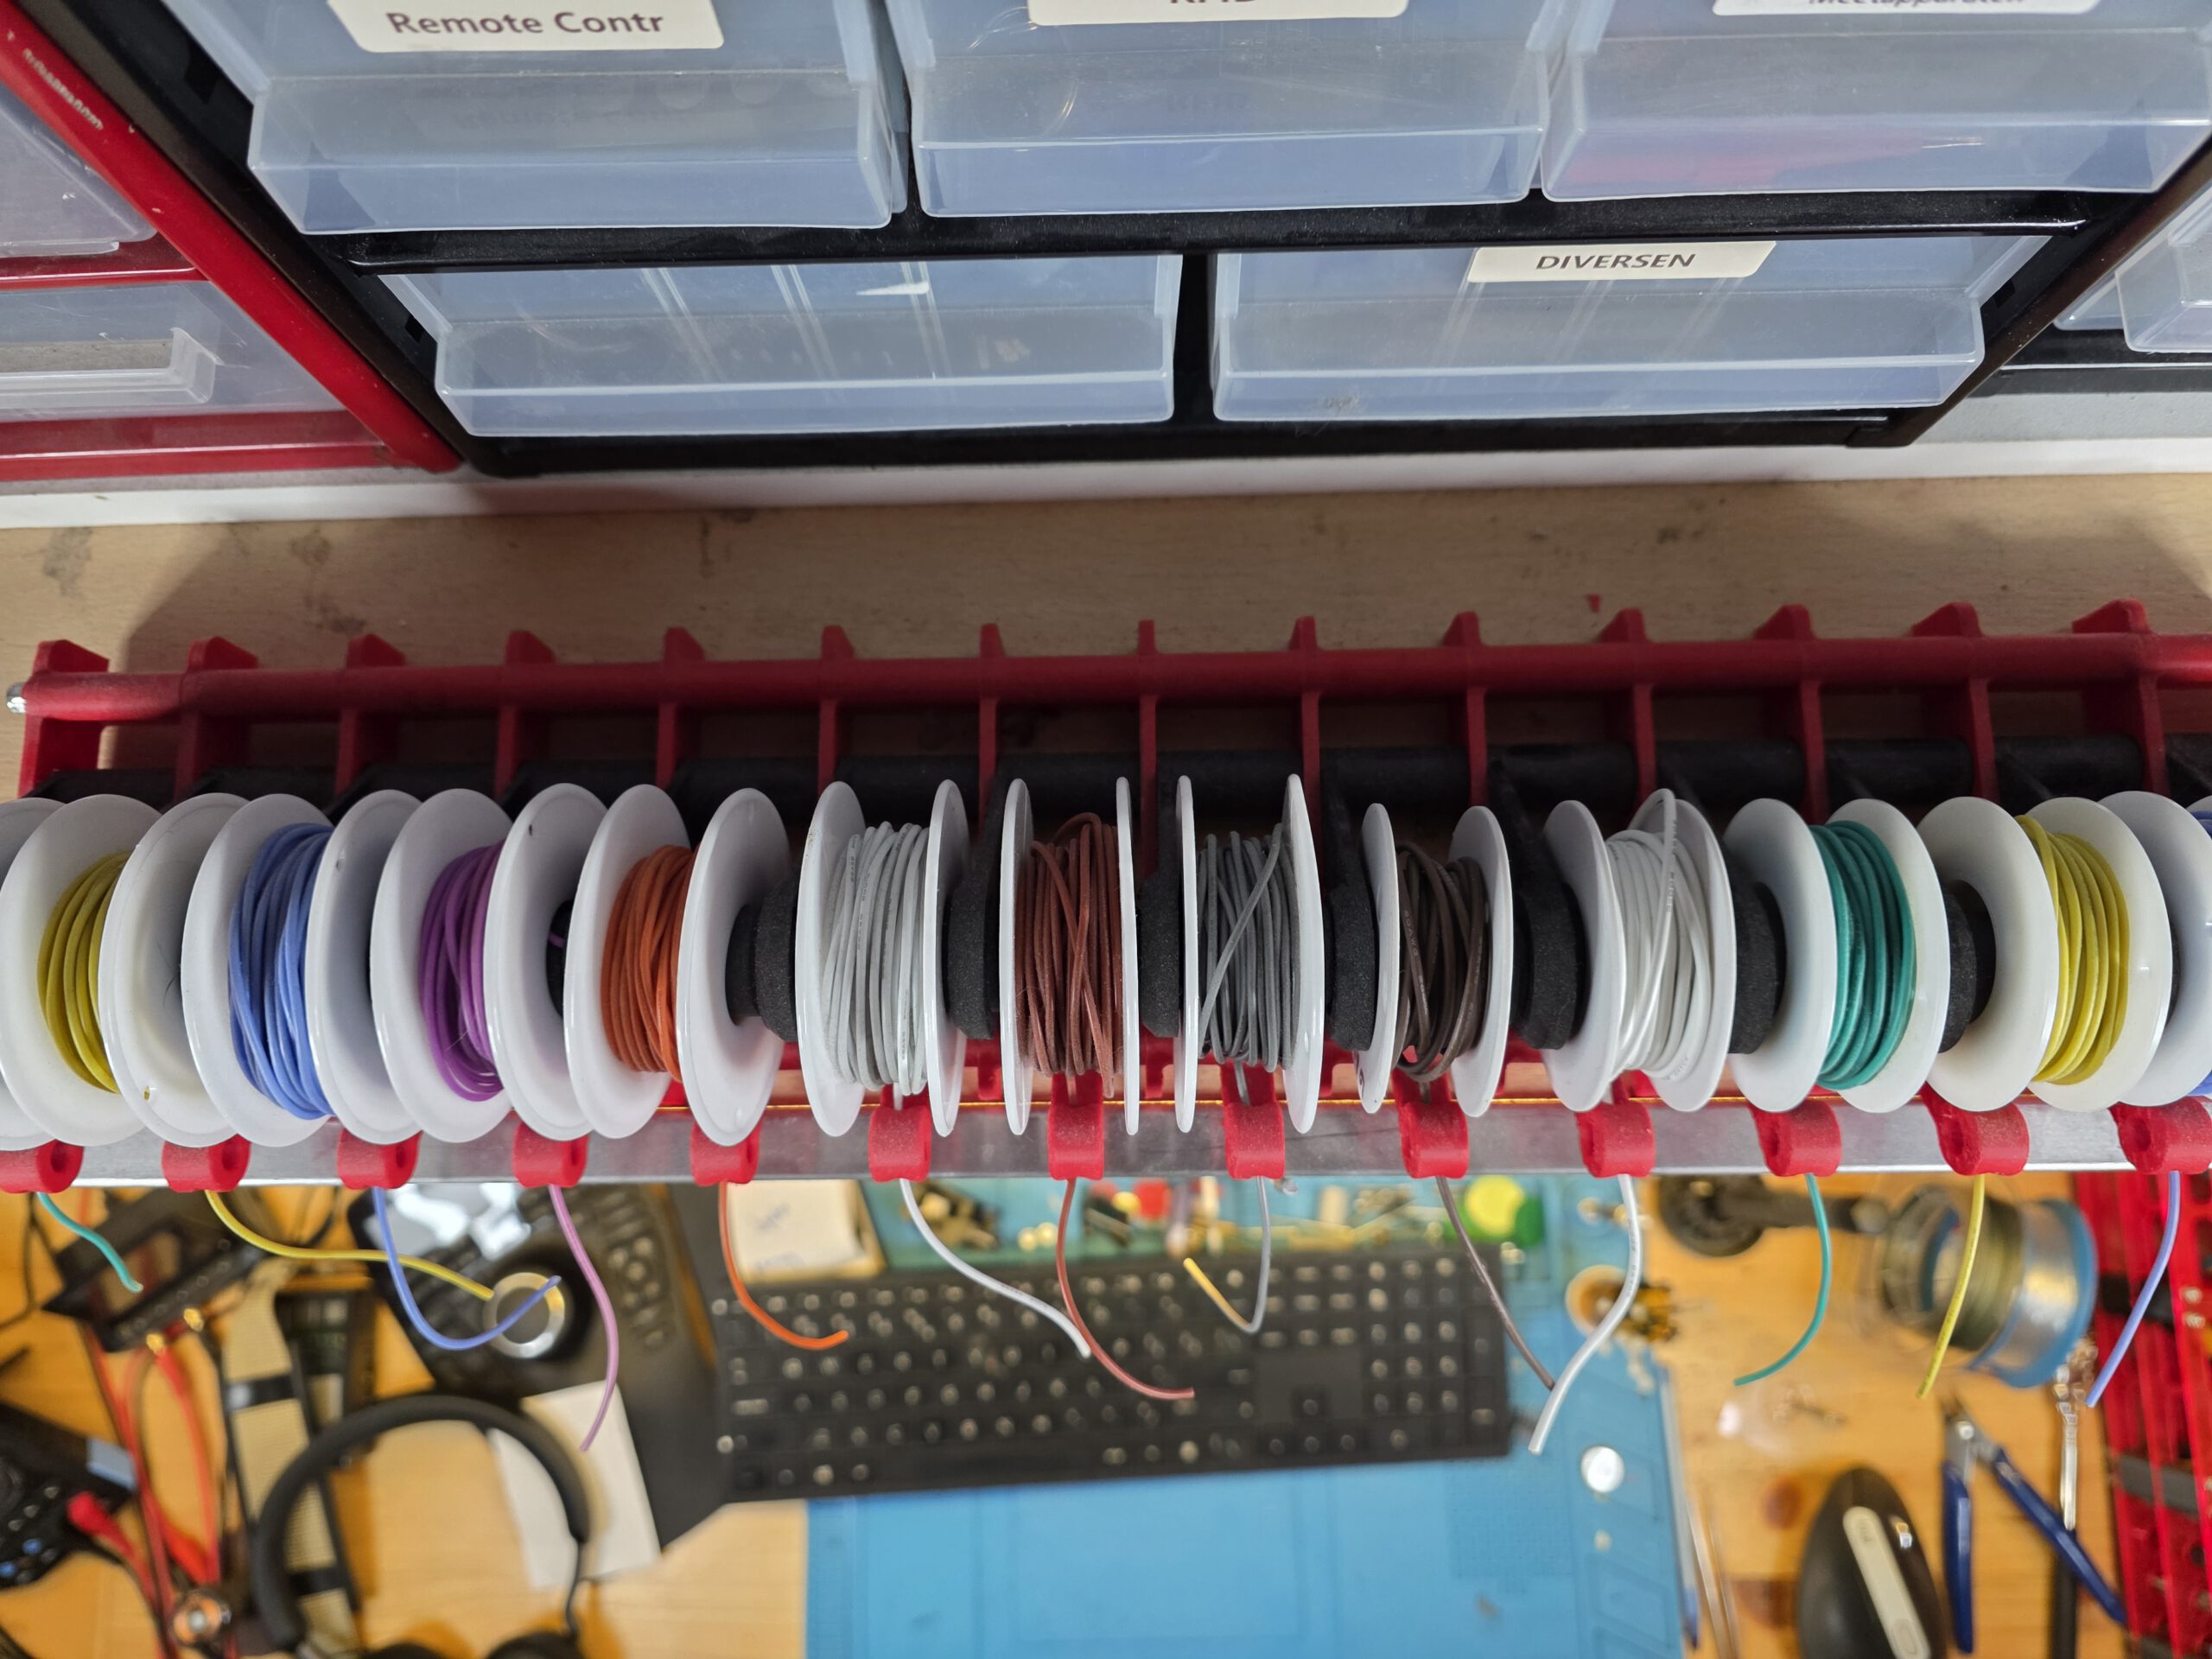
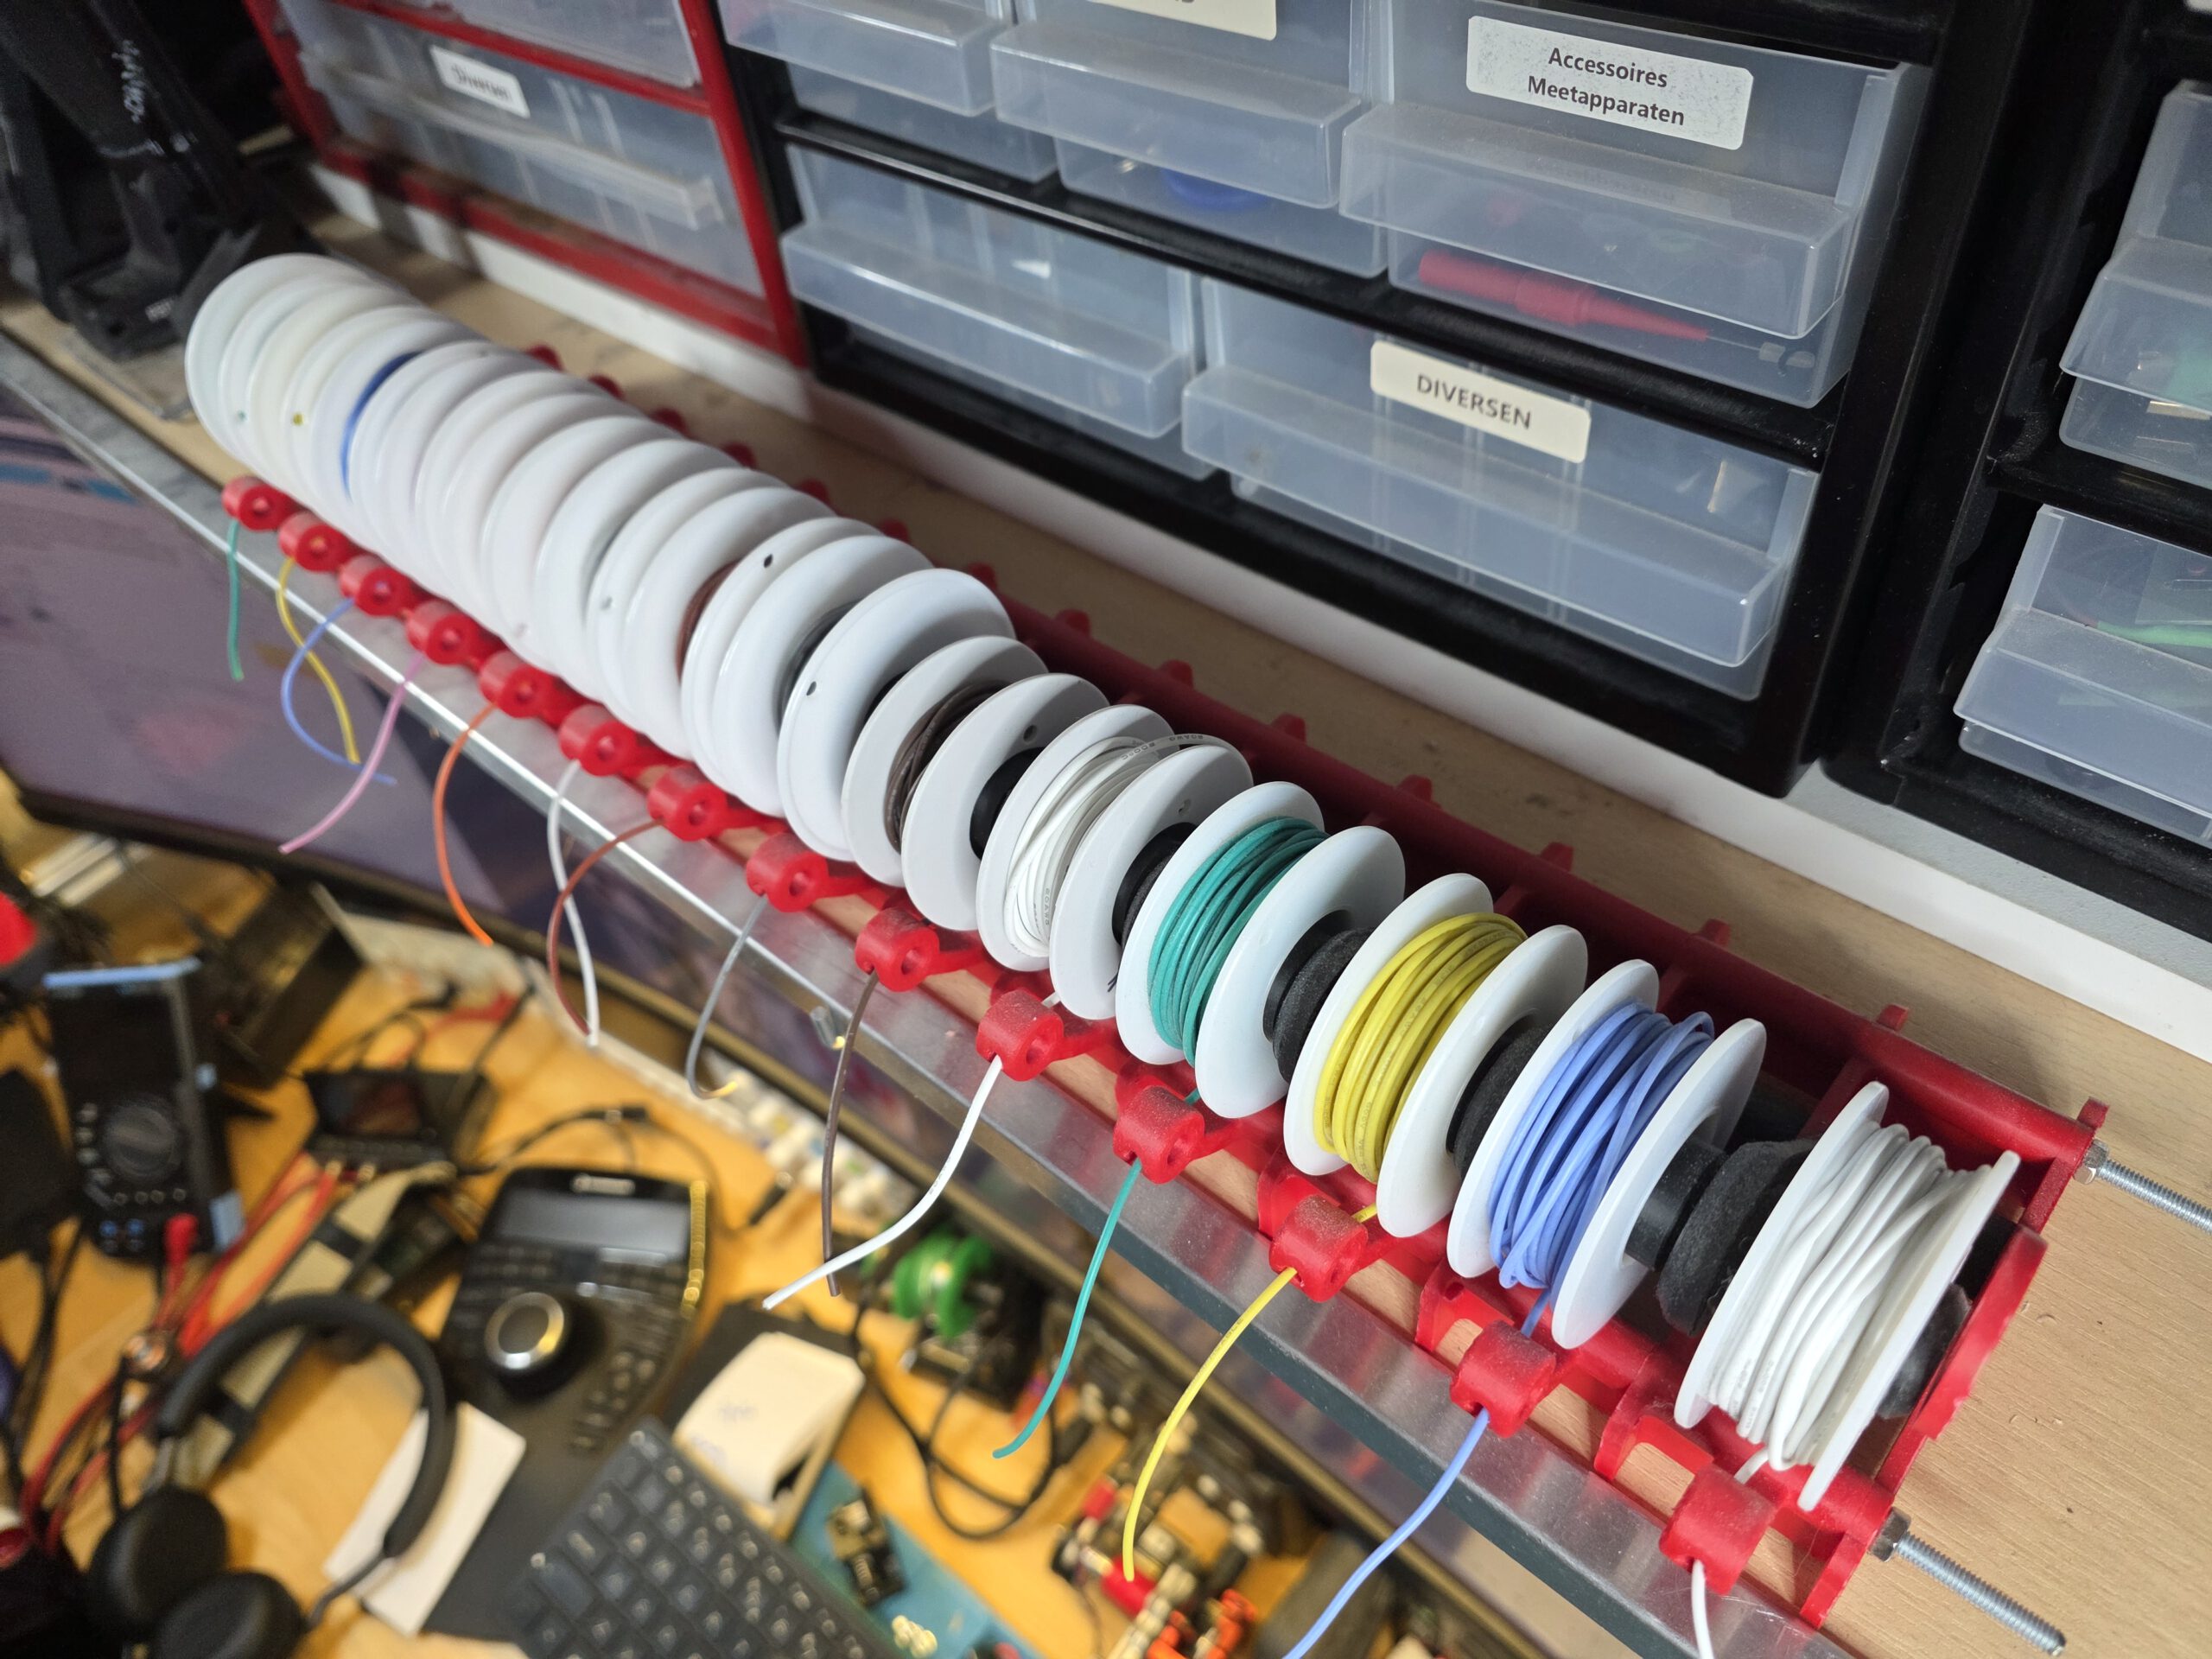
A custom-built, largely 3D-printed dispenser and organizer for small spools of hookup wire. The spools are mounted on a single horizontal axle, with an individual guide in front of each spool for feeding the wire through.
This keeps every wire end easy to find and allows the required length to be pulled directly from the spool. A simple idea, but exactly the kind of thing that prevents fifteen spools of wire from spontaneously deciding to become a single organism.
A large, multi-level tool rack designed to store a substantial number of hand tools vertically while keeping everything immediately accessible. It holds screwdrivers, pliers, tweezers, scissors, drill bits, files, calipers, measuring tools and many other workshop essentials.
The rack uses custom-designed plates, spacers and dedicated holders and openings for different types of tools. Rather than being an off-the-shelf organizer, it was designed specifically to maximize storage capacity within a very limited amount of workshop space.
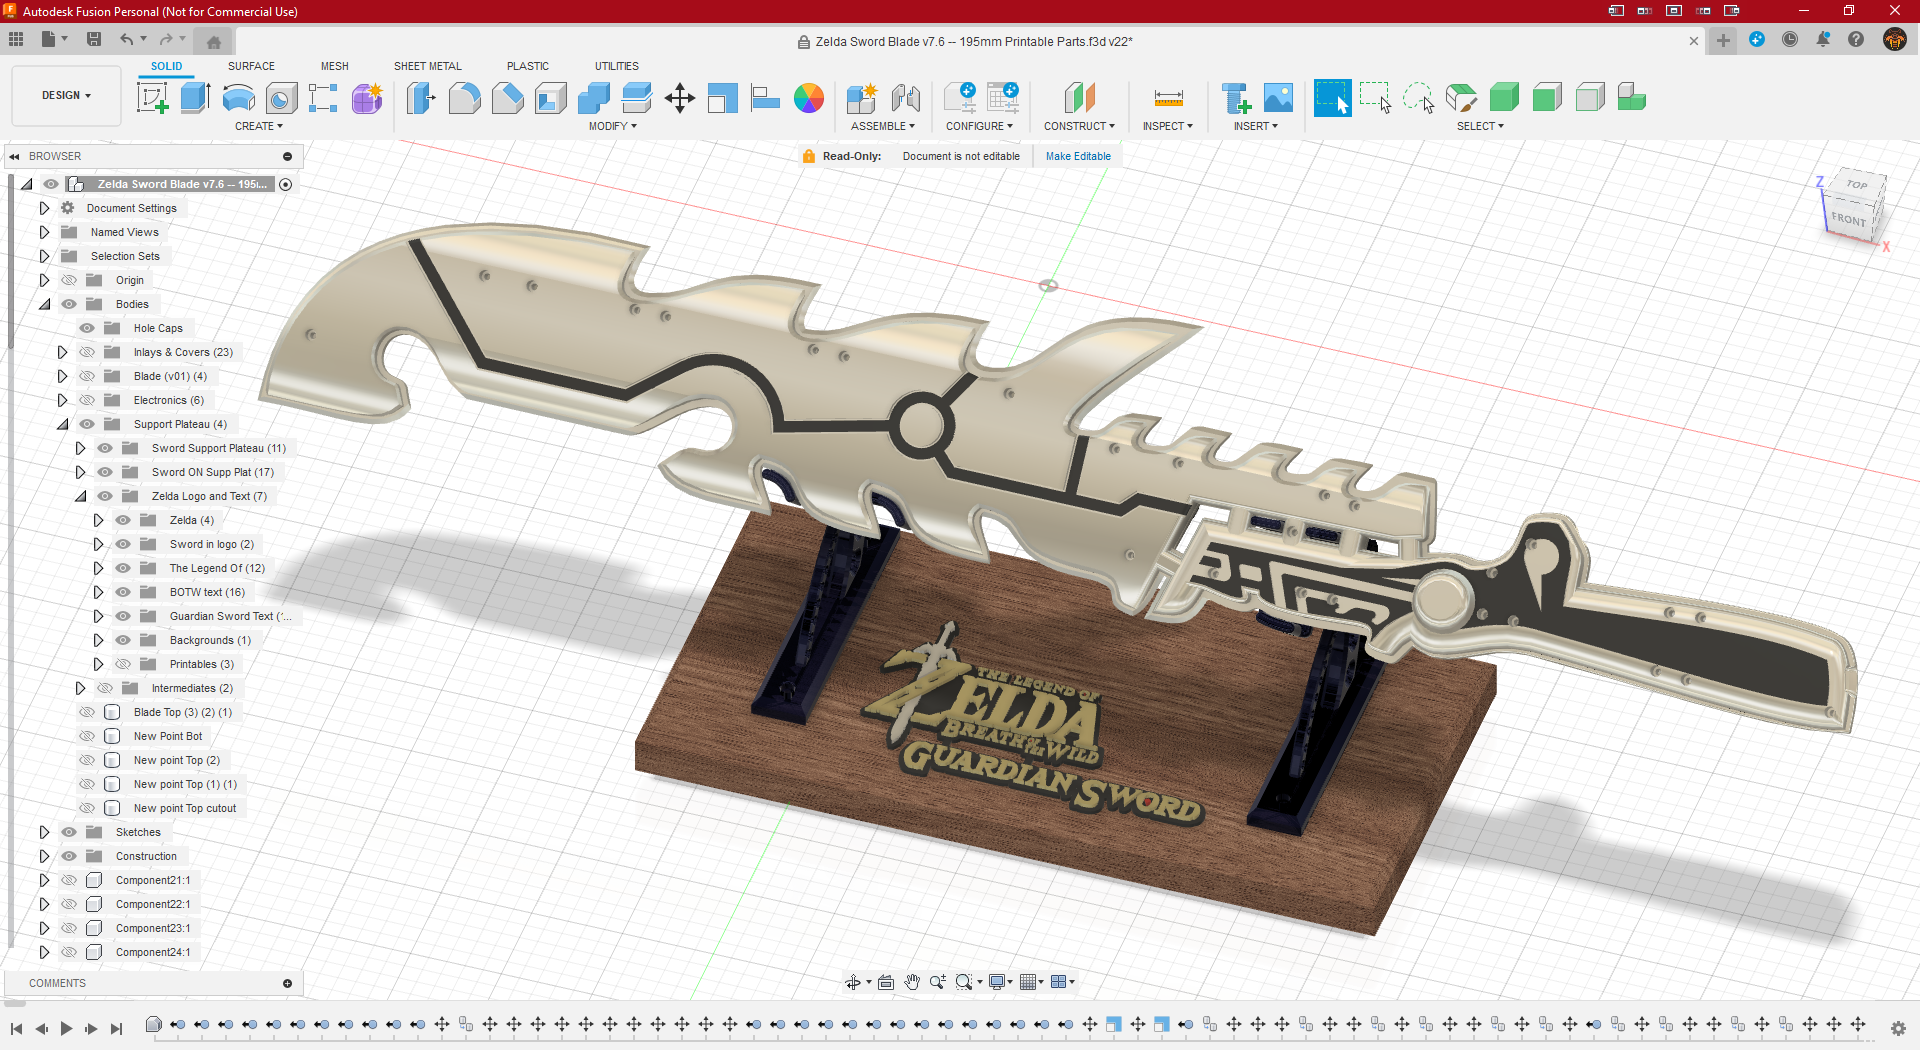
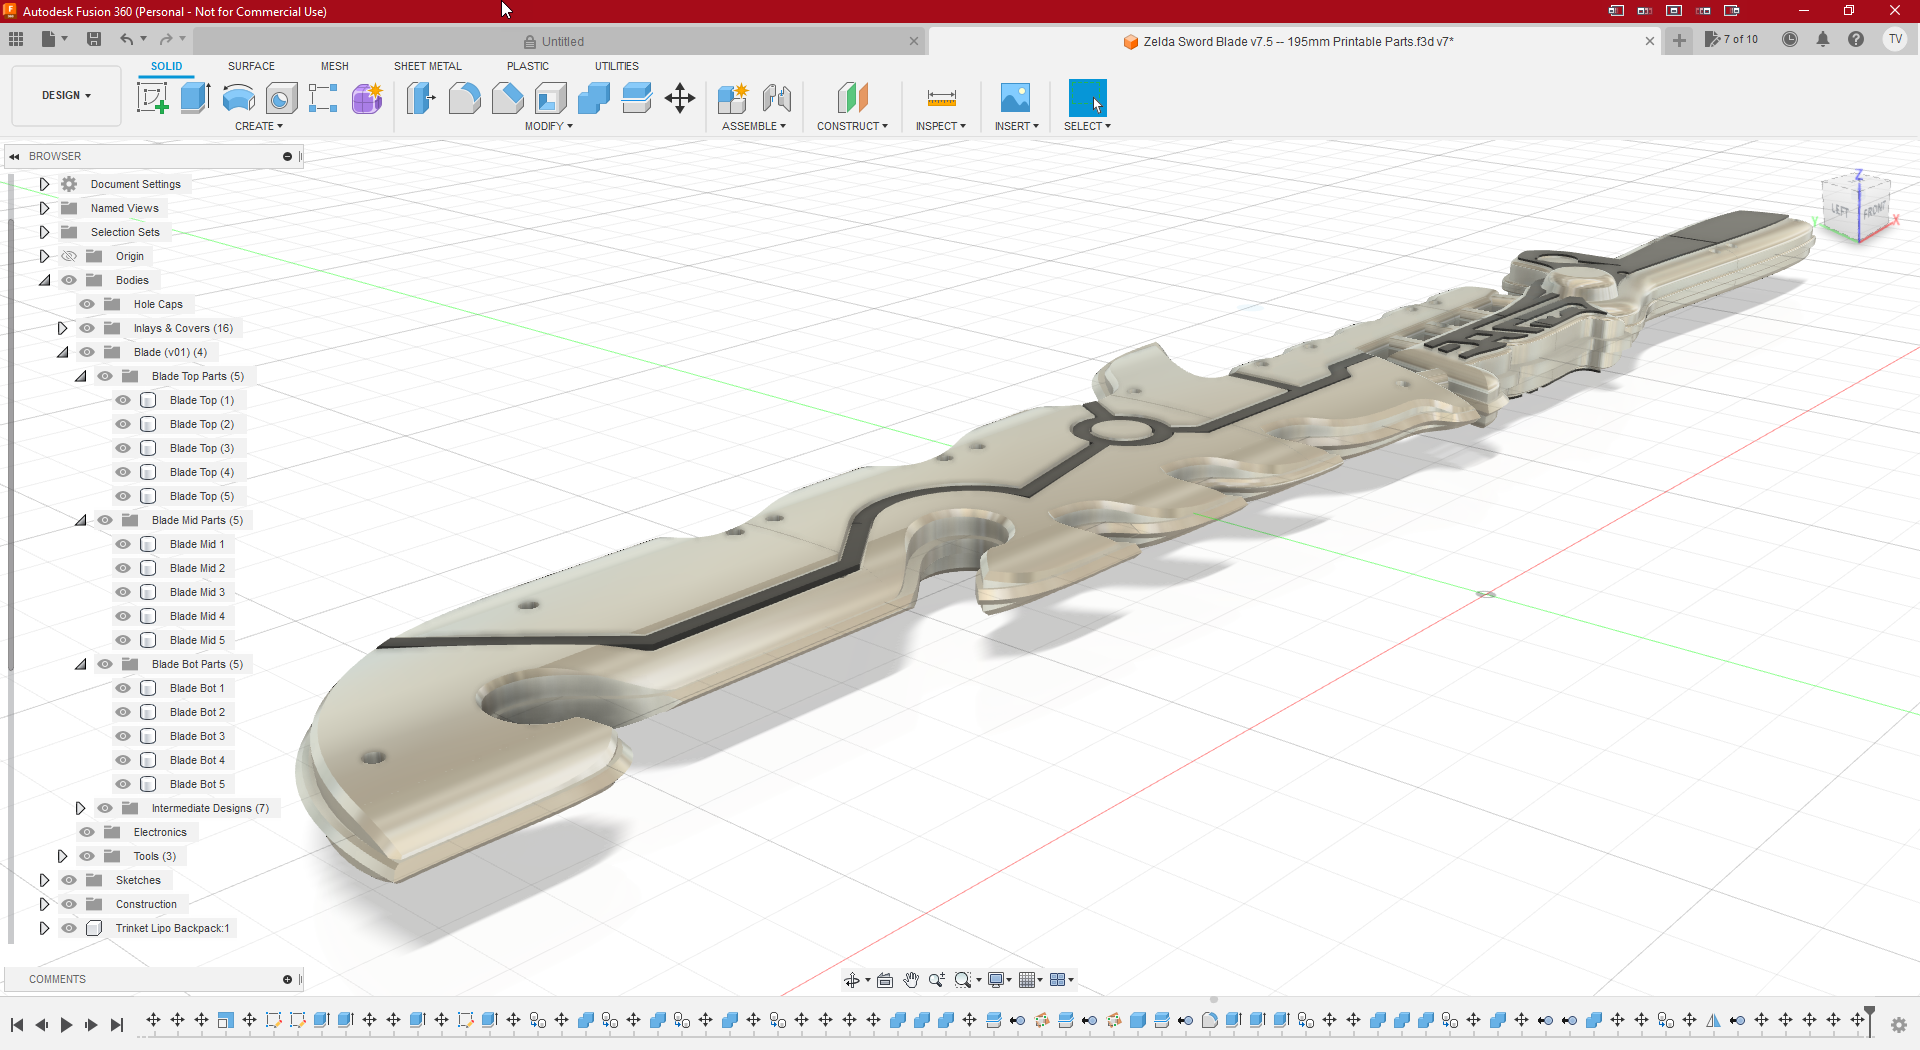
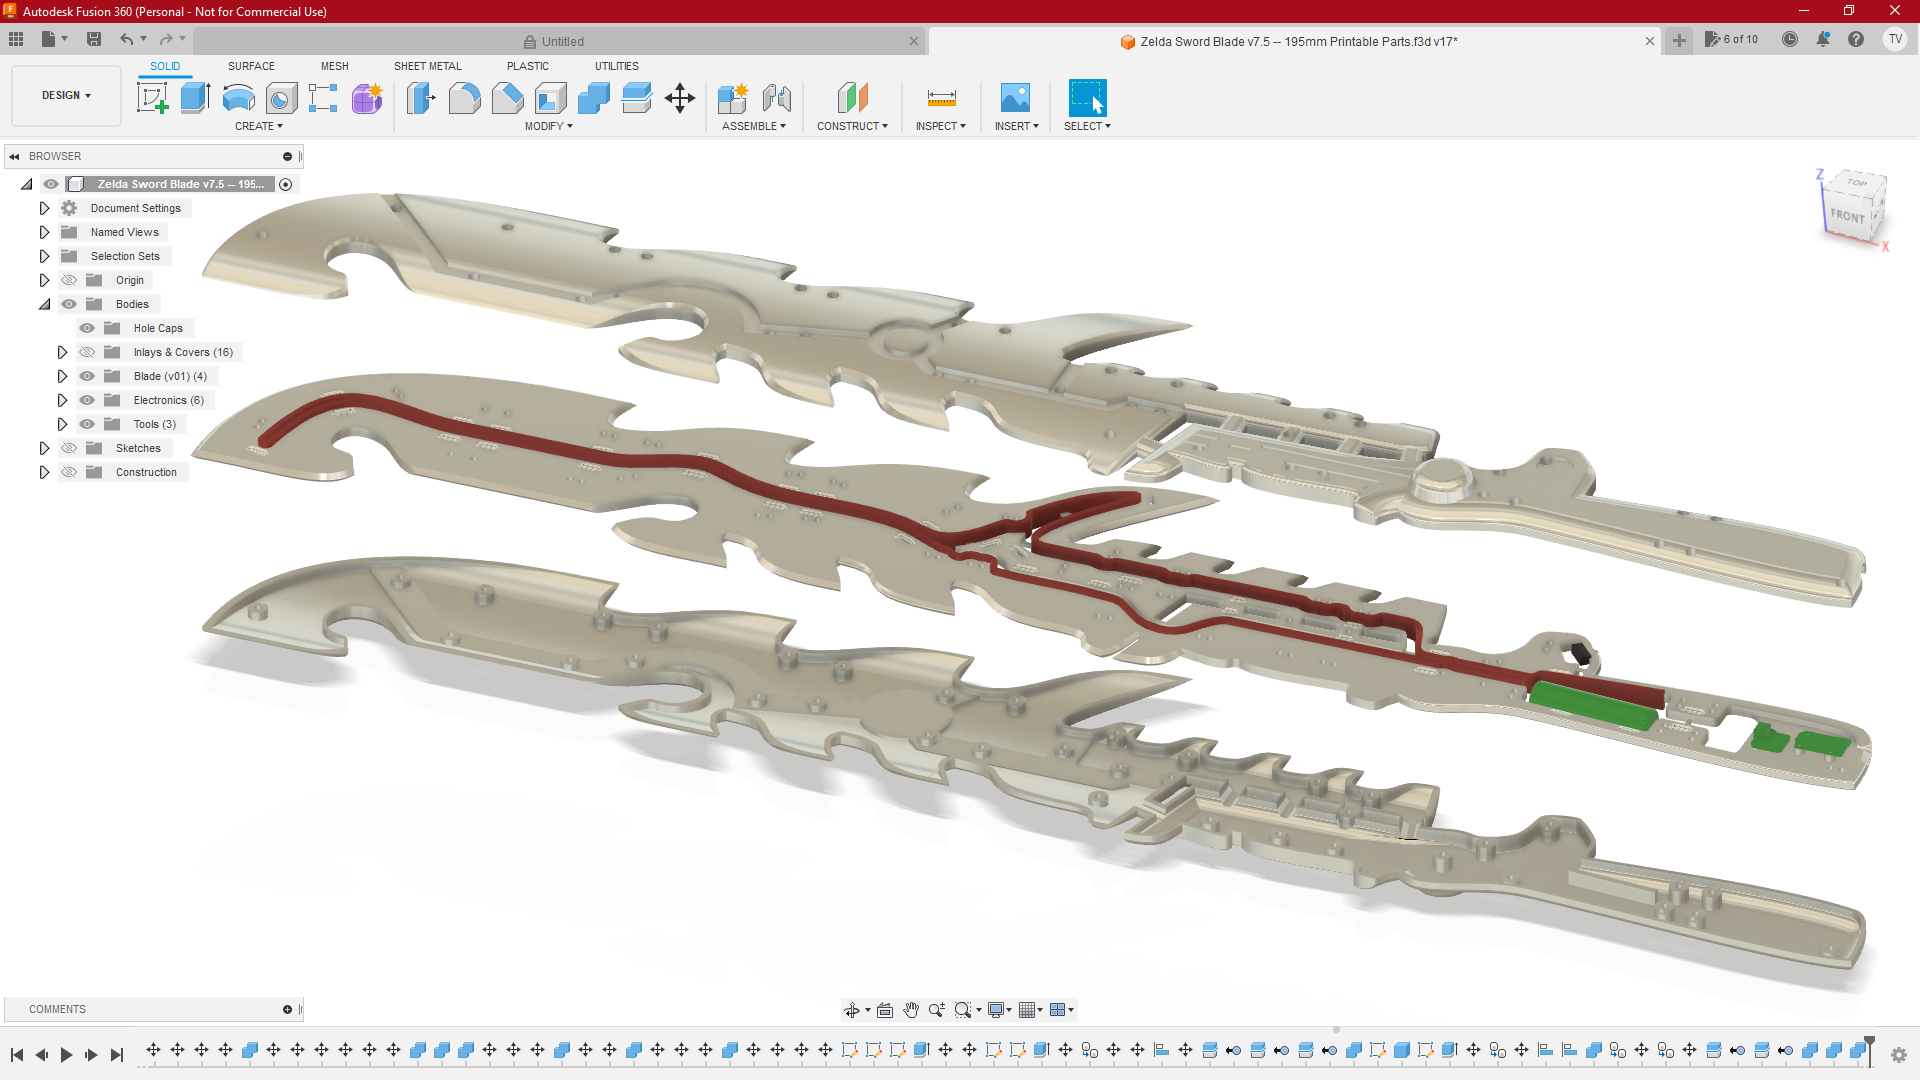
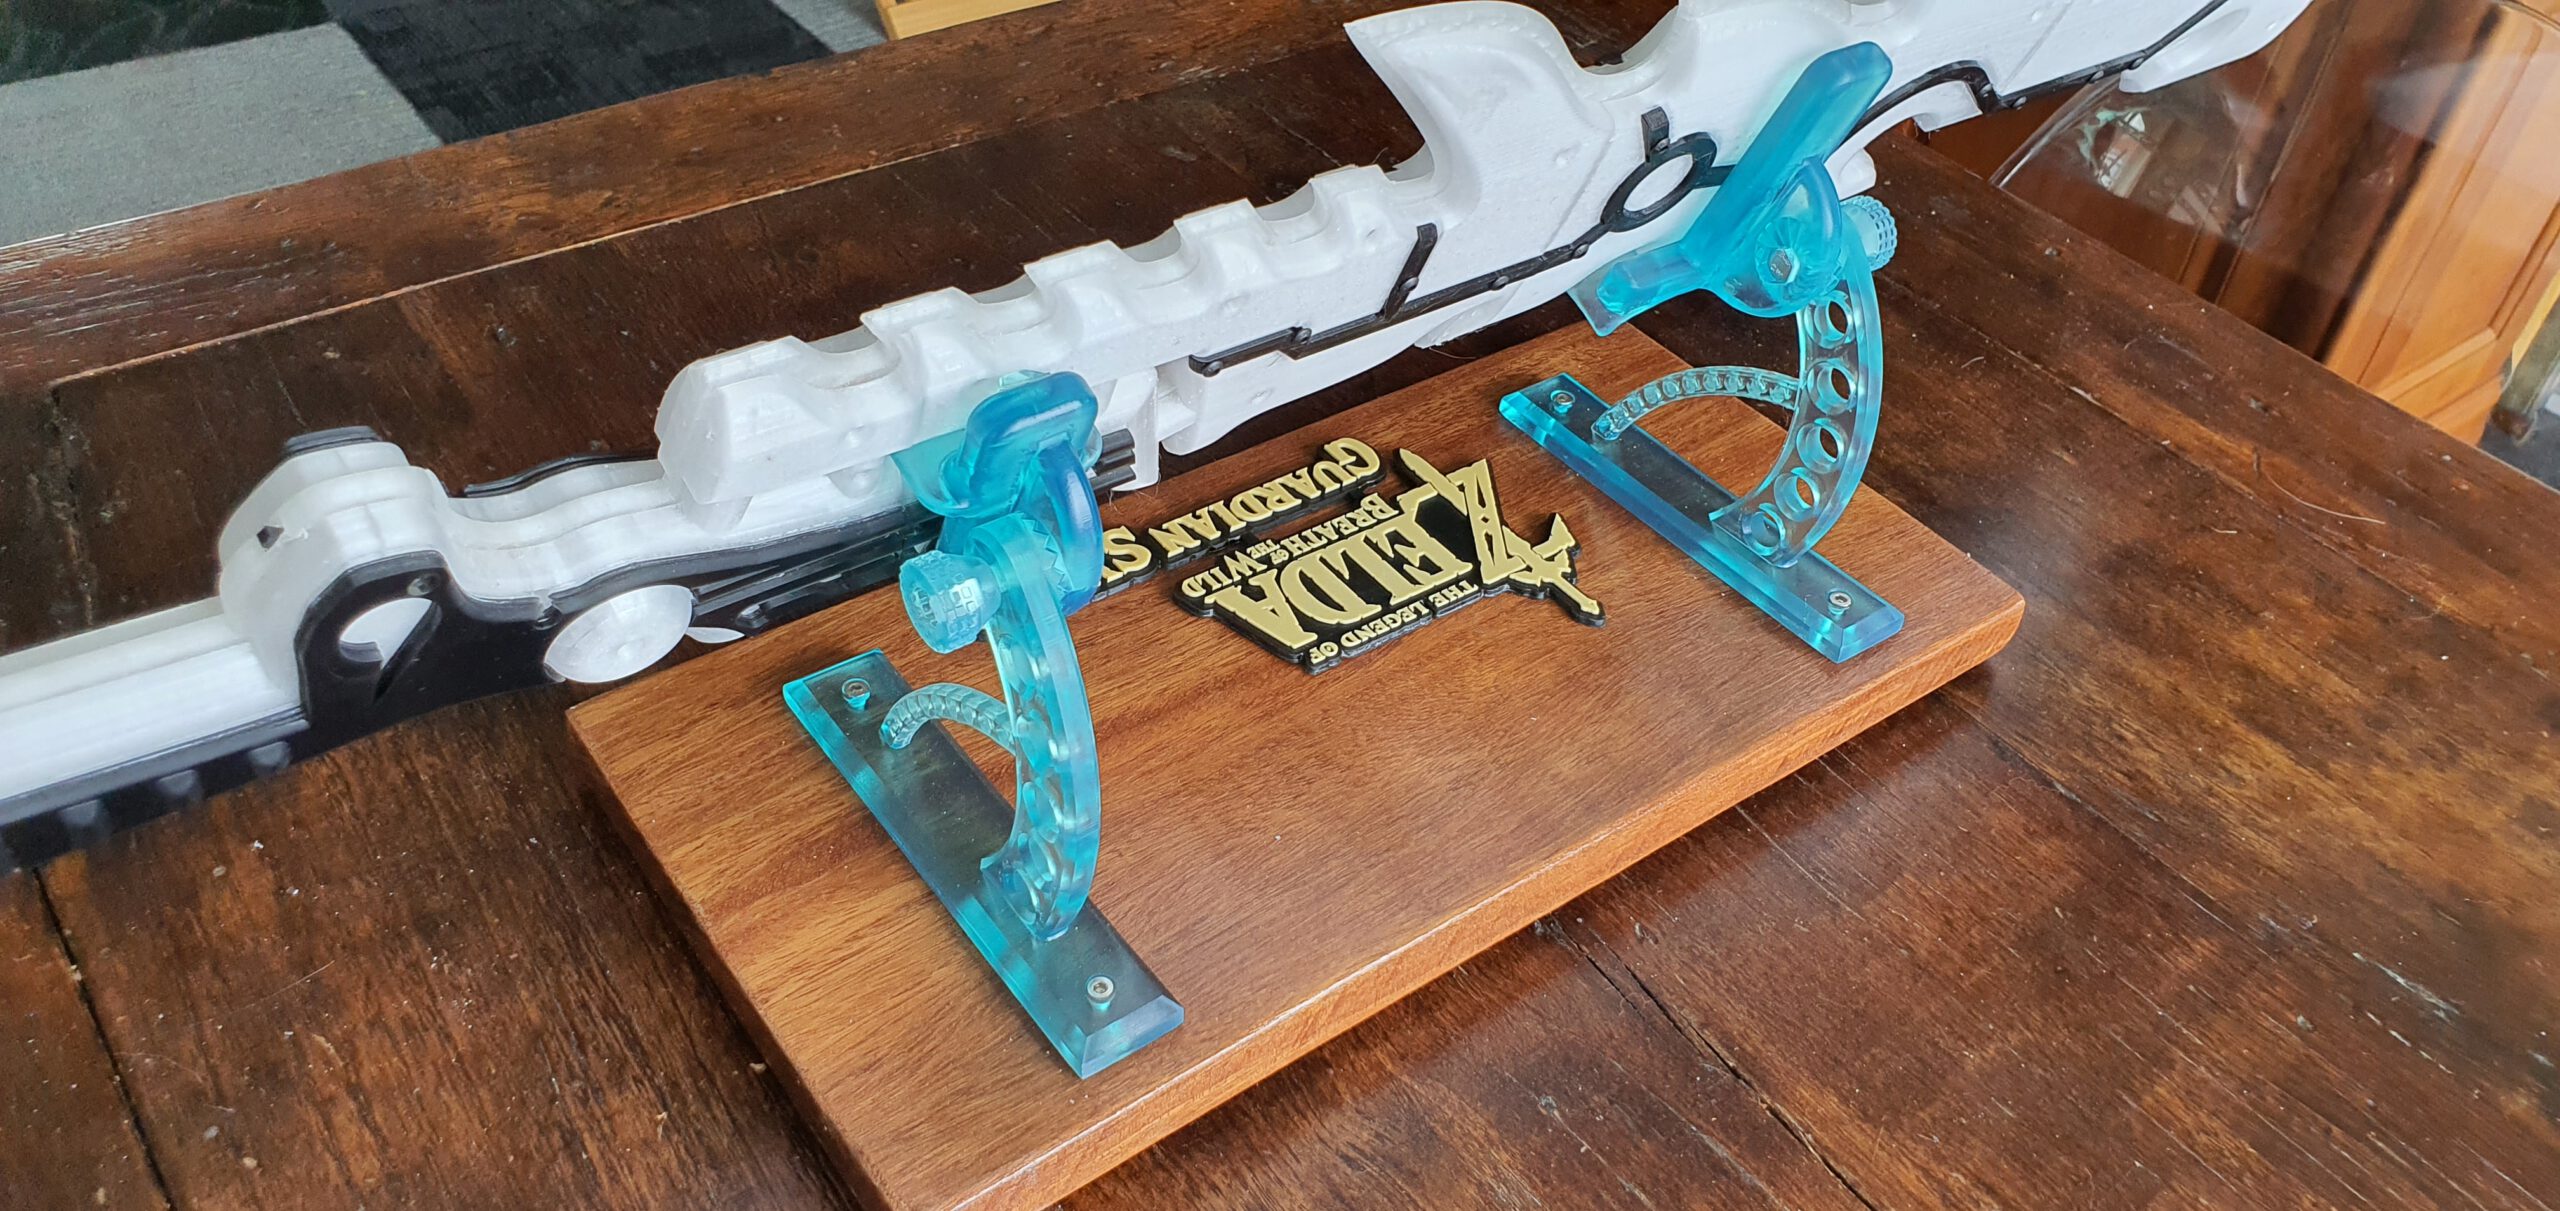
I made the original Zelda :BOTW Guardian Sword with NeoPixel Leds for my daughter and it looked really cool. After a few months the sword fell to the ground and broke into two pieces. The original design was nice, but not that sturdy, and… I also thought it was quite boxy.
A sturdier and more streamlined design
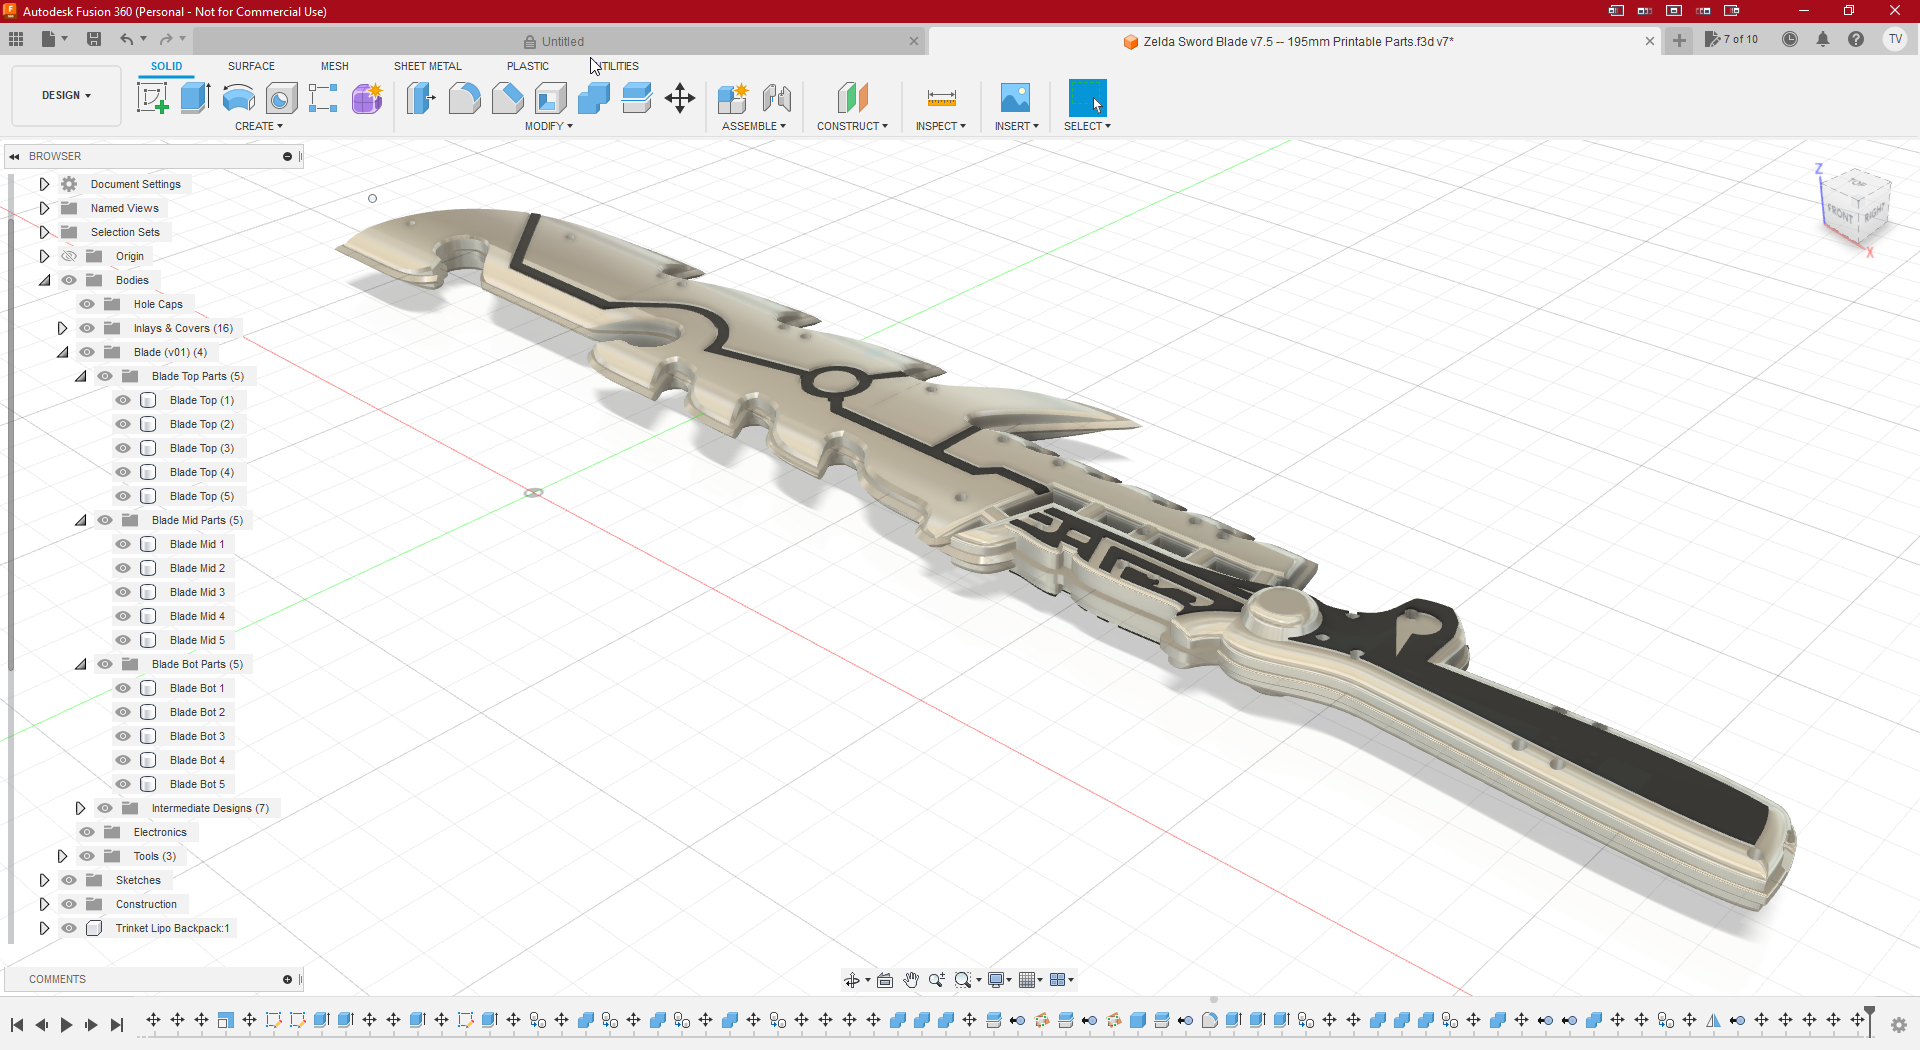
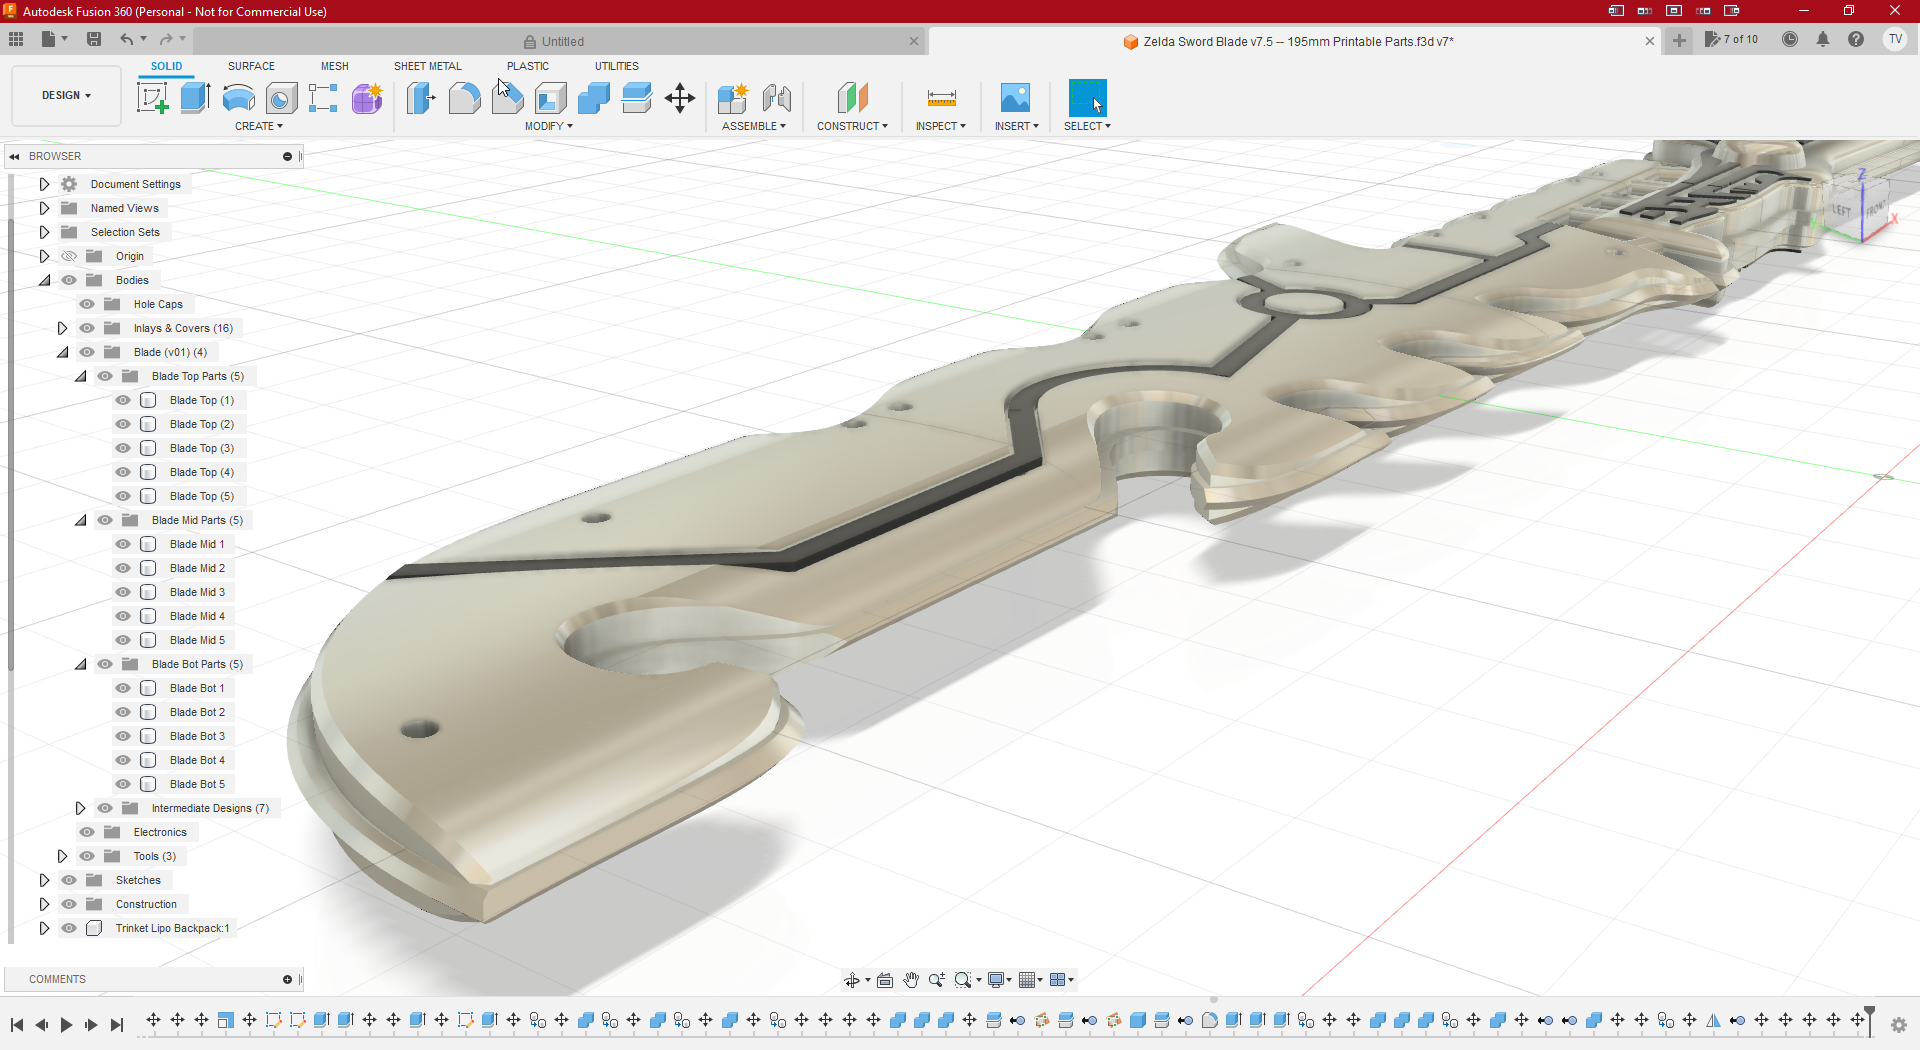
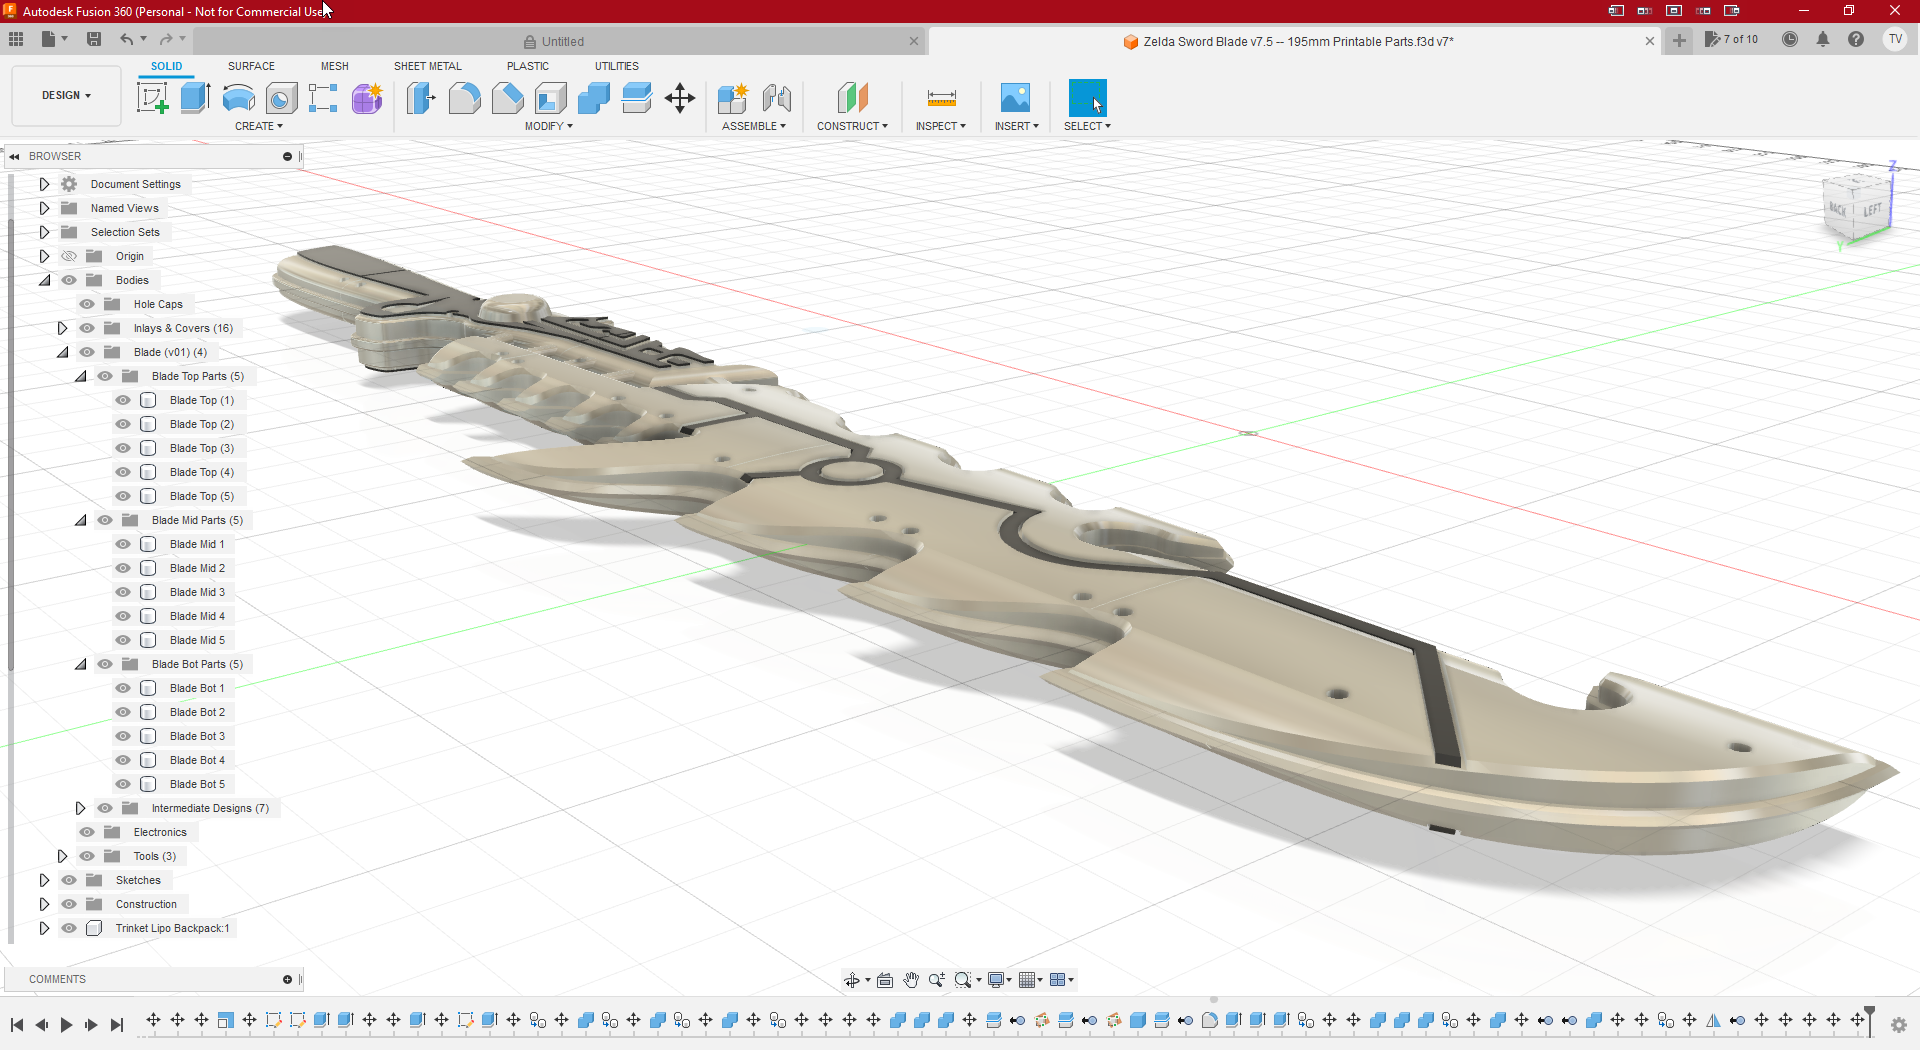
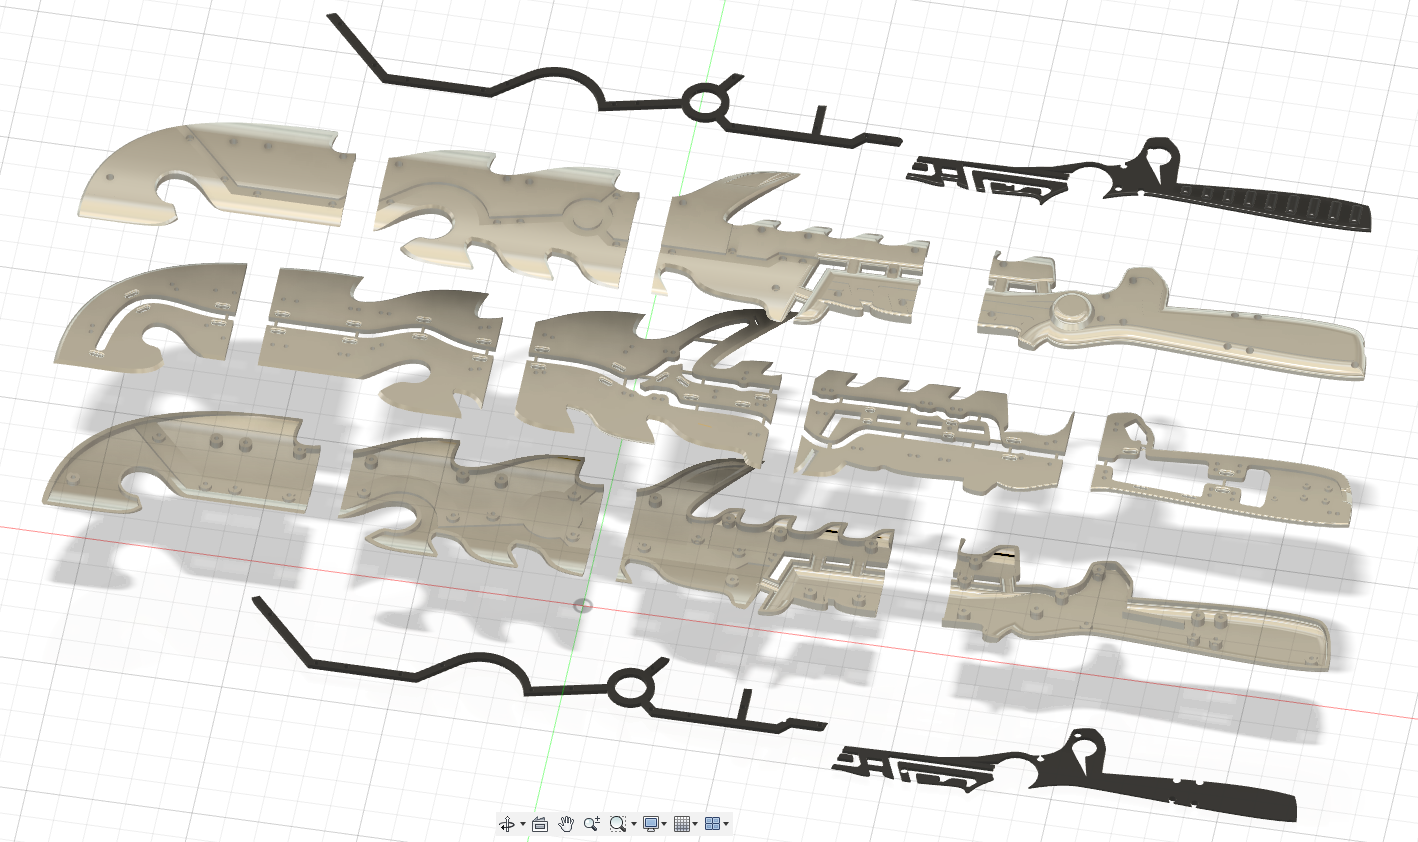
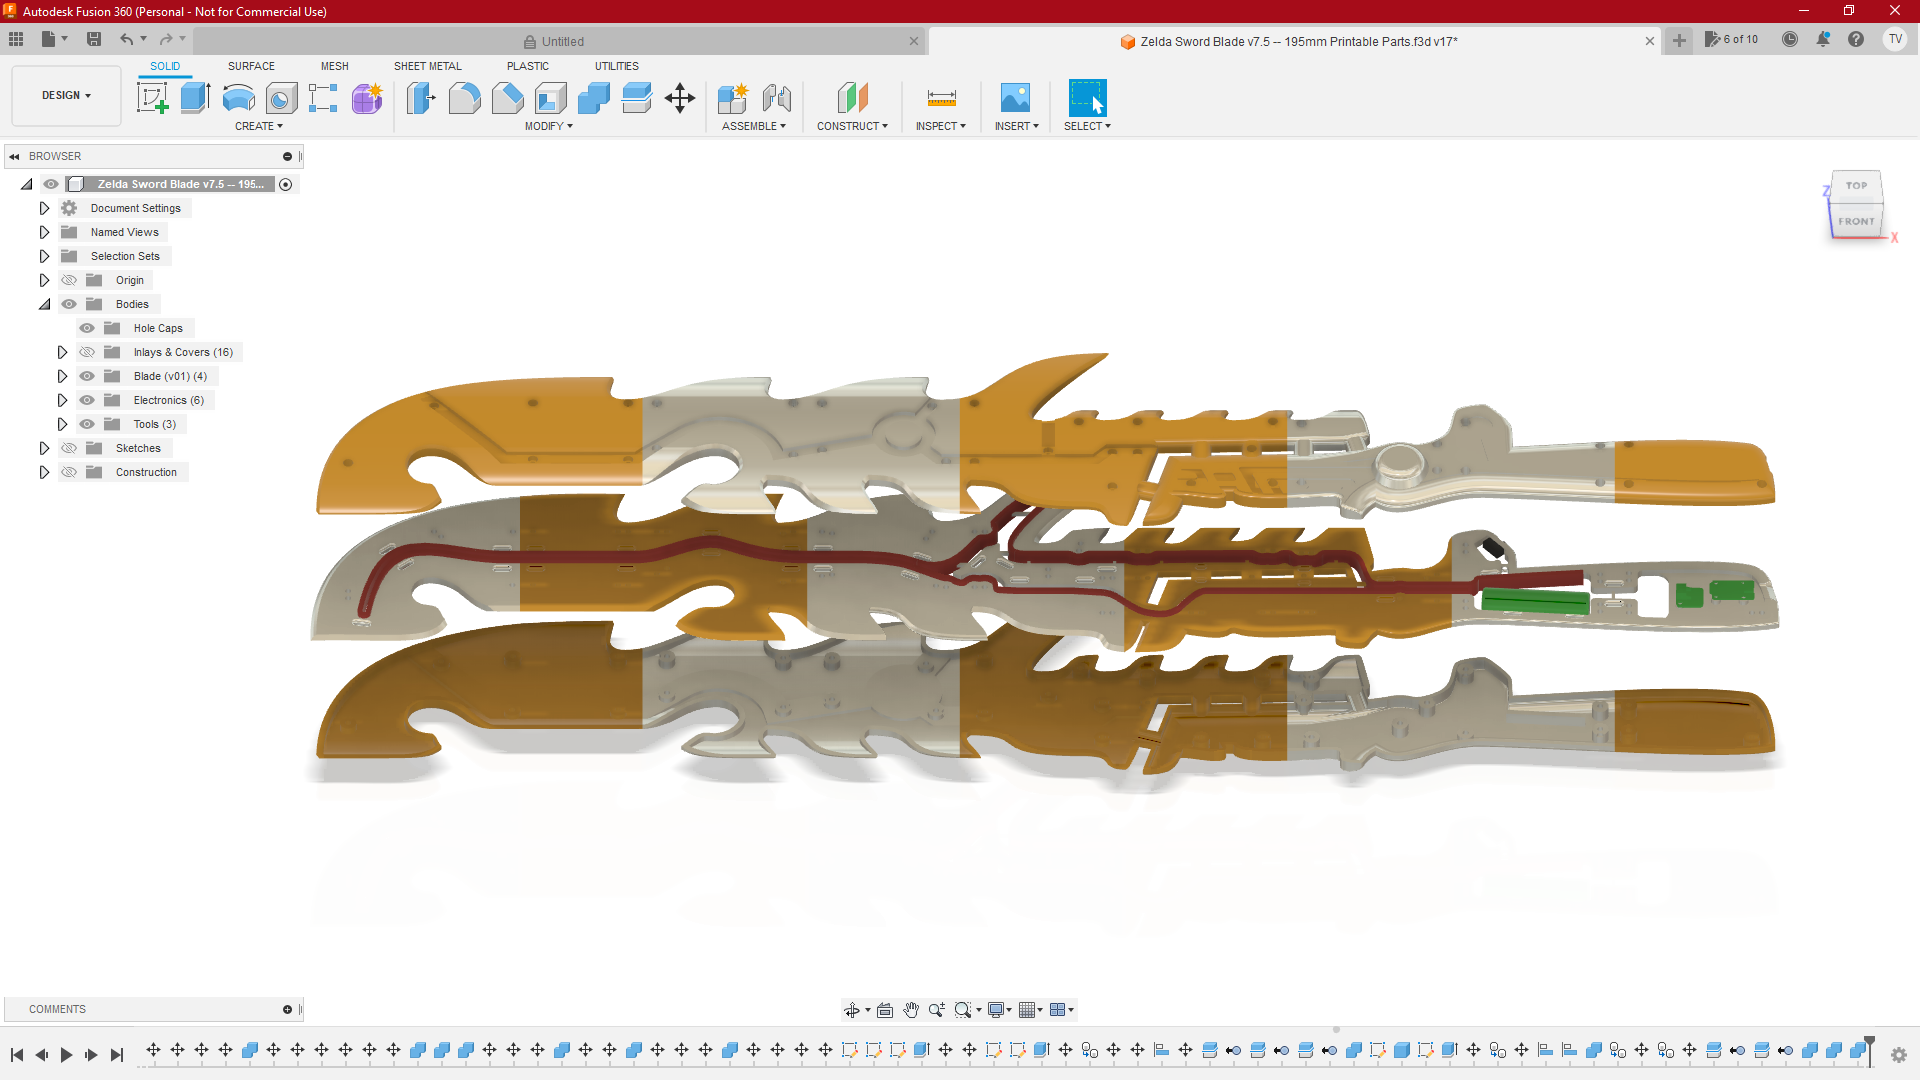
Then I decided to make a sturdier design that also had more flowing lines and formed a kind of sharp blade. I divided the sword into three layers that are mounted in overlapping brick bond for maximum strength. All corners are rounded and the middle layer creates an illusion of sharpness. For the rest I stayed as close to the original outline as possible because I liked it.
How it looked on the drawing Board
Assembling the sword
General Construction
Click to zoom in
Click to zoom in
Click to zoom in
Click to zoom in
Step 1: heat inserts
There are holes in the middle layer where M3 Heat Inserts can be mounted. The outsides can then be fitted with M3 hexagon socket screws.
Step 2: Screw on one of the outsides
There is a recess in the center surface for the LED strip. If the center surface is screwed to one of the outside edges, the paceholders that are in various places in the recess can be cut away.
Step 3: mount the LED strip
The LED strip can then be secured with the slotted holes that are located in various places along the recess.
Step 4 Install the other outside
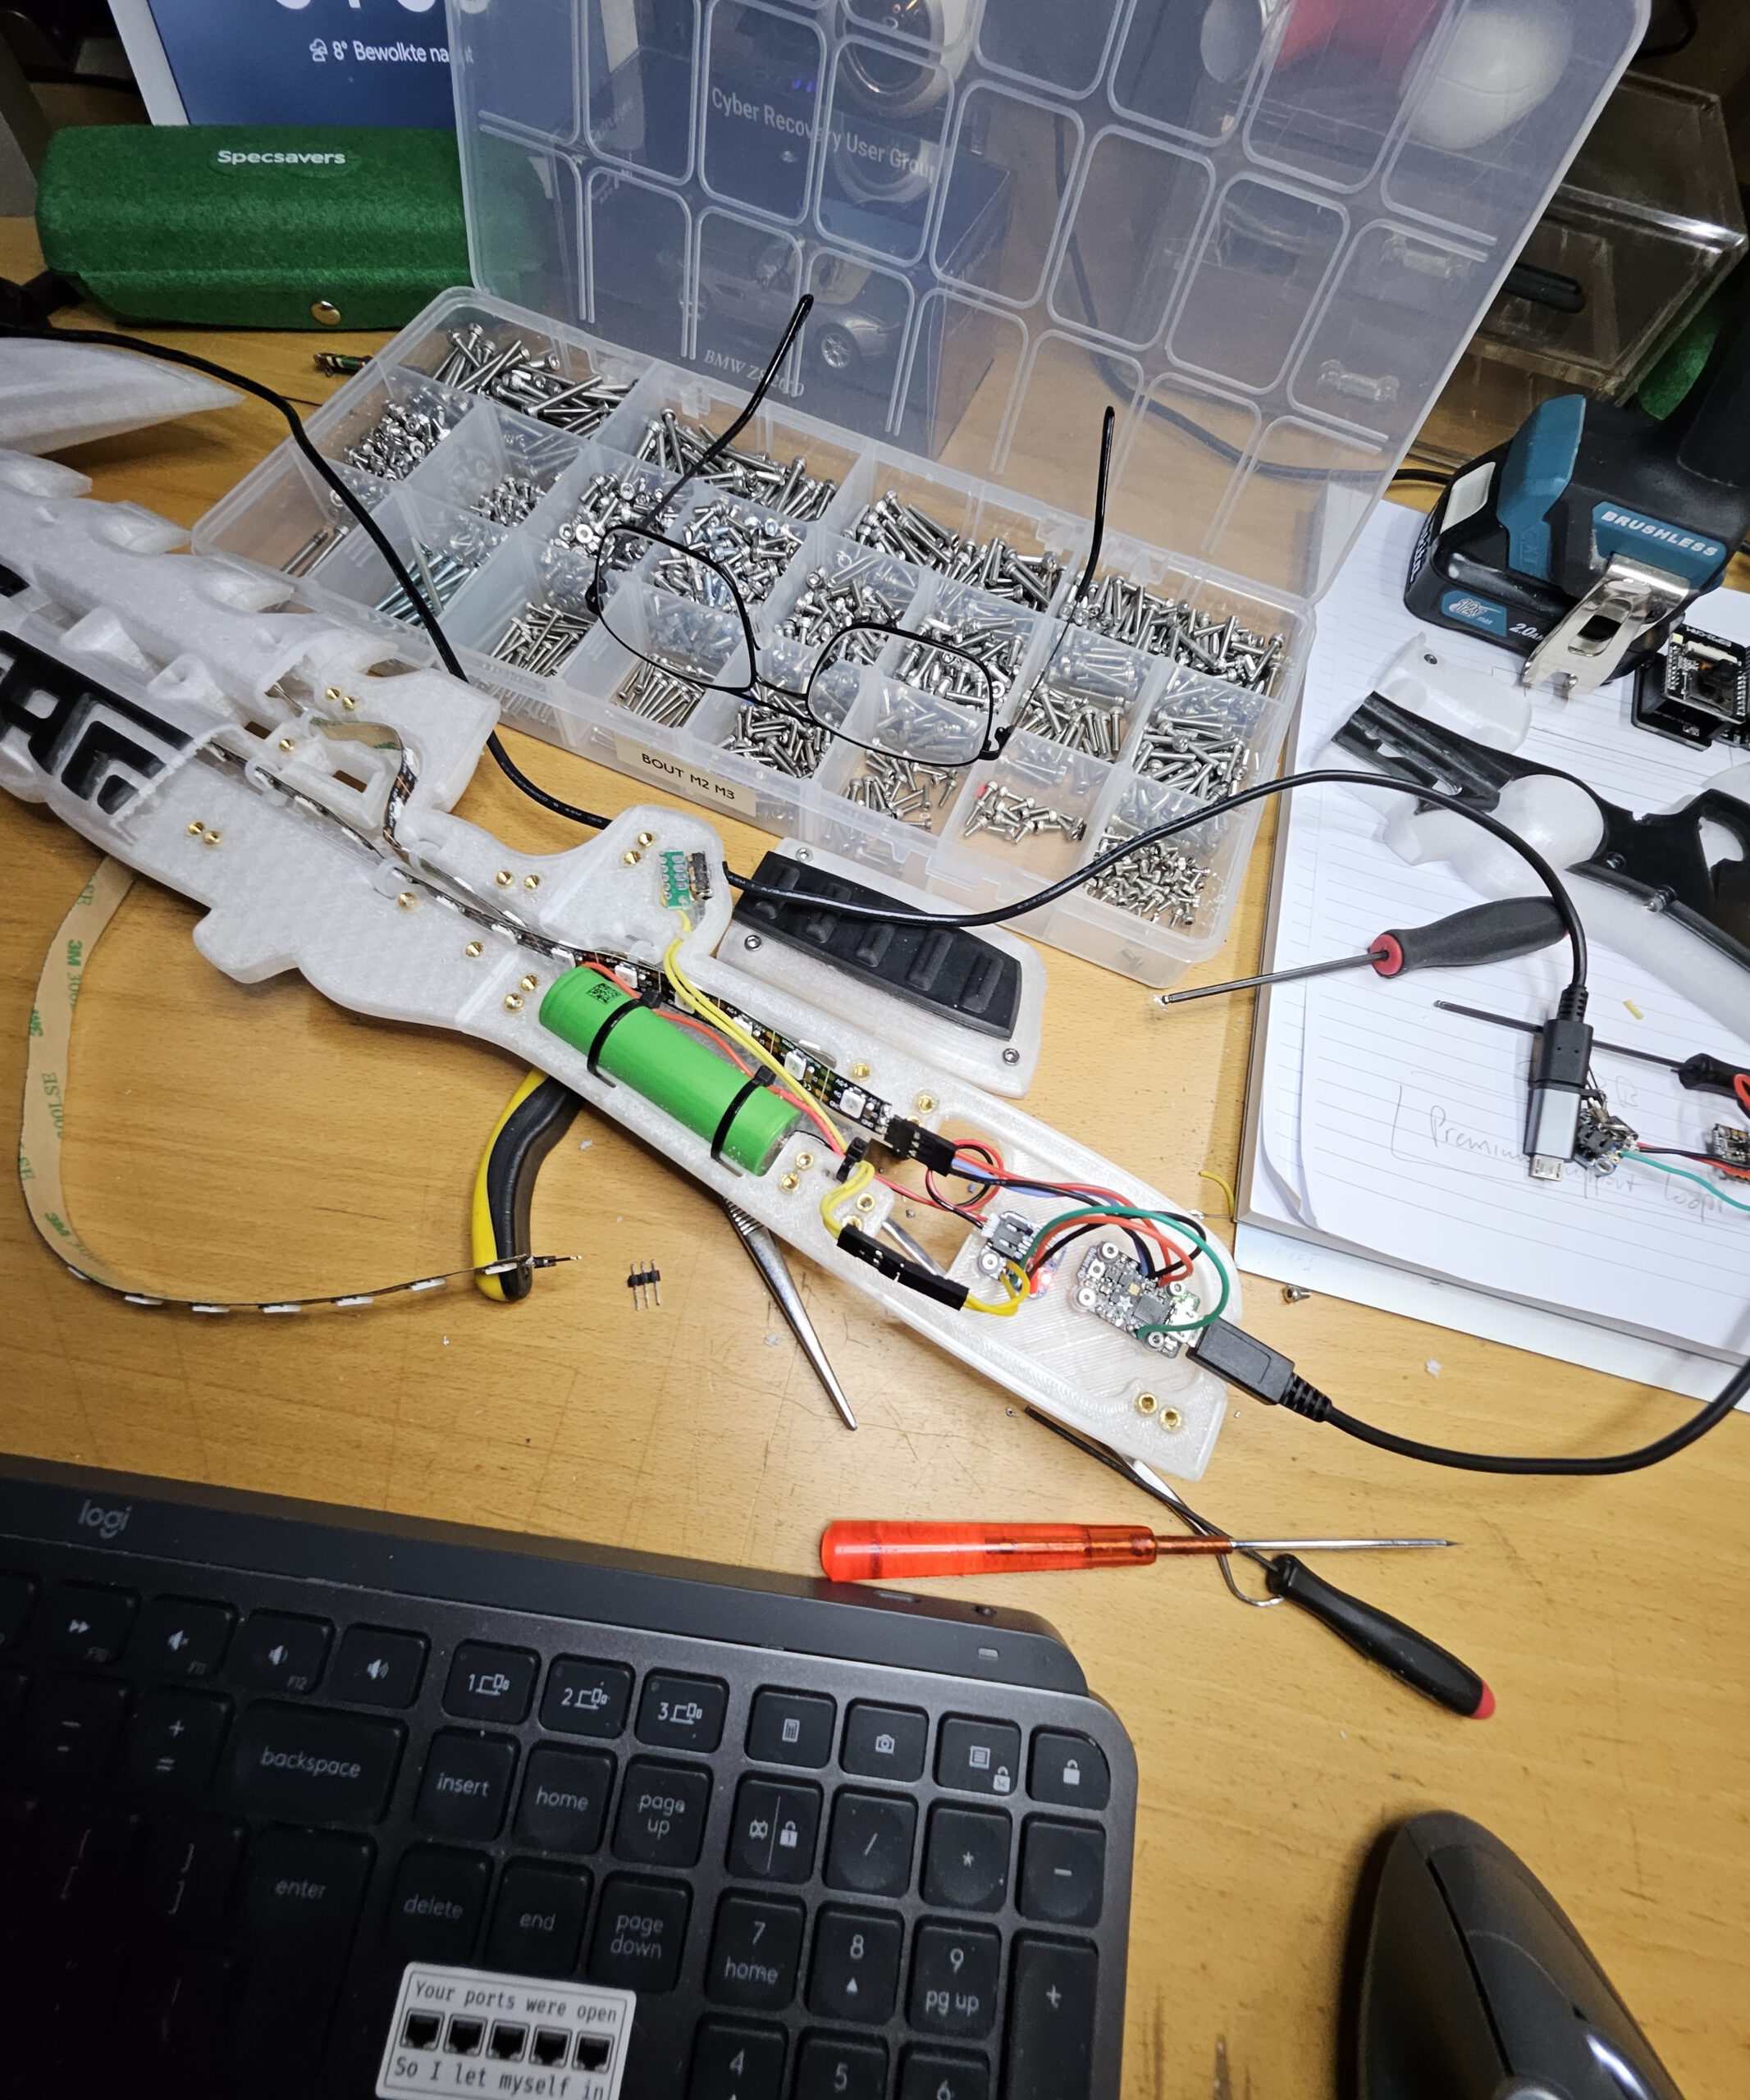
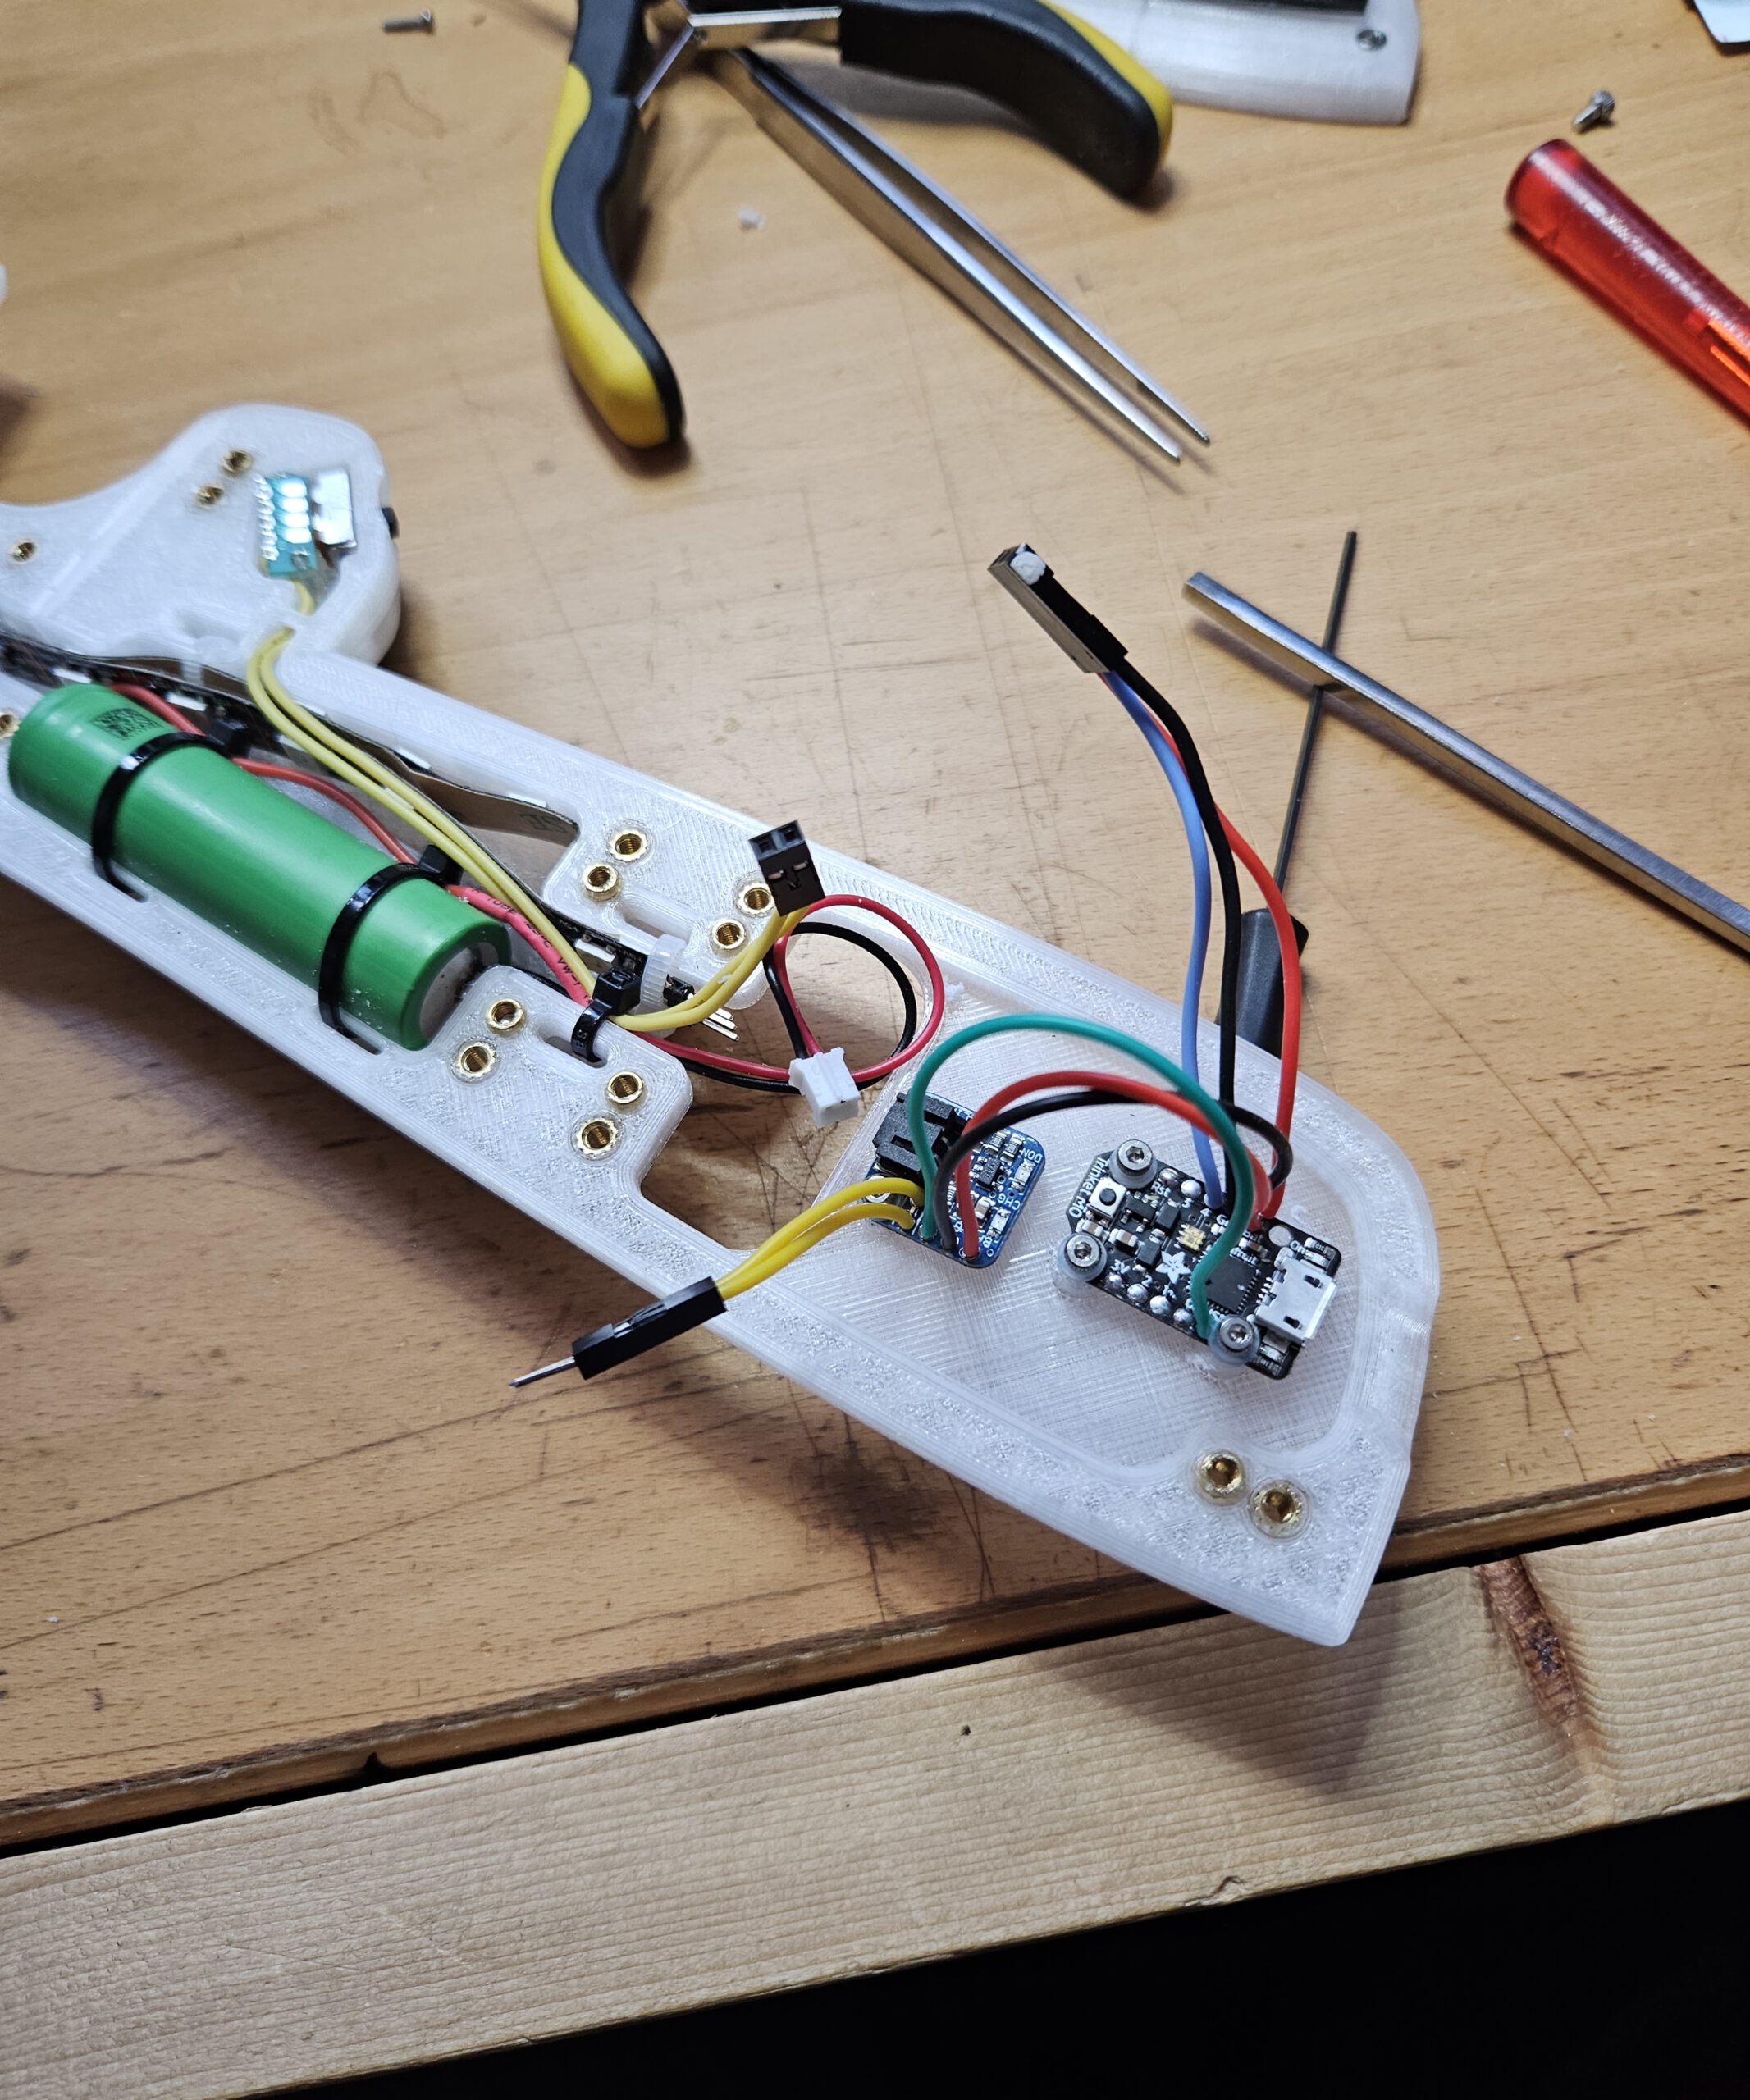
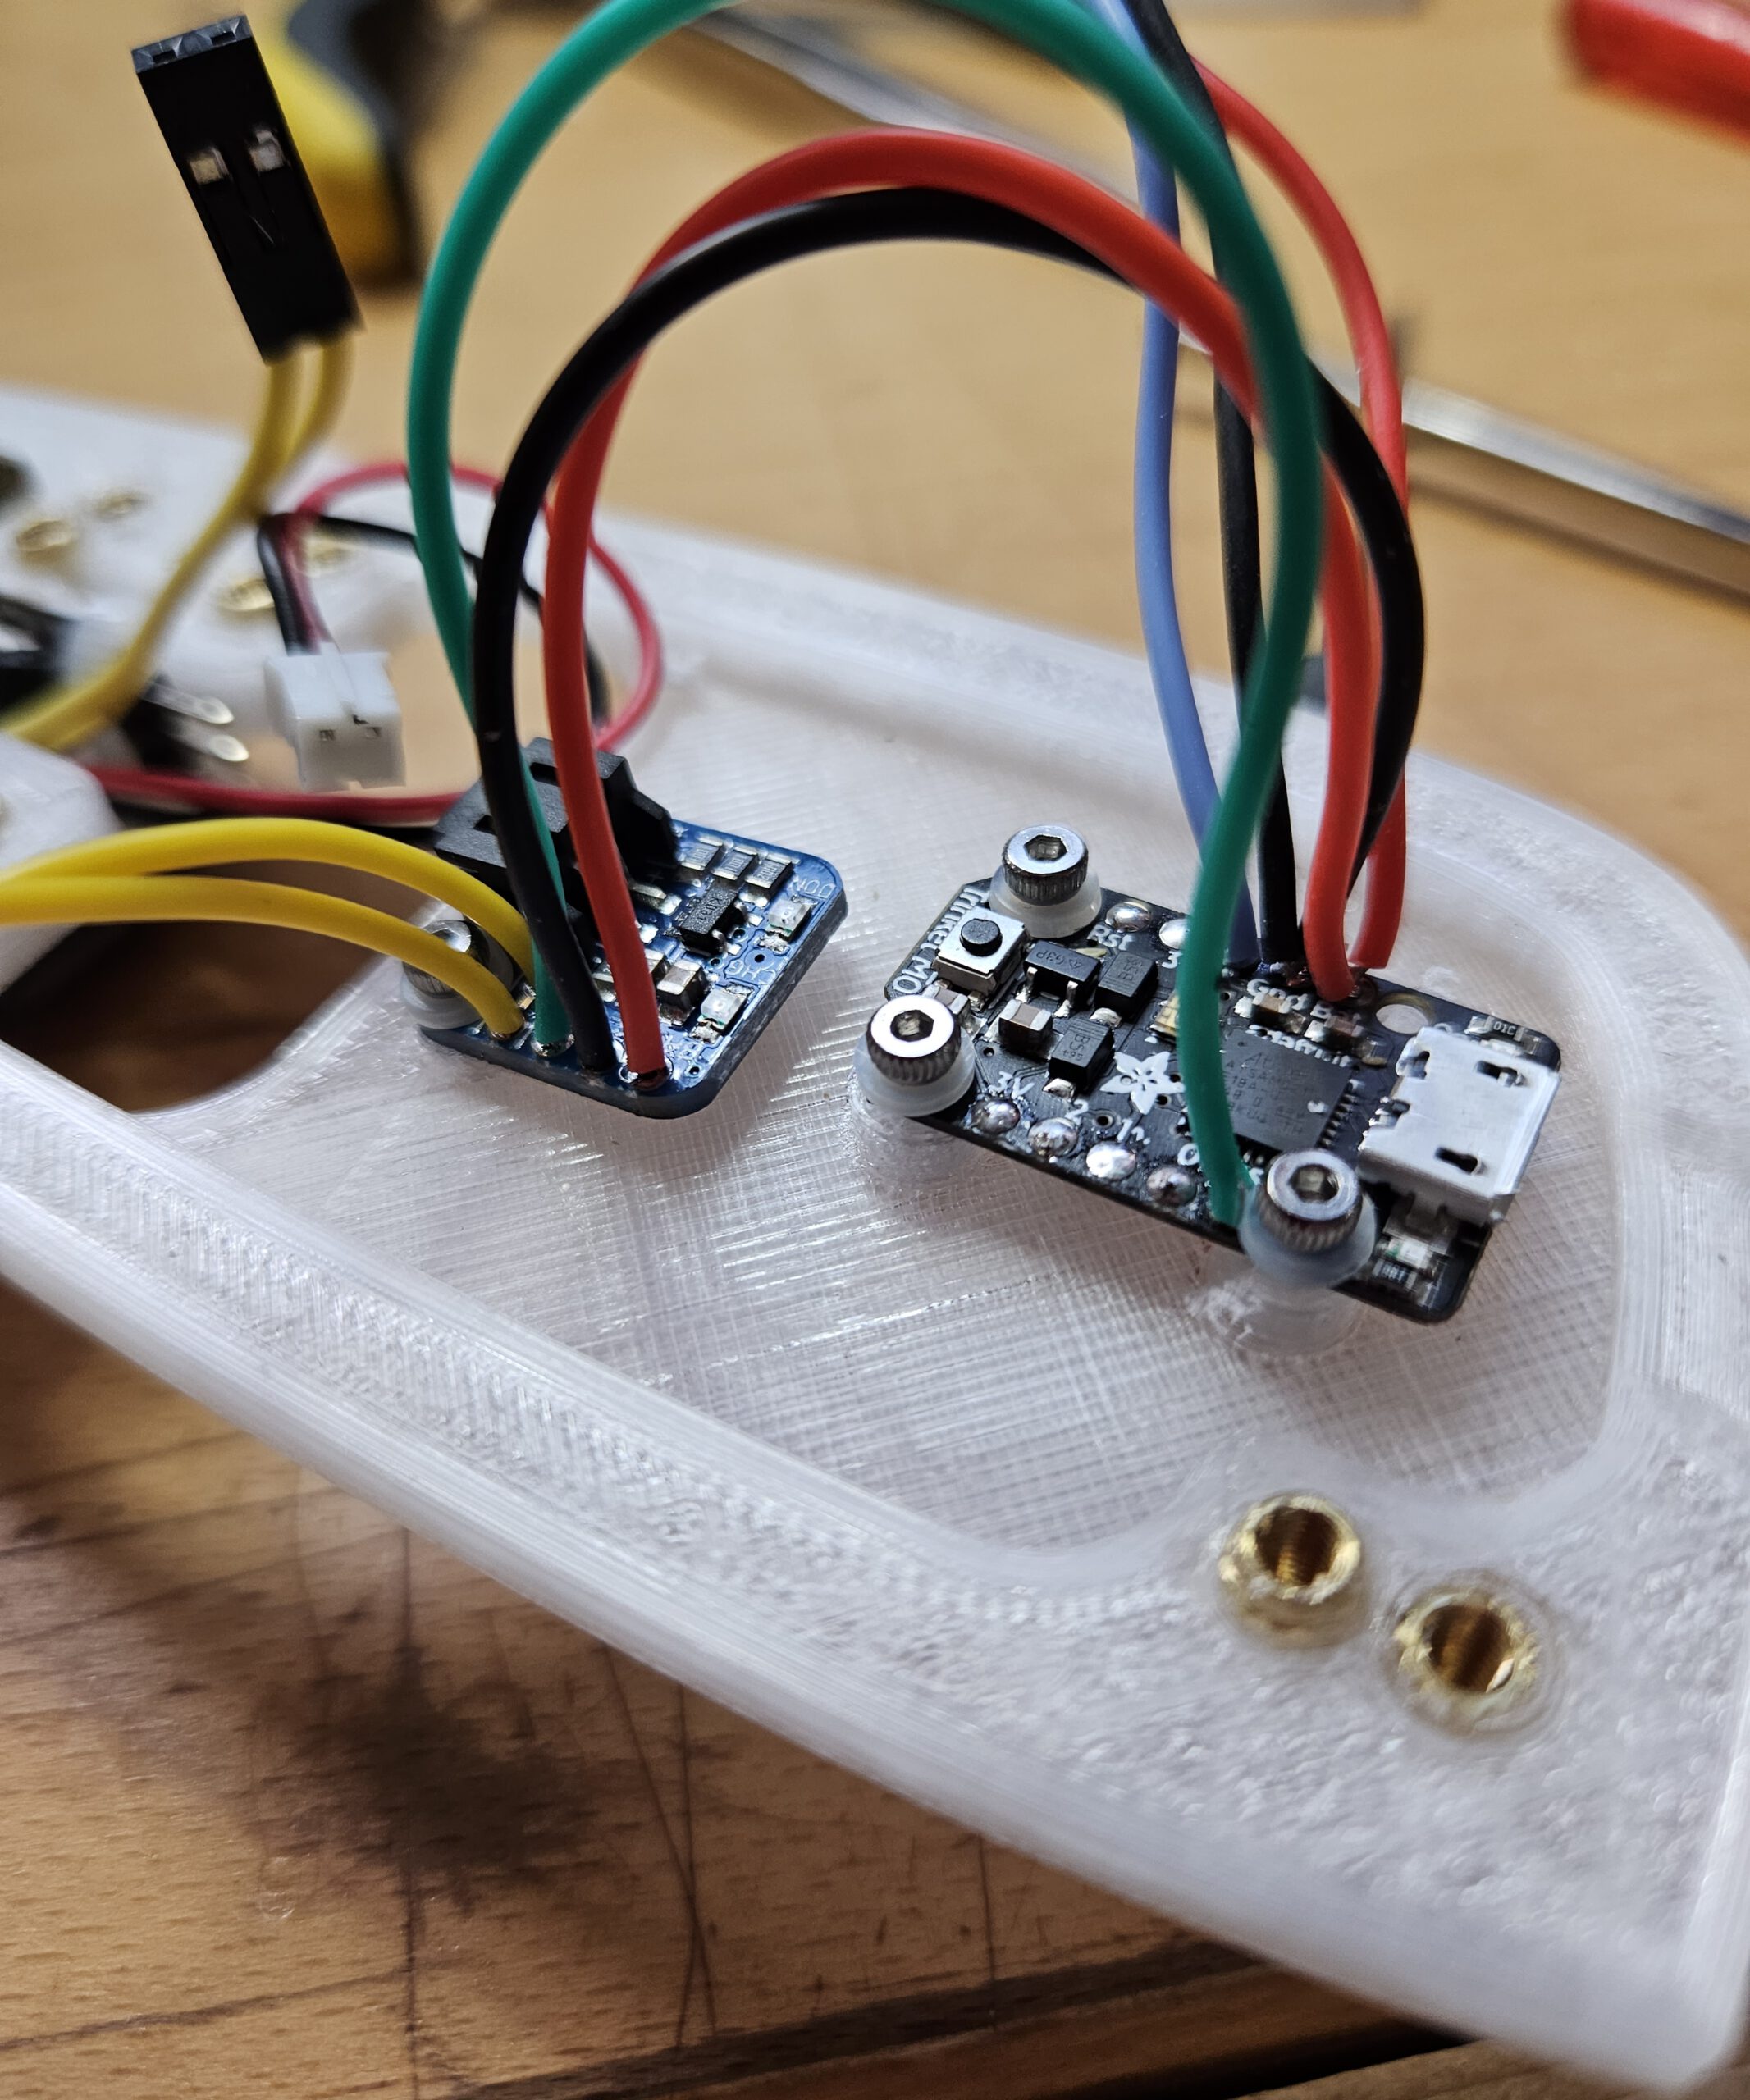
If you then screw the second (other) outside onto it, you get a very sturdy whole. Leave the handle open to mount the electronics. I have added a number of screenshots that explain some things in words and images.
Please note that the black details for the handle have placeholder connections. Do not glue these in place and cut them away after the glue has dried. Glue the black details in place (see photos).
And then your sword is ready.
Display base and Logo
In addition to the sword, I also designed a display base with the Zelda Logo on it.
Click to zoom
Click to zoom
Step 7: The Two-Tone Logo
The logo is printed with resin (liquid) with the black resin halfway replaced by yellow. (Try it, it works fine, pause the print, remove the build plate, rinse briefly, hang it back, put in a different color of resin and start again.) You can of course do something similar in your filament printer, pause, replace filament and start again.
Step 8: The support brackets
The brackets on which the sword rests are adjustable. This adjustability allows you to choose whether you want to place the base plate on something or hang it on the wall. You can adjust the angle according to your preference. I also printed those brackets with resin because you can then achieve a nice glass-like result.
Step 9: The base plate
I made it from wood because it has a very chic finish. But of course you can also print something.
Remark on supports
You must use supports for the outsides of the sword when printing. Normally I always try to make designs that you can print without supports, because supports always leave traces when removed, but that was not possible here.
Fortunately, they are on the inside and I recommend that you do not sand the surface completely smooth after removal because the irregularities give the light a nice diffuse character.
This is a compact, high-strength 3D-printed desktop vise designed for model making, electronics, 3D printing and other precision work.
The main feature of this design is its mechanically synchronized dual lead-screw drive.
Desktop Vise
Desktop Vise
Desktop Vise
Desktop Vise
Desktop Vise
Instead of moving the jaw with a single lead screw, this vise uses two T8 lead screws, one on each side of the moving jaw. A single handwheel drives both lead screws simultaneously through a three-gear transmission.
Because both sides are mechanically linked, they always travel together. This prevents the moving jaw from twisting or skewing and keeps the jaws parallel throughout their entire range of motion, even when a workpiece is clamped off-centre.
The video demonstrates the mechanism in operation.
How it works
The centre gear is connected to the handwheel and drives the two outer gears simultaneously. These drive the two T8 lead screws at exactly the same rate.
Two 8 mm steel guide rods provide additional guidance and rigidity for the moving jaw.
The result is a very simple mechanical system:
one handwheel → three synchronized gears → two lead screws → one parallel-moving jaw
No belts, electronics or separate adjustments are required.
Designed for strength
Although most of the vise is 3D printed, the parts carrying the main mechanical loads are steel rods, T8 lead screws, bearings and conventional fasteners.
The design can therefore be made considerably stronger than its appearance might suggest.
How strong it becomes depends heavily on the material and print settings used. I printed the vise using FormFutura TitanX with three walls/perimeters.
For heavier use, I recommend increasing the number of walls/perimeters rather than relying primarily on a very high infill percentage.
Print orientation is also important. Structural parts should preferably be oriented so that the main clamping forces do not try to separate the printed layers.
Obviously, this is still a predominantly 3D-printed desktop vise — it isn’t intended to replace the 20 kg lump of cast iron bolted to your workbench. 🙂
No Caption
No Caption
No Caption
No Caption
No Caption
No Caption
Linear bearings
The moving jaw runs on two 8 mm guide rods.
Printable linear-bearing components are included with the model, so commercial linear bearings are not strictly required.
However, I found that standard 8 mm metal linear ball bearings provide better stability and smoother movement, so I recommend using them if possible.
Gear grip
The three gears transfer the force through the bearing assemblies.
If you experience slipping under higher clamping loads, thin rubber rings or O-rings can be placed between the gears and the outer races of the ball bearings to increase friction.
Additional hardware required
Besides the printed parts, you will need:
3× deep-groove ball bearing — 15 × 32 × 9 mm
2× T8 lead screw — 8 mm × 125 mm
4× brass T8 trapezoidal lead-screw nut
2× 8 mm steel guide rod — 172 mm
2× 8 mm linear ball bearing — optional; printable alternatives are included
2× M8 threaded rod/stud — 215 mm
4× M8 nut
2× M3 × 20 mm socket-head screw
3× M3 × 15 mm socket-head screw
10× M3 × 10 mm socket-head screw
12× M4 × 30 mm socket-head screw
2× M4 × 10 mm socket-head screw
Standard washers and/or small adjustment hardware visible in the assembly may also be required depending on tolerances and the exact hardware used.
Printing
My original vise was printed primarily on a Voron 2.4 using ABS filament
Some smaller parts were produced using the Anycubic Photon Mono X 6K resin printer using “ABS-like” resin.
The design does not depend on these particular printers. Any reasonably well-calibrated FDM printer capable of producing mechanically strong parts should be suitable.
The vise was primarily designed for smaller precision work such as model building, electronics, PCB work, assembling 3D-printed parts and general maker projects.
The synchronized mechanism is particularly useful when working with parts that need to remain accurately aligned between the jaws.
Designed in Fusion 360 and built to answer a simple question:
How much of a proper precision desktop vise can you make with a 3D printer?